How many parts should a replicating printer print per plate to double its shop fastest?
research/selfrep-platepack
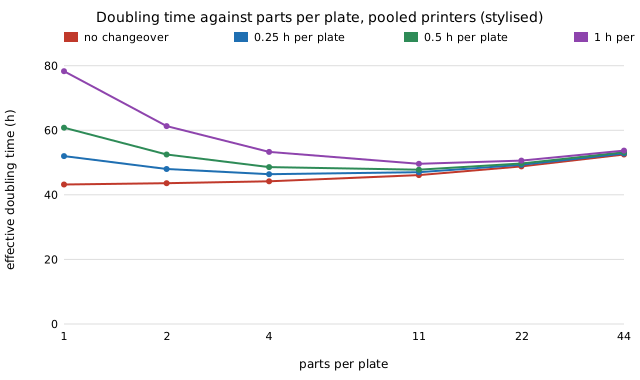
How many parts per print plate double a replicating printer shop fastest (stylised, assumed inputs): with no changeover one part per plate wins (43.2 h doubling), with 0.25 h per plate four parts (46.4 h), with 0.5 to 1 h eleven parts; pooled fleets stay 7.6 to 15.5% ahead of one copy per printer.
What it found
Groups the Prusa Mendel's 44 printed parts k to a plate in the selfrep-partpool simulator, with an assumed per-plate changeover of 0 to 1 h. With no changeover one part per plate is best (43.2 h effective doubling for a pooled fleet); at 0.25 h the best plate holds 4 parts (46.4 h), at 0.5 h and 1 h it holds 11 (47.8 h and 49.6 h). Pooling keeps an edge over one copy per printer (7.6–15.5%), and large plates cost it the pooling gain: at one plate per copy both policies coincide. Stylised: every input, including the changeover, is assumed, the BOM has no real part masses and plates are full and identical.
A figure from its own output
Paper, code and results
More in Self-replicating manufacturing
- How much of a RepRap printer can a growing seed shop make itself?Part, mass and cost closure of the RepRap Prusa Mendel (iteration 2) for three seed shops: printer alone makes 18 of 51 part lines (35%), plus router and laser 43%, assumed-mass closure 22%; casting helps only with brass bushings. Mass and cost inputs assumed. Stylised.
- Which machine should a seed shop add next, and does a greedy rule find it?Which machine a printer-only seed shop should add next under a budget: greedy closure-per-price vs exhaustive search; same choice on the real 3-machine instance, optimal in 72–94% of 500 synthetic instances. Machine prices assumed. Stylised.
- How fast does a replicating printer shop grow when its vitamins must be bought?Discrete-event and fluid growth of a replicating printer shop with imported vitamins: doubling time falls roughly as 1/budget until machine time binds (about 53 h in the simulation), failed builds cost about 1/(1-f), and closure helps most when imports bind. All inputs assumed; Lackner and Wendt comparison not done. Stylised.
- When should a replicating shop stop copying itself and start making goods?Optimal split of a replicating printer shop's time between copies and goods: copy flat out, then switch one e-folding time (about 50 h) before the horizon; constant splits get 9–27% of that value, smooth ramps no better. Cash-limited cases switch about 50 h from the end. All inputs assumed. Stylised.
- How much imported material can recycling save a self-replicating printer shop?Mass and energy balance of plastic and aluminium recycling for one RepRap copy (stylised, assumed process parameters): vitamins stay about 75% of imported mass, recycling the shop's own scrap cuts imports a median 3%, and only retired-machine plastic changes the plastic import much.
- How many printer copies does it take for a shop's recycling machines to repay their own imports?Payback of recycling machines with their own assumed part lists (stylised): about 100 printer copies on the shop's own scrap, 12–31 if retired machines' plastic is recycled.
All 34 Self-replicating manufacturing projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.