How fast does a replicating printer shop grow when its vitamins must be bought?
research/selfrep-growth
Discrete-event and fluid growth of a replicating printer shop with imported vitamins: doubling time falls roughly as 1/budget until machine time binds (about 53 h in the simulation), failed builds cost about 1/(1-f), and closure helps most when imports bind. All inputs assumed; Lackner and Wendt comparison not done. Stylised.
What it found
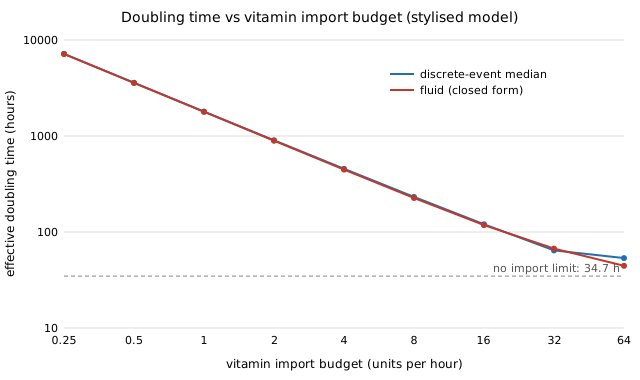
Builds on the selfrep-closure part model. A discrete-event simulation of a fleet of printers that each build copies of themselves, checked against a closed-form fluid model. With a small import budget the doubling time falls almost in proportion to the budget (about 455 h at 4 units/h, 120 h at 16/h); above a crossover fleet size N* = BW/V machine time binds and doubling flattens near the 50 h build time. Failed builds raise the doubling time by about 1/(1−f), and raising closure helps most when imports bind. Every input (print rate, assembly time, costs, budget, failure rate) is assumed and the fleet is homogeneous. Stylised. The comparison with Lackner and Wendt’s growth model is not done.
A figure from its own output
Paper, code and results
More in Self-replicating manufacturing
- When should a replicating shop stop copying itself and start making goods?Optimal split of a replicating printer shop's time between copies and goods: copy flat out, then switch one e-folding time (about 50 h) before the horizon; constant splits get 9–27% of that value, smooth ramps no better. Cash-limited cases switch about 50 h from the end. All inputs assumed. Stylised.
- How much imported material can recycling save a self-replicating printer shop?Mass and energy balance of plastic and aluminium recycling for one RepRap copy (stylised, assumed process parameters): vitamins stay about 75% of imported mass, recycling the shop's own scrap cuts imports a median 3%, and only retired-machine plastic changes the plastic import much.
- How many printer copies does it take for a shop's recycling machines to repay their own imports?Payback of recycling machines with their own assumed part lists (stylised): about 100 printer copies on the shop's own scrap, 12–31 if retired machines' plastic is recycled.
- Does pricing a shop’s imports, instead of weighing them, change when its recycling machines repay themselves?Recycler payback priced instead of weighed (stylised, assumed prices): plastic pair 98–111 printer copies on own scrap, furnace 203, 10–26 with retired plastic.
- What is the closed form of a replicating shop’s smooth switch from copying to goods, and does it match dynamic programming?Closed-form optimal copy share for a replicating printer shop with a saturating goods market (Pontryagin singular arc: goods output grows linearly, last 1/k hours all goods); earns 99.96–100% of the dynamic-programming policy's value. Necessary conditions only; all inputs assumed. Stylised.
- When the goods market saturates, does a replicating shop’s bang-bang switch turn smooth?Reinvestment of a replicating printer shop when the goods market saturates, checked by dynamic programming: bang-bang is optimal with linear revenue, but with market capacity below about 10^4 machine-hours per hour the optimum ramps the copy share down over 90–300 h and bang-bang loses 4.5–7%. All inputs assumed. Stylised.
All 34 Self-replicating manufacturing projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.