What is the closed form of a replicating shop’s smooth switch from copying to goods, and does it match dynamic programming?
research/selfrep-singulararc
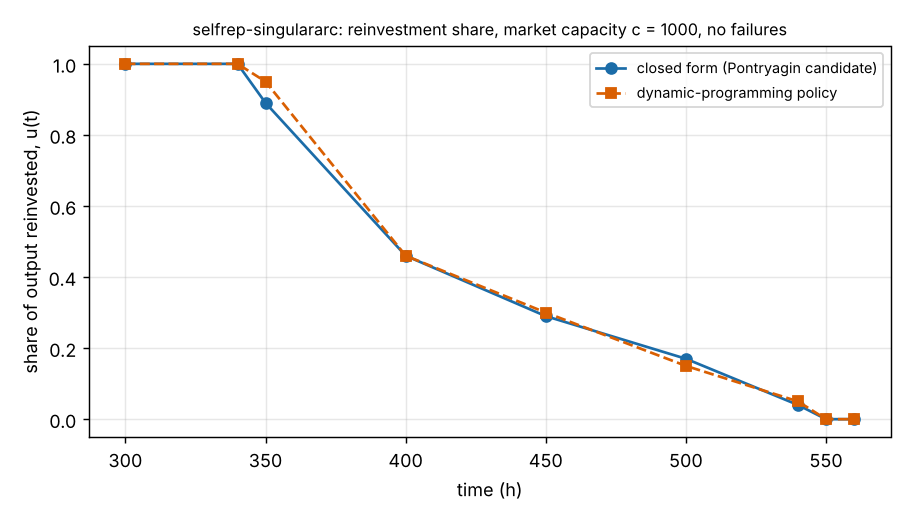
Closed-form optimal copy share for a replicating printer shop with a saturating goods market (Pontryagin singular arc: goods output grows linearly, last 1/k hours all goods); earns 99.96–100% of the dynamic-programming policy's value. Necessary conditions only; all inputs assumed. Stylised.
What it found
Builds on selfrep-satmarket. With concave revenue a c(1 − e−g/c), Pontryagin’s principle gives three arcs: copy flat out, a singular arc on which goods output grows linearly at rate kc, then goods only for the last 1/k hours. The entry time solves one scalar equation. In the Euler model the open-loop policy earns 99.96–100.00% of the dynamic-programming policy’s value over 7 market sizes and 4 failure shares. The conditions are necessary, not a proof of optimality, and depend on the assumed exponential revenue form. Stylised.
A figure from its own output
Paper, code and results
More in Self-replicating manufacturing
- When the goods market saturates, does a replicating shop’s bang-bang switch turn smooth?Reinvestment of a replicating printer shop when the goods market saturates, checked by dynamic programming: bang-bang is optimal with linear revenue, but with market capacity below about 10^4 machine-hours per hour the optimum ramps the copy share down over 90–300 h and bang-bang loses 4.5–7%. All inputs assumed. Stylised.
- What fleet can a replicating printer shop sustain when its machines wear out?Fleet a replicating printer shop sustains when machines wear out (stylised, assumed inputs): short-lived machines die out from one seed; recycling gains need a correction for builds cut short.
- Can an exactly solvable birth-death chain explain why short-lived printer fleets die out?Exact mean extinction time of a wearing-out printer fleet as a birth-death chain (stylised, assumed inputs): explains the die-outs in kind, within about 35% only after a post-hoc fix.
- Does paying for spares late rescue the long repair queue of a printer shop?Does paying for spares at service start rescue the long repair queue of a printer shop (stylised, assumed inputs): yes, an unbounded queue then beats never repairing (488 against 458 at one bench) and queue caps stop mattering.
- What happens to a repairing printer shop when repairs need labour?Repair labour as a limit on a repairing printer shop (stylised, assumed inputs): with few repair benches an unbounded queue of broken machines is dead stock and does worse than never repairing; capping the queue recovers most of the gain.
- When is repairing a printer worth more than building a new one?Repair versus replacement in a replicating printer shop (stylised, assumed inputs): repair wins iff its cost share is below its success probability, but only if spares are held back from new builds.
All 34 Self-replicating manufacturing projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.