Does writing a fixed-weight multiplier as shift-and-add with canonical signed digits beat Yosys's x * K?
research/chip-constmul
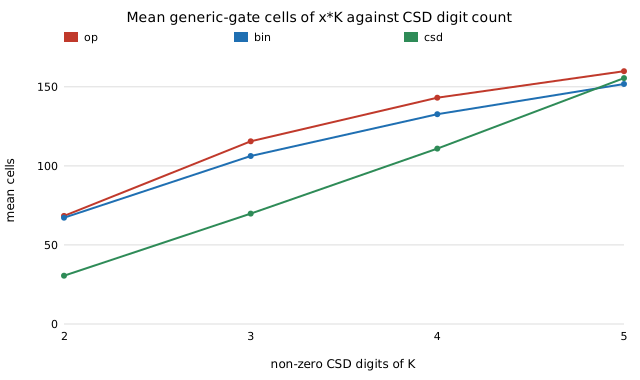
Fixed-weight multipliers for all 255 8-bit constants: Yosys's x * K tracks binary shift-add (Pearson 0.97 with set bits), and a canonical-signed-digit form has 33% fewer generic-gate cells at similar depth (every form proved equivalent).
What it found
For every 8-bit constant K (1–255), an 8-bit input is multiplied three ways — the * operator, binary shift-add, and canonical-signed-digit (CSD) shift-add/subtract — and scored by Yosys 0.33 in generic gates; every variant is proved equivalent to the operator form by a miter. The operator tracks binary shift-add (cells correlate 0.97 with the number of set bits of K, 0.65 with CSD digits). CSD uses 75.7 mean cells against 112.9 for the operator (33.0% fewer; fewer cells for 230 of 255 constants, worse for 14) at similar mean depth (20.0 vs 19.6); K=255 drops from 222 to 30 cells. Preliminary: one tool version, one ABC script, generic gates rather than library area, one input width, no shared sub-sums across constants.
A figure from its own output
Paper, code and results
More in LLM chip design loops
- Does sharing sub-sums across a bank of fixed-weight multipliers cut gates beyond per-constant shift-and-add?A bank of fixed-weight multipliers sharing sub-sums (multiple-constant multiplication): 9% fewer generic-gate cells than per-constant signed-digit shift-add at 2 constants and about 20% fewer at 8 and 16 (43% fewer than Yosys's
*), every form proved equivalent; random constants, not trained weights. - How many gates could an exact 4-input rewriter still remove from Yosys/ABC netlists?How many gates an exact 4-input rewriter could still remove from real Yosys/ABC netlists: none in 28 of 30 runs (1 gate in two), even where the default script beats plain mapping by 25 to 42%, so the flow's gains are not local.
- How many gates above the proven minimum does Yosys/ABC use for 4-input logic?How far above the SAT-proven minimum gate count Yosys/ABC lands on 4-input logic: the default flow is exactly optimal on only 34% of sampled functions (mean 1.19 gates above, max 4), and a heavier script is worse.
- Does the ABC synthesis script matter as much as the written RTL structure for adder and multiplier area and depth?Sweeps five ABC scripts over five adder and eight multiplier structures (all proved equivalent): the script moves cells×depth by up to 1.75× for one adder, while all eight multiplier structures score identically (stylised, generic-gate).
- Does the order or naming of equivalent Verilog change what Yosys and ABC synthesise?Whether equivalent Verilog that differs only in wire names, statement order or the order of added operands synthesises to the same size: names and statement order never change cells×depth, operand order does for one carry-select adder (up to 1.43×, a 17% better result than the earlier sweep's best; stylised).
- Do the blocks of a carry-select adder share a + b independently when every chain gets its own operand order?Tests whether carry-select blocks share
a+bindependently under mixed per-chain operand orders: the set of sharing blocks predicts Yosys's adder count in 400 of 400 random variants and fixes the cells x depth score (8 sets, one score each per ABC script); the cost is not additive across blocks (stylised, Yosys 0.33).
All 40 LLM chip design loops projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.