Where does exact queueing analysis of a robot-printer cell stop working?
research/robofab-cell-cv
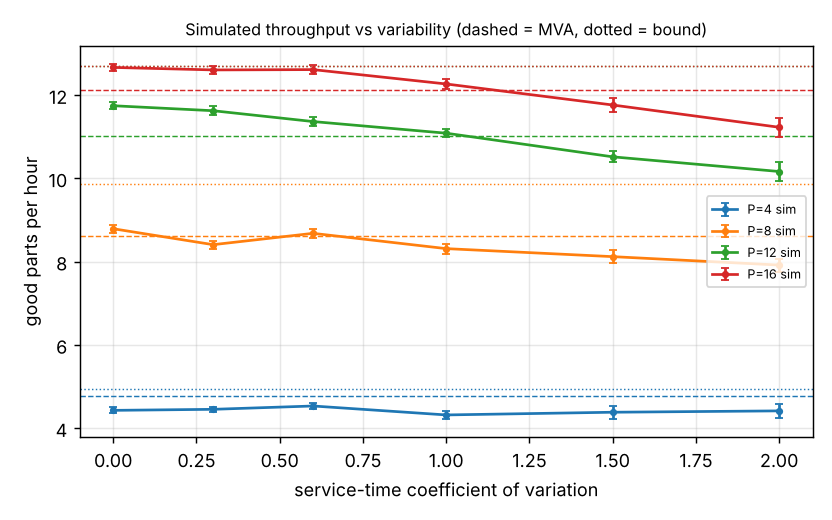
Coefficient-of-variation sweep and a measured printer stall share for the arm-printer-inspection queueing model: MVA's error crosses zero near cv 1 while the utilisation bound stays high, and held-printer capacity times (1 − stall) reproduces the saturated rate at 4 and 8 printers. Stylised.
What it found
A follow-up to the mean-value-analysis project: a coefficient-of-variation sweep (0–2, lognormal times, 4–16 printers, 20 seeds) and a directly measured printer stall share (finished parts waiting for the arm). At 12 printers the MVA error runs from −6.2% to +8.4% and crosses zero near cv 1, while the utilisation bound stays 8–25% high. Stall is small (about 4.6% at 8 printers), but holding the printer through load and unload plus the stall reproduces the saturated rate at 4 and 8 printers (8.59 against 8.56 ± 0.09). Stylised, illustrative times, simulation only.
A figure from its own output
Paper, code and results
More in Robot manufacturing loops
- Is a print-failure camera worth it in a robot-arm 3D-printer cell?Is a print-failure camera worth it in a robot-arm printer cell? Blind printing against abort-on-failure: +6 to 10% good parts per hour at 2 to 10 printers, none once the arm limits the cell; break-even false-stop rate. Stylised.
- Where should a print-failure detector's alarm threshold go in a robot-arm 3D-printer cell?Where should a print-failure detector's alarm threshold go in a robot-arm printer cell? A look every 2 min makes a z = 2 threshold 19 to 23% worse than blind printing; the best z is 3 to 3.5, worth +6% (d' = 2) to +11% (d' = 4). Stylised.
- Where does a flow-equivalent-server decomposition of a robot-printer cell go wrong as the inspector speeds up or slows down?Where does the flow-equivalent-server decomposition of a robot-printer cell err as the inspector speed varies? Error is 0 for fast and slow inspectors but peaks at −2% to −5% just below the knee where inspector and subsystem rates match, ten times the earlier 0.3% mean. Stylised.
- Can a flow-equivalent-server decomposition predict a robot-printer cell's throughput without enumerating its states?Can a flow-equivalent-server decomposition predict a robot-printer cell without enumerating its states? Mean error 0.3% (max 1.6%) against the exact Markov chain in 42 settings, where plain MVA is off by up to 20%. Stylised.
- Is the error of queueing analysis of a robot-printer cell from print-time variability or from the cell's structure?Is the error of queueing analysis of a robot-printer cell from print-time variability or from structure? An exact Markov chain says structure: cv 1 to 0.33 moves throughput by at most 0.71%, while plain MVA overshoots up to 20% beyond the printer count.
- Does holding the printer through load and unload fix queueing analysis of a robot-printer cell?Does adding load and unload time to the printer's demand fix MVA of the robot-printer cell? Mixed: it cuts the error at saturation (2.9% against 8.2%) but raises it elsewhere (7.3% against 3.6%), so overall plain MVA is better (4.7% against 6.2%). Stylised.
All 53 Robot manufacturing loops projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.