How long can a Unitree G1 hold a building load before its motors overheat?
research/buildbot-holdheat
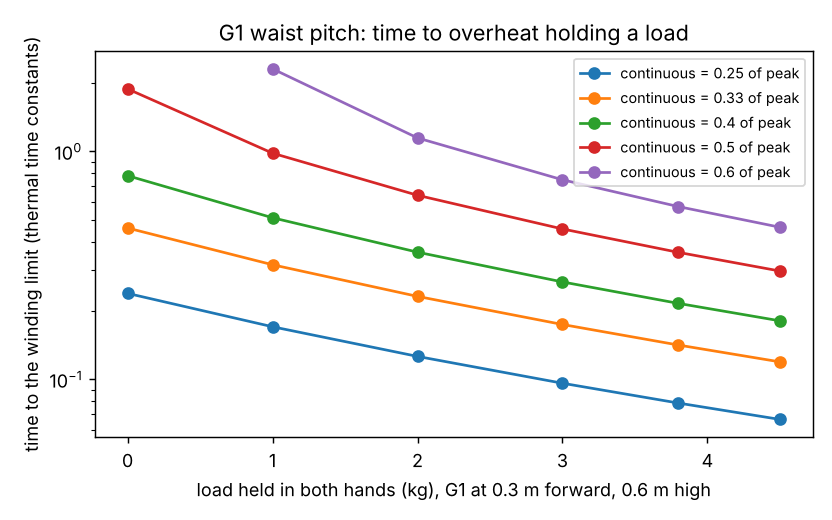
Can a stock humanoid hold a stud for a minute? G1 static joint torques re-read against a swept continuous-torque fraction: the waist is at 0.54 of peak with empty hands at the carry pose and 0.91 with a 3.8 kg stud, so below a 0.6 continuous ratio nothing is sustainable (0.6 kg at 0.6) and a stud reaches the winding limit in 0.14 thermal time constants at 1/3. A 150-pose search finds a posture (hands 0.15 m ahead, 0.7 m high) at 0.33 of peak, so the 0.91 is not the floor.
What it found
buildbot-payload checks loads against each joint's peak torque. Motors can only hold a fraction of peak indefinitely, and no continuous rating for the Menagerie G1 was found, so this sweeps the continuous/peak ratio from 0.25 to 0.6. From the MuJoCo static torques at the stud-carry pose (0.3 m ahead of the feet, 0.6 m high), the waist pitch motor already sits at 0.54 of peak with empty hands, so with a continuous rating below 0.6 of peak nothing is sustainable there, and at 0.6 only 0.6 kg is: even a 3.8 kg stud takes the waist to 0.91 of peak and, with a first-order thermal model (loss ∝ torque2), reaches its limit in 0.14 thermal time constants at a ratio of 1/3. A 3.4 kg nailer at stud height reaches 0.76 of peak; one end of a sheet with a person exceeds peak. A pose search then finds the 0.91 is posture-specific: a 150-pose grid reaches 0.33 of peak with the stud held 0.15 m ahead and 0.7 m high (wrist pitch binding, no self-collision flagged, stud geometry not modelled), which is sustainable at any ratio of 0.4 or more. Static torques only; the thermal time constant and the continuous rating are unsourced, so only dimensionless hold times are reported; not a rated runtime.
A figure from its own output
Paper, code and results
More in Robots on the building site
- Does a searched posture let a Unitree G1 hold a stud longer than the default pose?Does a searched arm and waist posture let a G1 hold a stud longer? In MuJoCo the stud's peak joint fraction falls from 0.91 (default) to 0.76 with the centre of pressure on the sole point and to 0.49 (best of three noisy seeds) 3 cm inside the toe edge, enough to make a stud sustainable at a continuous rating of 0.5 of peak; a 2x6 goes 0.93 to 0.68 and sheets stay above peak.
- Does a hand-written flexing-sheet plant agree with MuJoCo, and do its sim-to-sim transfer failures hold there?Does the hand-written flexing-sheet plant of buildbot-skills agree with MuJoCo? Pass/fail labels agree on 99.8% of 2600 episodes across 13 policies, so the sim-to-sim transfer failure (0-11% vs 81% where tuned) is not an artefact of my equations.
- Does a G1 humanoid on a drive-and-lift base nail a 4x8 sheet faster than a walking G1?Does a G1 on a drive-and-lift base nail a 4x8 sheet faster than a walking G1? Yes in 22 of 24 speed settings: 54-121 s a sheet (13 stances, 12 moves of 5-63 s) against 85-119 s walking and 372 s by hand, and it matches a 61 s gantry only with a fast tip, 0.5 m/s drive and 0.2 m/s lift (speeds swept, not a chosen machine; reach unchanged from static statics).
- How slow must a person be at nailing a sheet of sheathing for a Unitree G1 nailing it to pay?How slow must a person be at nailing a sheet of sheathing for a Unitree G1 nailing it to pay? A walking G1 (85 s a sheet) pays above 35 s of person time at 0.3 supervision, a base-mounted one above 26 to 76 s; about $110 a house, and the person's time per sheet is the unsourced unknown.
- Does a nailer's recoil slow a G1 down when it fires a whole 62-nail sheet in sequence?Does a nailer's recoil slow a G1 down when it fires a whole 62-nail sheet in sequence? Not by much: the arm is settled and back on the wall within 0.31 s at 4 N s of recoil, shorter than the 0.16 s moves only for a fast tip, so a sheet loses 0 s (2.3-2.5 s at 10 m/s2 and 4 N s) and the clean-sheet probability does not move; the stud finder still sets the budget (recoil, loop, tip speed and wall are swept, not sourced).
- What can a Unitree G1 or H1 humanoid lift on a house-building site?Can a stock humanoid carry building materials? MuJoCo static payload envelopes of the Unitree G1 (median 4.5 kg, waist-limited; matches Unitree's 2–3 kg rating) and H1 (median 14.2 kg, elbow-limited): the G1 can carry a 2x4 but not a 2x6, the H1 can take one end of an OSB or drywall sheet with a person and set a lightweight block, but not a whole sheet, a normal-weight block or a 60 lb bag, and neither reaches an 8 ft ceiling.
All 27 Robots on the building site projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.