A snapshot twin of a spinning lidar ignores that the platform moves during the sweep: how biased is the map, what does one scan reveal, and what do yaw and acceleration do?
research/sweep-twin
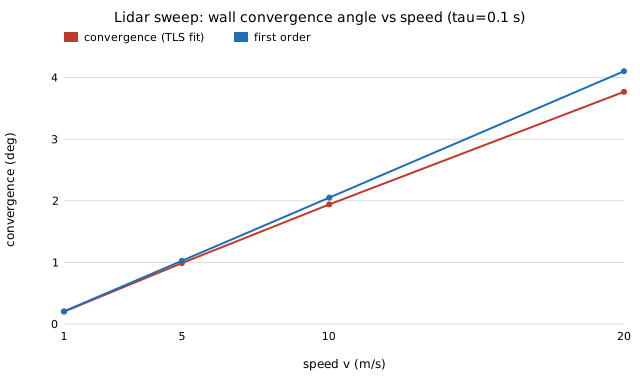
A snapshot-scan twin of a spinning lidar ignores motion during the sweep: length biased by exactly vτ/2 (0.5 m at 10 m/s), parallel walls converge by vτ/2π·(1/d₁+1/d₂), one scan gives speed to 0.13 m/s, yaw scales bearings by −κβ/(1+κ), acceleration biases odometry by a·t_f without accumulating.
What it found
Real sensor: 2-D lidar at 10 Hz firing each beam at a different time while the platform moves; twin: all beams at t = 0. At 10 m/s the front and back walls are placed 0.25 and 0.75 m short, so apparent room length is biased by exactly vτ/2 = 0.50 m while the width is exact, and deskewing with the true motion removes it. Parallel walls appear to converge by ≈ vτ/(2π)(1/d1+1/d2) (1.94° measured vs 2.05° first order), so a wall-angle estimator certified on the snapshot twin inherits a heading bias; inverting that angle recovers speed from a single scan to 0.13 m/s at 1 cm range noise (first-order bias −1.8%). Yaw scales bearings by exactly −κβ/(1+κ), and acceleration biases scan-to-scan odometry by exactly a tf in velocity, bounded and non-accumulating. Stylised: 2-D rectangular room, constant velocity or acceleration along one axis, known platform motion.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- A satellite-positioning twin with white range noise certifies an error radius the real receiver does not meet: how wrong is it once multipath is correlated, and does averaging fix it?A white-noise satellite-positioning twin vs a receiver with correlated multipath: exact HDOP
√(4/n)and bias map2b/n, averaging loses the1/√Tgain (95% radius covers 33% at T=10, 5% at T=100), and a residual integrity test tuned on the twin false-alarms 21% at equal multipath. Stylised. - A point-mass twin of a rolling body ignores rotational inertia: how wrong are acceleration, slip and coast distance, and what does one calibration fix?Point-mass twin of a rolling body ignores rotational inertia: acceleration overstated by exactly
1+k, slip thresholdk tanα/(1+k)invisible, coast distance 40–100% off, one calibration cannot fix a mixed fleet. - A pinhole twin of a radially distorted camera mis-ranges the near field: how far off does a twin-trained braking policy stop, and does focal calibration fix it?A pinhole twin of a radially distorted camera mis-ranges the floor by exactly
1/(1+k₁h²/R²)(+8.1% at 1 m fork₁=−0.3), a twin-trained braking policy stops 9 cm short of 1 m, focal calibration trades the near-field error for a far-field one, and one grid image identifiesk₁. - An instantaneous-exposure twin of a finite-exposure camera certifies detection at every speed: what is the real speed limit, and what does a blur-matched filter buy back?An instantaneous-exposure twin of a finite-exposure camera certifies detection at every speed; a moving bar is an exact trapezoid (peak
C·min(1, w/d)), a twin-tuned peak detector has a hard speed limitwC/(σz), and a blur-matched box filter raises it quadratically (5–55×). - A twin with an ideal magnetometer returns the true heading: how large is the hard-iron and soft-iron error, what does it do to a compass-held path, and how much of a turn does a swing calibration need?A twin with an ideal magnetometer hides hard/soft-iron heading error: exact peaks
asin(β/B)andasin(|1−r|/(1+r)), a compass-held square misses by exactly2Lβ/B, and swing calibration error grows ×12 at a 90° arc. Stylised. - A gyro twin calibrated on white noise hides the bias random walk: how wrong are its heading error, re-alignment interval and dead-reckoning budget, and does a single-point Allan fit help?A gyro twin calibrated on white noise hides the bias random walk: heading variance ratio exactly
1+(t/t*)²(2.33 at 100 s, 134 at 1000 s), the twin's re-alignment interval is 24× too long (10 000 s vs 416 s), a single-point Allan fit is right at one horizon only, and dead-reckoning range is over-stated 1.25–1.74×. Stylised.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.