An instantaneous-exposure twin of a finite-exposure camera certifies detection at every speed: what is the real speed limit, and what does a blur-matched filter buy back?
research/blur-twin
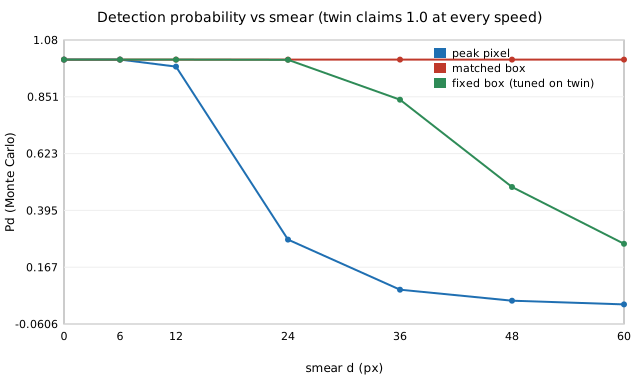
An instantaneous-exposure twin of a finite-exposure camera certifies detection at every speed; a moving bar is an exact trapezoid (peak C·min(1, w/d)), a twin-tuned peak detector has a hard speed limit wC/(σz), and a blur-matched box filter raises it quadratically (5–55×).
What it found
A bar of width w moving d = vT px during the exposure is imaged as an exact trapezoid (peak C·min(1, w/d), energy Cw conserved), matching a 2000-sub-exposure simulation to its quantisation. A single-pixel peak detector that the twin certifies at Pd = 1 everywhere loses power as soon as d > w (at w = 6, C/σ = 10: Pd 1.00 → 0.28 at d = 24), with speed limit d* = wC/(σz) (13.7 px). A box filter of length d collects all of Cw at noise cost √d, output Cw/(σ√d)·(1−w/4d), so the limit grows quadratically in SNR: 5–55× faster over 12 settings, but it needs the speed, and a filter tuned on the twin (length w) still drops to Pd 0.26 at d = 60. Stylised: 1-D, known location, constant velocity, white Gaussian noise, no real footage.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- A twin with an ideal magnetometer returns the true heading: how large is the hard-iron and soft-iron error, what does it do to a compass-held path, and how much of a turn does a swing calibration need?A twin with an ideal magnetometer hides hard/soft-iron heading error: exact peaks
asin(β/B)andasin(|1−r|/(1+r)), a compass-held square misses by exactly2Lβ/B, and swing calibration error grows ×12 at a 90° arc. Stylised. - A gyro twin calibrated on white noise hides the bias random walk: how wrong are its heading error, re-alignment interval and dead-reckoning budget, and does a single-point Allan fit help?A gyro twin calibrated on white noise hides the bias random walk: heading variance ratio exactly
1+(t/t*)²(2.33 at 100 s, 134 at 1000 s), the twin's re-alignment interval is 24× too long (10 000 s vs 416 s), a single-point Allan fit is right at one horizon only, and dead-reckoning range is over-stated 1.25–1.74×. Stylised. - A zero-wind twin of a UAV out-and-back leg: does a tailwind repay the headwind, and what does a twin calibrated on one leg say about the return?Zero-wind twin of a UAV out-and-back leg: wind does not cancel (real/twin energy
1/(1−(w/v)²)), the best airspeed moves tov²=w²+√(w⁴+1), and a one-leg-calibrated twin is off by exactly±w/vwith the sign of the leg flown. - A constant-gain twin of a motor holding a load certifies every load: what does thermal derating do to the real hold?A constant-gain twin of a motor holding a load certifies every load: magnet derating makes holding a positive thermal feedback with a fold at
λ=4/27(real temperature 1.33–2.25× the twin's near it, no hold above it, runaway in≈4π/(9√ε)thermal time constants), short tests cannot see it, the twin overstates holdable torque 1.1–1.6×, and refitting a constant gain does not remove the fold. - What does a twin whose sensor reads at any distance get wrong about a loop with a range-limited lidar or radar?A twin whose sensor reads at any distance vs a range-limited one: exact step-count law (49 vs 4021 steps from 1000R), PI overshoot neither bound nor lower bound (4.1× at 1000R), exact scale invariance, and the gain fitted from logs of a given extent.
- One long twin run or many replications when every run starts in the wrong state?One long twin run or many replications under a start-up transient: exact AR(1) MSE and t-interval coverage (single run minimises MSE; replication costs 1.07×–2.2×; 92% coverage at MSE-optimal deletion for short replications), batch means not worse, preliminary M/M/1 coverage 6–84%.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.