A gyro twin calibrated on white noise hides the bias random walk: how wrong are its heading error, re-alignment interval and dead-reckoning budget, and does a single-point Allan fit help?
research/gyro-twin
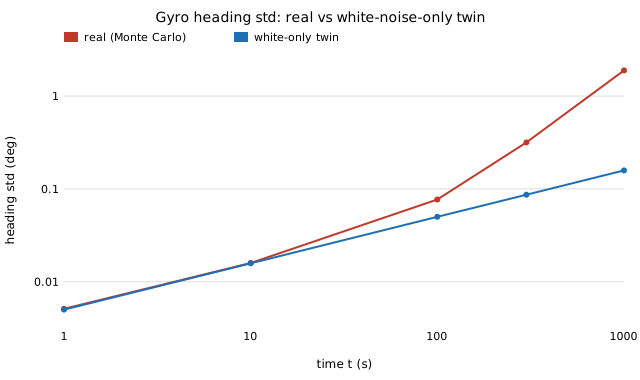
A gyro twin calibrated on white noise hides the bias random walk: heading variance ratio exactly 1+(t/t*)² (2.33 at 100 s, 134 at 1000 s), the twin's re-alignment interval is 24× too long (10 000 s vs 416 s), a single-point Allan fit is right at one horizon only, and dead-reckoning range is over-stated 1.25–1.74×. Stylised.
What it found
Real rate = white noise N plus a random-walking bias K; the twin keeps only N. Heading variance is N2t + K2t3/3, so the real/twin ratio is exactly 1 + (t/t*)2 with t* = √3N/K = 86.6 s (2.33 at 100 s, 134 at 1000 s), confirmed by Monte Carlo and a simulated Allan deviation (within 3% for short averaging times, noisy at 1000 s). Re-aligning to keep 2σ heading within 1° is needed every 416 s; the twin allows 10 000 s (24×), where the real error exceeds 1° with probability 0.986. An Allan fit at 1–10 s changes nothing; a fit at τ0 = 100 s is exact only there (variance ratio 2.3 at 1 s, 0.18 at 300 s) and one at 1000 s is 5.6× too conservative. For 2σ cross-track error within 1 m the twin reports 1.74× (1 m/s) and 1.25× (5 m/s) too much usable distance. Stylised: linear-Gaussian, one axis, parameters chosen by me, no aiding, no real IMU data.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- A zero-wind twin of a UAV out-and-back leg: does a tailwind repay the headwind, and what does a twin calibrated on one leg say about the return?Zero-wind twin of a UAV out-and-back leg: wind does not cancel (real/twin energy
1/(1−(w/v)²)), the best airspeed moves tov²=w²+√(w⁴+1), and a one-leg-calibrated twin is off by exactly±w/vwith the sign of the leg flown. - A constant-gain twin of a motor holding a load certifies every load: what does thermal derating do to the real hold?A constant-gain twin of a motor holding a load certifies every load: magnet derating makes holding a positive thermal feedback with a fold at
λ=4/27(real temperature 1.33–2.25× the twin's near it, no hold above it, runaway in≈4π/(9√ε)thermal time constants), short tests cannot see it, the twin overstates holdable torque 1.1–1.6×, and refitting a constant gain does not remove the fold. - What does a twin whose sensor reads at any distance get wrong about a loop with a range-limited lidar or radar?A twin whose sensor reads at any distance vs a range-limited one: exact step-count law (49 vs 4021 steps from 1000R), PI overshoot neither bound nor lower bound (4.1× at 1000R), exact scale invariance, and the gain fitted from logs of a given extent.
- One long twin run or many replications when every run starts in the wrong state?One long twin run or many replications under a start-up transient: exact AR(1) MSE and t-interval coverage (single run minimises MSE; replication costs 1.07×–2.2×; 92% coverage at MSE-optimal deletion for short replications), batch means not worse, preliminary M/M/1 coverage 6–84%.
- How biased is a short digital-twin run that starts from a default state?Cold-start bias of short twin runs: exact AR(1) bias/variance/warm-up deletion, M/M/1 empty-start bias constant
ρ/(1−ρ)³, negligible at valid-interval lengths but −5.6 of 9 at 50 jobs; MSER-5 did not help. - How many designs should a digital twin shortlist for real-plant verification?Shortlisting K designs in a twin and verifying the top m on the real plant under a fixed trial budget: twin-only value exactly
ρc_K, best m falls from 8 to 2 as ρ rises 0.6→0.95 (K=50, B=20), and a useless twin still gains 0.12 from budget concentration alone. Stylised.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.