How many designs should a digital twin shortlist for real-plant verification?
research/twin-screen
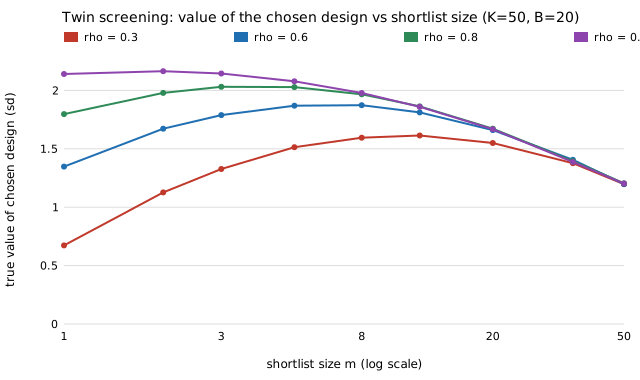
Shortlisting K designs in a twin and verifying the top m on the real plant under a fixed trial budget: twin-only value exactly ρc_K, best m falls from 8 to 2 as ρ rises 0.6→0.95 (K=50, B=20), and a useless twin still gains 0.12 from budget concentration alone. Stylised.
What it found
A twin ranks K=50 designs and a fixed budget of 20 noisy real trials verifies only the top m. The twin alone is worth exactly ρcK (cK=2.249), and the best shortlist shrinks as the twin improves (m=8 at ρ=0.6, 2 at 0.95), reaching 1.87 and 2.17 sd against 1.20 for real-only testing and an oracle 2.25. A useless twin still gains 0.12 by concentrating the budget on fewer designs, so that part is not the twin's. Stylised Gaussian model, even budget split, Monte Carlo.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- How far should a real-plant estimate be pulled toward its digital twin?Pulling a real-plant parameter estimate toward its twin (James–Stein): exact risk
d−(d−2)²E[1/(d−2+2K)], never worse in total for d≥3, perfect twin risk 2 at any d, worthn+σ²/τ²real samples at large d, but one mismatched parameter takes ≈d/4noise variances (25.5 at d=100) unless shrinkage is blockwise (1.65 at blocks of 5, d=30). - What does a twin that assumes the radar is aligned with the body get wrong about dead reckoning, and can loop-closure validation see it?A radar twin assuming the sensor is body-aligned: planar dead reckoning is exactly the true path rotated by the mount yaw (error
2 sin(e/2)·|displacement|, bounded, zero after loops, so loop-closure validation is blind), closed-form rotation fit with stdσ/√Σ|p|², but a pitched mount drifts verticallylaps·2πR sin e. - How many real rollouts does a biased digital twin save when certifying a policy?Certifying a policy with a biased digital twin: exact twin/plant cost correlation, optimal twin-to-real rollout split and speed-up (matched by simulation), bias first order but correlation second order in model error so the replayable-disturbance fraction caps the twin's value, and twin-only intervals cover ~0%.
- What does a Gaussian-clutter radar twin promise about detection, not just false alarms?What a Gaussian-clutter radar twin promises about detection: exact Pfa/Pd laws for CA- and OS-CFAR in textured clutter, OS inflated like CA, an SNR shortfall (6.3 dB at ν=2) larger than the threshold repair, and no CA/OS ranking reversal.
- How do you estimate a controller's real-world cost with a biased digital twin?Estimating a controller's real cost with a biased digital twin as a control variate: cost correlation in closed form (
0.985 → 0.472as the twin's gain error grows while its bias grows 300×), exactlyλ²under partial disturbance replay, optimal twin/real ratio√(c_rρ²/(c_t(1−ρ²)))and break-even twin price, simulated variance ratio 0.228 vs 0.225 predicted. - How fast can a deployed digital twin be caught going stale, and when is it invisible?Anytime-valid monitoring of a deployed twin: e-process on closed-loop residuals (2.3% vs 51.6% false alarms under peeking), rate = twin-transfer score gap, an invisible blind line
Δa = kΔbthat needs ditherv, and when dithering pays.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.