Can a robot fleet's reputation survive one bad incident?
research/society-trust
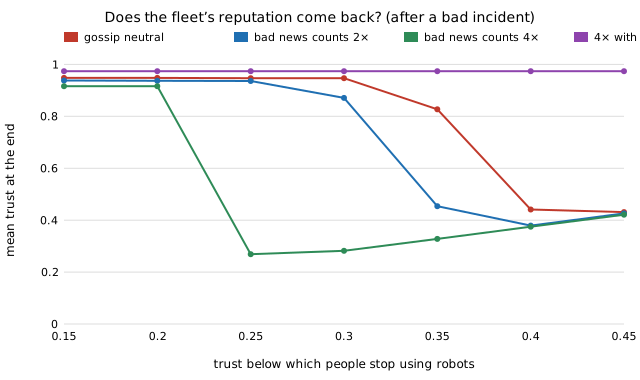
Can a robot fleet's reputation survive one bad incident? In a model where trust spreads by experience and gossip, a dent always recovers because people keep meeting robots; reputation is lost only through avoidance (at a 0.30 avoid-below threshold, 20/20, 18/20 and 0/20 crowds recover under neutral, 2× and 4× negativity in gossip), and robots that explain failures recovered every time. Stylised.
What it found
Simulated people hold trust in a robot fleet, updated by their own encounters and by gossip in which bad news may travel further than good. Trust that is only dented recovers in every case. What sinks a reputation is avoidance: if people stop using robots below a trust threshold of 0.30, an incident at error rate 0.8 is recovered in 20/20 crowds with neutral gossip, 18/20 when bad news counts 2×, and 0/20 at 4× (final mean trust 0.947, 0.871, 0.282). Robots that explain failures (each costing 0.3× the trust) recovered in every setting. Stylised: 100 simulated people, one shared reputation, a hard avoidance threshold, no fitted parameters.
A figure from its own output
Paper, code and results
More in Robot societies among people
- What does it cost robots to let people go first at a shared lift or narrow pavement?What does it cost robots to let people go first at a shared lift or narrow pavement? At load 0.9, deference cuts people's wait 6.5× (4.60 to 0.71) and raises robots' by 2.6 units; total waiting cost is conserved, so it pays only if a person's wait costs more than a robot's, and a lone defector waits far less (2.08 vs 7.65). Queueing model within 2.7% of closed forms.
- Do robot agents keep the norms they state?Do robot agents keep the norms they state? A pluggable town harness with a deterministic stub (no language model run): a robot stating "always yield" keeps it in 1 − 0.4×pressure of meetings (1.00 to 0.60), and people's cost per meeting rises from 0.20 to 1.08. Stylised.
- Does the robots-in-a-corridor conclusion survive a more humanlike crowd?Does the robots-in-a-corridor conclusion survive a more humanlike crowd? Adaptive robots stay free and committed robots never flip the crowd in all five simulated crowds, but the size of the slowdown (loss of 0.17–0.49 of desired speed at 30% robots) and of personal-space intrusions (0.03–0.36 of agent time) depends strongly on how humanlike the people are. Stylised.
- How many robots does it take to change a crowd's walking side when some people never adapt?How many robots does it take to change a crowd's walking side when some people never adapt? With 0, 20, 40 and 50% stubborn walkers the mean-field tipping share (memory 9) rises 0.217, 0.240, 0.283, 0.329, simulation agrees within 0.02, and committed-robot conflict costs barely change. Stylised.
- How many robots does it take to change a crowd's walking side when some people always walk on the robots' side?How many robots does it take to change a crowd's walking side when some people always walk on the robots' side? Each 5% of always-robot-side people cuts the memory-9 mean-field tipping share (0.217) by about 0.04, 25% tip a crowd with no robots, opposing blocs raise the bar, and simulation agrees within 0.01. Stylised.
- Does a stubborn block that slowly converts let a smaller robot minority tip a crowd's walking side?Does a stubborn block that slowly converts let a smaller robot minority tip a crowd's walking side? With 40% stubborn walkers, 24% robots never tip (0 of 12) but tip all 12 at 0.1% conversion per round (median round 721).
All 31 Robot societies among people projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.