Do door robots that learn from their own costs keep honouring an urgency cue?
research/society-learncue
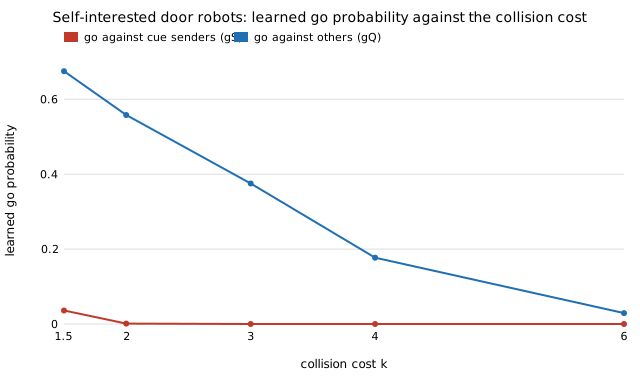
Do door robots that learn from their own costs keep honouring an urgency cue? They keep yielding to cue senders but stop going against everyone else, which erases most of the cue's gain to urgent people.
What it found
society-cheapcue gave robots a fixed rule (yield to someone sending the urgency cue, go against everyone else) that cost the robots themselves 0.29 per encounter. Here each robot learns its own go probability for cue senders (gS) and others (gQ) by a logit response to its own expected cost, with people re-equilibrating (30% robots, 20% urgent people, normal cue cost 0.6, collision cost 3, waiting and dithering cost 1). The fleet keeps honouring the cue (gS gS ≤ 0.03 in every cellle; 0.04 in every cell) but stops going against everyone else: gQ settles at 0.18 (ρ = 1) to 0.42 (ρ = 0), not 1, from three different starts. The urgent people's gain over yield-all shrinks to −0.005 at ρ = 0.25 (a small loss) and is positive (+0.18) only at ρ = 0; the crowd is still worse off than under yield-all in every setting tried (+0.006 to +0.065). A sharper robot response (logit 32) goes against others only 0.14 of the time. Assumed, not sourced: ρ, cue costs, logit sharpness, round-figure door costs, mean-field people, random pairing; robot learning is a fixed point of the response, not a simulated learning run.
A figure from its own output
Paper, code and results
More in Robot societies among people
- Do robots that learn at a door drift to going first when collisions are cheap?Do robots that learn at a door drift to going first when collisions are cheap? No: with 30% robots they settle on a mix whose go share falls smoothly with collision cost (0.51 at k = 1.5, 0.03 at k = 2.8), whatever they start from, at a higher crowd cost than a fixed yielding fleet for k of 1 or more.
- How many line-cutting robots does it take to break a queueing norm?How many line-cutting robots break a queueing norm? Mean-field critical share 12.7% (memory 9, lone-cut objection 0.9), simulation agrees; depends mostly on how fast objection fades. Stylised: objection strength is swept, not sourced.
- Does the observed rate of objection to line-cutting keep a queueing norm in a robot crowd?Do real objection rates keep a queue norm? People alone need to stop a lone cut at least 0.786 of the time; Milgram's field reactions (about 0.5, secondary source) imply 7.5% enforcer robots even with no cutters. Inputs not read from the paper; p0 is swept.
- Does a signal-reading door fleet help people once robots are not counted, and for whom?Does a signal-reading door fleet help people once robots are not counted? Only if the urgent cue costs them about a third of what it costs others, or a planner weights urgent waiting; an equal-cost cue hurts people at every weight tried.
- Can a local mean-field predict which robot blocks tip a ring crowd's passing-side convention?A deterministic local mean-field agrees with the society-allies simulation on tip/no-tip in 145 of 160 cells and is almost never too optimistic, but it overstates the share of evenly spread robots needed (0.20 against 0.12 at k = 2).
- Is the mean-field's overshoot on the ring crowd caused by finite-size noise or by memory correlation?Neither alone: a noisy memoryless map tips at 0.06 robot share for spread robots, the simulation at 0.10 and the deterministic mean-field at 0.18 (k = 2).
All 31 Robot societies among people projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.