What natural-frequency target does a printer’s rod have to meet, and what does a wooden rod cost?
research/selfrep-rodmodes
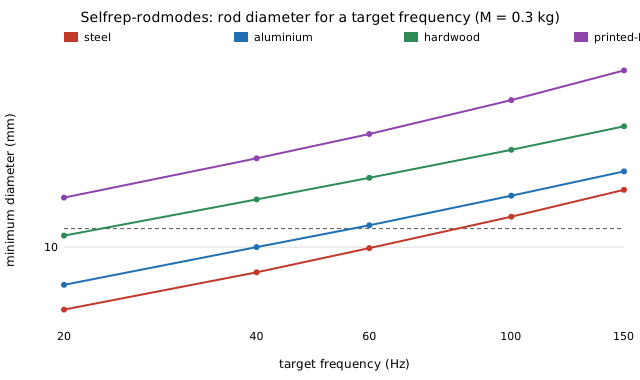
Carriage natural frequency on the Prusa Mendel's smooth rods: a vibration target, not a sag limit, sets the rod diameter; hardwood needs about twice steel's diameter (stylised).
What it found
Follow-up to selfrep-rodbeam that derives the rod spec from a vibration target instead of an assumed sag limit. A carriage mass on a simply supported rod (Rayleigh estimate with the 17/35 effective rod mass) gives a first mode of 42 Hz for 8 mm steel but 10 Hz for hardwood and 5 Hz for printed PLA, for an assumed 0.3 kg carriage. Matching steel’s frequency needs about 16 mm of hardwood, close to the sag-matching 17 mm; at equal frequency the dowel is 1.9–2.1× the steel diameter. Stylised: carriage mass and material constants are assumptions, one mode, no damping or bushing play.
A figure from its own output
Paper, code and results
More in Self-replicating manufacturing
- Does an aluminium rod fit the printer where a wooden one cannot?Aluminium rods in the printer redesign: matching a steel rod's sag takes 10.4 mm aluminium (fits the assumed 12 mm holders) against 16.9 mm hardwood (does not), at 39.5% vs 37.8% mass closure (stylised).
- How stiff a rod does a frequency target need, in aluminium and in wood?Sizing printer rods to a first-mode frequency target instead of a sag spec: at 0.3 kg aluminium reaches 40 Hz with 10.0 mm (fits the assumed 12 mm holders) where hardwood needs 16.0 mm (stylised).
- How thick must a printer rod be to keep carriage ringing small at a given acceleration?Rod diameter from an acceleration and ringing budget: at 3 m/s² with abrupt steps steel needs 7.3 mm, aluminium 9.6 mm, hardwood 15.5 mm; a 20 ms force ramp cuts aluminium at 5 m/s² from 10.9 to 8.9 mm (stylised).
- Which assumed input of the replicating-printer growth model does the doubling time depend on most?Which assumed input of the replicating-printer growth model moves its doubling time (Sobol indices, stylised, assumed ranges): budget and vitamin cost together carry ~90% of the variance when imports bind; when machine time binds, failure, print rate, budget and price are comparable.
- How does a resale value for the finished fleet move the switch from copies to goods?A resale value
sper machine at the horizon shortens the goods phase from one e-folding time1/kto1/k − s/a; ats ≥ a/kthe shop never switches. Grid optimum matches the closed form. All inputs assumed. Stylised. - Does a resale value for the finished fleet still end copying late when the goods market saturates?A resale value
sper machine with a saturating goods market (DP): at capacity c = 1000 machine-hours per hour the copy phase runs to the horizon once s is 12.5 (a quarter of a/k), and the policy that ignores s earns 14% of the optimum; the DP loses to bang-bang by under 1% where the fleet is large, so it is a lower bound there; stylised, preliminary.
All 34 Self-replicating manufacturing projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.