How stiff a rod does a frequency target need, in aluminium and in wood?
research/selfrep-alufreq
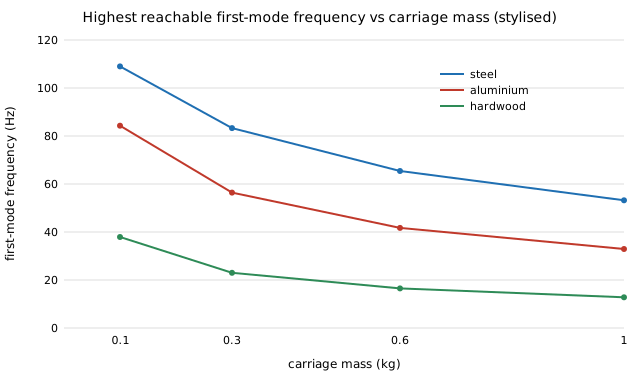
Sizing printer rods to a first-mode frequency target instead of a sag spec: at 0.3 kg aluminium reaches 40 Hz with 10.0 mm (fits the assumed 12 mm holders) where hardwood needs 16.0 mm (stylised).
What it found
Follow-up to selfrep-alurod and selfrep-rodmodes: rods of the printer redesign are sized to a first-mode frequency target (Rayleigh estimate, assumed 0.3 kg carriage) instead of a sag spec. Aluminium reaches 40 Hz with 10.0 mm, inside the assumed 12 mm holder limit, where hardwood needs 16.0 mm; within 12 mm the highest reachable frequency is 56 Hz for aluminium and 23 Hz for hardwood. Closure by mass rises with the target only because thicker stock counts as makeable, while imported stock grows from 1946 g to 2596 g. Stylised: one mode, assumed carriage mass, moduli and holder limit.
A figure from its own output
Paper, code and results
More in Self-replicating manufacturing
- How thick must a printer rod be to keep carriage ringing small at a given acceleration?Rod diameter from an acceleration and ringing budget: at 3 m/s² with abrupt steps steel needs 7.3 mm, aluminium 9.6 mm, hardwood 15.5 mm; a 20 ms force ramp cuts aluminium at 5 m/s² from 10.9 to 8.9 mm (stylised).
- Which assumed input of the replicating-printer growth model does the doubling time depend on most?Which assumed input of the replicating-printer growth model moves its doubling time (Sobol indices, stylised, assumed ranges): budget and vitamin cost together carry ~90% of the variance when imports bind; when machine time binds, failure, print rate, budget and price are comparable.
- How does a resale value for the finished fleet move the switch from copies to goods?A resale value
sper machine at the horizon shortens the goods phase from one e-folding time1/kto1/k − s/a; ats ≥ a/kthe shop never switches. Grid optimum matches the closed form. All inputs assumed. Stylised. - Does a resale value for the finished fleet still end copying late when the goods market saturates?A resale value
sper machine with a saturating goods market (DP): at capacity c = 1000 machine-hours per hour the copy phase runs to the horizon once s is 12.5 (a quarter of a/k), and the policy that ignores s earns 14% of the optimum; the DP loses to bang-bang by under 1% where the fleet is large, so it is a lower bound there; stylised, preliminary. - Is the dynamic-programming table for the replicating shop with a resale value converged, and can its policy be trusted?Grid-convergence check of the terminal-value DP: the policy's value is stable to about 0.15% from 800 to 1,600 grid points while the table value rises from 8–13% (400 points) to 2–3% (1,600) below it; a stylised fluid model, preliminary.
- How much does a smooth copy-then-sell policy beat a single switch for the replicating shop, certified without interpolation?An interpolation-free DP (the table equals its own policy's value to 1e-14): with no resale value and a saturating market a three-phase policy beats the best single switch by 4.7% (c = 1e4) to 7.1% (c = 1e3), while a resale value of 50 makes one switch optimal; a stylised fluid model, preliminary.
All 34 Self-replicating manufacturing projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.