When a pest window sets a deadline, is a scout-and-treater fleet or a fleet of inline weeding robots cheaper?
research/osrobot-deadline
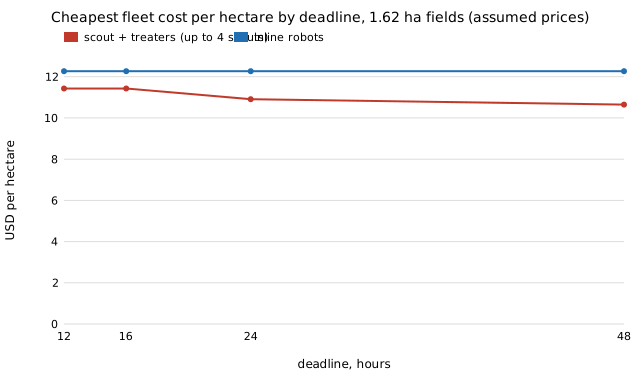
When a pest window sets a deadline, is a scout-and-treater fleet or inline weeding robots cheaper? One scout cannot finish 16 fields faster than 5.3 to 32.5 h; pipeline/inline cost is 1.06 to 1.12 at 0.72 ha, 1.49 at 0.18 ha, and 0.87 to 0.93 at 1.62 ha where it can meet the deadline.
What it found
A stdlib extension of osrobot-pipeline that adds a hard finish deadline for 16 equal fields and searches up to four scouts, up to 16 treaters and up to 32 inline robots (no new simulation; every price an assumed round number). One scout cannot finish 16 fields faster than 5.3, 15.9 and 32.5 h (0.18, 0.72, 1.62 ha fields) however many treaters it feeds, against 0.7, 2.8 and 6.2 h for 32 inline robots. Cheapest pipeline over cheapest inline: 1.06 to 1.12 at 0.72 ha, rising as the deadline tightens, and 1.49 at 0.18 ha; at 1.62 ha the pipeline is cheaper (0.87 to 0.93) at every deadline it can meet but cannot meet 8 h, where only inline robots can. Stylised: equal fields, hard cut-off, no late-yield curve.
A figure from its own output
Paper, code and results
More in Open-source purpose-built robots
- If one scout drone feeds ground treaters in a pipeline, can a held fleet beat inline weeding robots?If one scout drone feeds ground treaters in a pipeline, can a held fleet beat inline weeding robots? One scout keeps only 1.0 to 1.3 treaters busy; overlapping the stages cuts the held-pair penalty to 1.04 at 0.72 ha fields and 0.86 at 1.62 ha, still losing on small fields. Assumed prices; scheduling over
osrobot-pairprice's fits. - Is a scout drone plus a camera-less ground treater cheaper per hectare than one weeding robot, and from what field size?Is a scout drone plus a camera-less ground treater cheaper per hectare than one weeding robot? With assumed prices and each machine charged for its own minutes, break-even is near 0.5 ha and the pair is about 0.7 times the cost per hectare at 5 ha; held for the whole job it never wins; flips with utilisation, labour and battery life. Stylised, nothing built.
- Does a fast scout platform plus a ground treater beat one weeding robot, and does a mud-aware tour matter?Does a fast scout platform plus a ground treater beat one weeding robot? At matched kill (0.343) a 3 m scout swath finishes in 26.6 min against about 42 min for one inline robot, but a 1 m swath takes 47.3 min; a mud-aware tour changes nothing (stylised, simulation only).
- Does a better tour rescue scout-then-treat weeding?Does a better tour rescue scout-then-treat weeding? 2-opt cuts the tour from 539 m to 468 m but a field still takes 56.1 min against 51.7 min treating inline; scouting loses at every weed density tried (stylised, simulation only).
- For a weeding robot with a cheap camera, is it better to treat weeds as it drives or to scout first and come back, and what does a weak sensor cost?For a weeding robot with a cheap camera, is it better to treat weeds as it drives or to scout first? Scouting then touring killed the same share (0.399 against 0.401 at 1 m/s) and was slower in all 23 paired rows; lane overlap repays a weak sensor (0.40 to 0.86 killed) at 3.5 times the time. Stylised, constants assumed.
- Which open hydraulic circuit gets a small excavator closest to stock energy use for the least money?Research programme (proposal stage): pump-shaft energy of fixed open-centre, load-sensing and ideal independent-metering circuits on an illustrative excavator cycle; over 2,916 swept cases load-sensing uses a median 47% of open-centre energy and metering 80% of load-sensing, an ordering that holds by construction; on 20,000 random cycles in a machine envelope load-sensing is a median 44% of open-centre; no measured cycle, margin or price is sourced yet
All 44 Open-source purpose-built robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.