For a weeding robot with a cheap camera, is it better to treat weeds as it drives or to scout first and come back, and what does a weak sensor cost?
research/osrobot-field
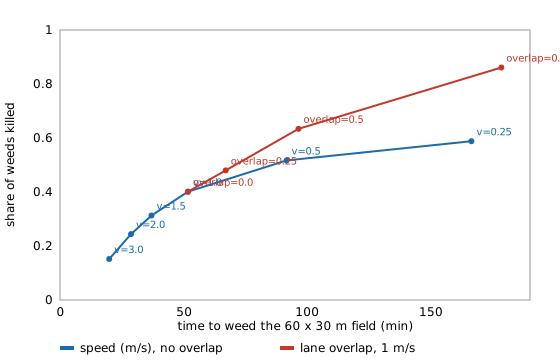
For a weeding robot with a cheap camera, is it better to treat weeds as it drives or to scout first? Scouting then touring killed the same share (0.399 against 0.401 at 1 m/s) and was slower in all 23 paired rows; lane overlap repays a weak sensor (0.40 to 0.86 killed) at 3.5 times the time. Stylised, constants assumed.
What it found
A stdlib simulation of a lane-following weeding robot on a 60×30 m field with clustered weeds, a motion-blurred noisy detector and muddy squares. Scouting then touring the targets kills the same share of weeds as treating inline (0.399 against 0.401 at 1 m/s) and is slower in all 23 paired rows, by 2.8 to 7.8 min. Lane overlap repays a weak sensor at a steep price: 0 to 0.75 overlap raises the kill share from 0.40 to 0.86 and the time from 52 to 178 min; no grid configuration reaches a 0.9 kill share at a 0.5 hit rate. Stylised: every constant is assumed, the speed results move with the blur assumption, and the planner comparison is a statement about this cost model.
A figure from its own output
Paper, code and results
More in Open-source purpose-built robots
- Which open hydraulic circuit gets a small excavator closest to stock energy use for the least money?Research programme (proposal stage): pump-shaft energy of fixed open-centre, load-sensing and ideal independent-metering circuits on an illustrative excavator cycle; over 2,916 swept cases load-sensing uses a median 47% of open-centre energy and metering 80% of load-sensing, an ordering that holds by construction; on 20,000 random cycles in a machine envelope load-sensing is a median 44% of open-centre; no measured cycle, margin or price is sourced yet
- Collision avoidance that obeys the rules of the road: velocity obstacles against rule-based and sampling MPC for a small boatOn 115 scripted COLREGs encounters a rule-aware velocity-obstacle planner passes at least 100 m in 95.7% (rule-based 77.4%, sampling MPC 84.3%), but its safe share falls to 82-85% when the target's velocity estimate is off by 0.3 to 0.6 m/s, and the stand-on vessel's action range matters most: 91% at 200 m, 99% at 600 m
- Which body carries a survey payload furthest per kWh? Hull choice for small autonomous boatsResearch programme (proposal stage): energy per survey kilometre of hull types for 100 to 500 kg autonomous boats; with a Michell wave term a catamaran out-ranges a monohull in 3.3% of 6,561 cases, none at equal length; with Slocum coefficients from the gliderflight package a glider never out-ranges a same-mass propeller AUV at equal hotel load (0 of 2,430 cases); it breaks even when the AUV's hotel load is about 5 times its own; a REMUS-100-class AUV's non-propulsion load implied by vendor endurance is 104 to 175 W, far above that, so the glider out-ranges it in every case on energy per metre (at a tenth of the speed); a Savitsky planing hull reaches at most 0.14 of the monohull range (0 of 48 cases); a SWATH (two submerged torpedoes on struts) out-ranges the monohull in none of 4,374 swept pairs; charging panel mass to the battery (2 to 10 kg/m2, swept) cuts the median solar range multiplier from 2.01 to 1.64 at worst, and the full deck stays the best array wherever range is finite; against ten years of daily NASA POWER insolation a threshold speed policy (slow or hold when the pack is under 30%) never raises km/day over a fixed 1 m/s but cuts pack-empty days, e.g. 25.4% to 1.5% for a 4 m boat at 25 N
- Holding a survey line in current and waves: line-of-sight against integral line-of-sight for a small boatPlain line-of-sight guidance leaves a steady cross-track offset of delta*tan(asin(c/U)) in a cross current c (simulation matches it to 1%: 3.77 m at 0.3 m/s, 12 m look-ahead); integral LOS removes it, with lower rms cross-track error in 136 of 144 cross-current cases and the 8 exceptions all at a 6 m look-ahead with integral gain 2, where it oscillates (rms about 2.3 m even in still water)
- If a late field loses yield instead of failing a hard deadline, does a scout-and-treater fleet still lose to inline weeding robots?Replaces the hard deadline of osrobot-deadline with a 2% yield loss per leaf stage of delay (Knezevic et al. 2003): the best pipeline costs 1.06 to 1.20 times the best inline fleet at 0.72 ha and 1.49 to 1.51 at 0.18 ha, and at 1.62 ha inline is cheaper when the window closes by 8 h and the pipeline from 12 h
- What does a 2-joint feeding arm cost against a 6-joint one once the whole bill of materials is priced?What does a 2-joint feeding arm cost against a 6-joint one once the whole bill of materials is priced? About 1.8 times, not 3: $66 against $122 at the SO-ARM101 table's $13.89 servo, rising to 2.4 times at a $49 retail servo.
All 44 Open-source purpose-built robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.