Does a fast scout platform plus a ground treater beat one weeding robot, and does a mud-aware tour matter?
research/osrobot-scoutpair
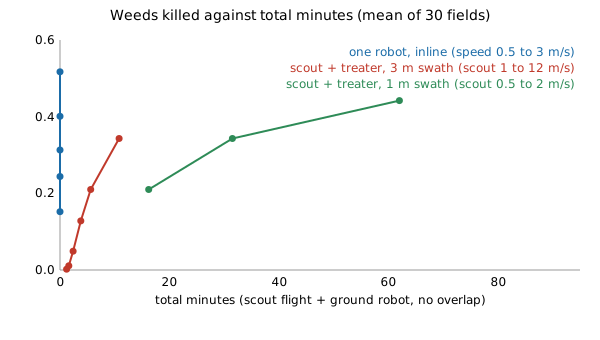
Does a fast scout platform plus a ground treater beat one weeding robot? At matched kill (0.343) a 3 m scout swath finishes in 26.6 min against about 42 min for one inline robot, but a 1 m swath takes 47.3 min; a mud-aware tour changes nothing (stylised, simulation only).
What it found
A stdlib follow-up to osrobot-fieldtour that makes the scout a second platform with its own swath and detector, then compares at matched kill because both platforms lose detections as they speed up. With a 3 m scout swath at 1 m/s the pair kills 0.343 in 26.6 min against about 42 min for one inline robot interpolated to the same kill; with the scout's swath cut to the ground robot's 1 m the same kill takes 47.3 min and the pair loses by about 13%. The saving is the swath ratio, not the second vehicle. A mud-aware tour changes the total by 0.1 min or less at 0 to 80% mud. Assumed constants, no registration error and no pipelining or capital cost: stylised, simulation only.
A figure from its own output
Paper, code and results
More in Open-source purpose-built robots
- Does a better tour rescue scout-then-treat weeding?Does a better tour rescue scout-then-treat weeding? 2-opt cuts the tour from 539 m to 468 m but a field still takes 56.1 min against 51.7 min treating inline; scouting loses at every weed density tried (stylised, simulation only).
- For a weeding robot with a cheap camera, is it better to treat weeds as it drives or to scout first and come back, and what does a weak sensor cost?For a weeding robot with a cheap camera, is it better to treat weeds as it drives or to scout first? Scouting then touring killed the same share (0.399 against 0.401 at 1 m/s) and was slower in all 23 paired rows; lane overlap repays a weak sensor (0.40 to 0.86 killed) at 3.5 times the time. Stylised, constants assumed.
- Which open hydraulic circuit gets a small excavator closest to stock energy use for the least money?Research programme (proposal stage): pump-shaft energy of fixed open-centre, load-sensing and ideal independent-metering circuits on an illustrative excavator cycle; over 2,916 swept cases load-sensing uses a median 47% of open-centre energy and metering 80% of load-sensing, an ordering that holds by construction; on 20,000 random cycles in a machine envelope load-sensing is a median 44% of open-centre; no measured cycle, margin or price is sourced yet
- Collision avoidance that obeys the rules of the road: velocity obstacles against rule-based and sampling MPC for a small boatOn 115 scripted COLREGs encounters a rule-aware velocity-obstacle planner passes at least 100 m in 95.7% (rule-based 77.4%, sampling MPC 84.3%), but its safe share falls to 82-85% when the target's velocity estimate is off by 0.3 to 0.6 m/s, and the stand-on vessel's action range matters most: 91% at 200 m, 99% at 600 m
- Which body carries a survey payload furthest per kWh? Hull choice for small autonomous boatsResearch programme (proposal stage): energy per survey kilometre of hull types for 100 to 500 kg autonomous boats; with a Michell wave term a catamaran out-ranges a monohull in 3.3% of 6,561 cases, none at equal length; with Slocum coefficients from the gliderflight package a glider never out-ranges a same-mass propeller AUV at equal hotel load (0 of 2,430 cases); it breaks even when the AUV's hotel load is about 5 times its own; a REMUS-100-class AUV's non-propulsion load implied by vendor endurance is 104 to 175 W, far above that, so the glider out-ranges it in every case on energy per metre (at a tenth of the speed); a Savitsky planing hull reaches at most 0.14 of the monohull range (0 of 48 cases); a SWATH (two submerged torpedoes on struts) out-ranges the monohull in none of 4,374 swept pairs; charging panel mass to the battery (2 to 10 kg/m2, swept) cuts the median solar range multiplier from 2.01 to 1.64 at worst, and the full deck stays the best array wherever range is finite; against ten years of daily NASA POWER insolation a threshold speed policy (slow or hold when the pack is under 30%) never raises km/day over a fixed 1 m/s but cuts pack-empty days, e.g. 25.4% to 1.5% for a 4 m boat at 25 N
- Holding a survey line in current and waves: line-of-sight against integral line-of-sight for a small boatPlain line-of-sight guidance leaves a steady cross-track offset of delta*tan(asin(c/U)) in a cross current c (simulation matches it to 1%: 3.77 m at 0.3 m/s, 12 m look-ahead); integral LOS removes it, with lower rms cross-track error in 136 of 144 cross-current cases and the 8 exceptions all at a 6 m look-ahead with integral gain 2, where it oscillates (rms about 2.3 m even in still water)
All 44 Open-source purpose-built robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.