Does inverting a quadratic thrust curve exactly fix the error a linear-thrust twin makes, and what if the thrust exponent is also wrong?
research/invthrust-twin
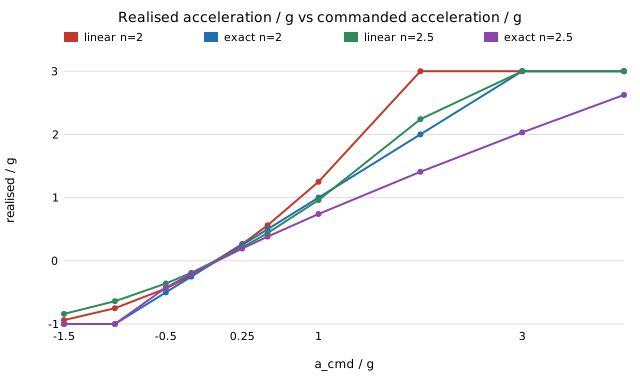
Exact square-root thrust inverse vs the linear one on a quadratic-thrust vehicle: up/down overshoot gap 3.00→0.09 points with the right model, but only 3.67→1.65 when the thrust exponent is misidentified (2.5 vs 2).
What it found
Follow-up to thrust-twin. With the right model, the exact square-root throttle inverse realises the commanded acceleration inside the throttle limits and shrinks the up/down overshoot gap at ζ=0.7, p=2 from 3.00 to 0.09 points. With the thrust exponent misidentified (2.5 instead of 2) the exact inverse flips the asymmetry and halves the gap (3.67 to 1.65 points) but overshoot stays at 0.071–0.088 against the twin’s 0.046, and settling time is unchanged. Stylised: 1-D, noiseless, static thrust map, assumed throttle limits, exponent error only.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- How much does a wrong process-noise guess cost a Kalman filter?How much does a wrong process-noise guess cost a Kalman filter? Exact scalar steady state: under-guessing
qby ×100 costs ×7.4 MSE, over-guessing by ×100 only ×1.6 (bounded byr), and the under-guessing filter reports 5× too-small error bars. Stylised. - Do low-discrepancy scenarios make a twin evaluate a policy more accurately than iid domain randomisation?Do low-discrepancy scenarios beat iid domain randomisation for evaluating a policy in a twin? Latin hypercubes only cut MSE 1.6–12× (rate stays
n^-0.5); shifted Halton changes the rate for smooth returns (149× lower MSE at d=2) and keeps 4–24× on a success-rate jump, shrinking with d; theR_dlattice is erratic at d=5; 95% intervals from 8 randomisations cover 94–97%. Stylised. - Why does the Rd low-discrepancy lattice lose its advantage at d = 5 when evaluating a twin policy?Why does the
R_dlow-discrepancy lattice lose its edge at d=5 when scoring a twin policy? Not a seed fluke (exponent −0.45 ± 0.01 over six seeds) and not a smooth dimension effect (a dip between d=4 and d=6); a√pgenerator gets −0.66 at d=5. A simple resonance score does not explain it. Stylised. - How long does a float32 twin of a chaotic system shadow the float64 one, and do its statistics survive?How long does a float32 twin of a chaotic system shadow the float64 one, and do its statistics survive? Lorenz and Rössler: float32 departs from float64 after a median 12.3 and 164 time units, like a float64 start error of about 5×10⁻⁶ (100× the float32 roundoff), but the Lyapunov exponent and time-averaged statistics agree within sampling error (stylised).
- Does a float32 simulation of a bouncing, chaotic system lose its statistics? Sinai billiard against float64Does a float32 simulation of a bouncing, chaotic system lose its statistics? Sinai billiard: float32 leaves the float64 trajectory after a median 21 collisions, like a float64 start error of about one unit roundoff, and changes the event order one collision later, but the mean free path and circle-hit share agree with float64 and with Cauchy's exact value (stylised).
- How many research READMEs admit their citations are unchecked, and which works need checking first?Audit of how many research READMEs flag a citation as unchecked: 94 of 550 (17.1%), with Dawid and Skene (1979), Zhang et al. (2019), Horowitz (2014) and Horvitz (1999) the most repeated; counts admissions only, nothing verified.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.