How much does a wrong process-noise guess cost a Kalman filter?
research/free-kfmismatch
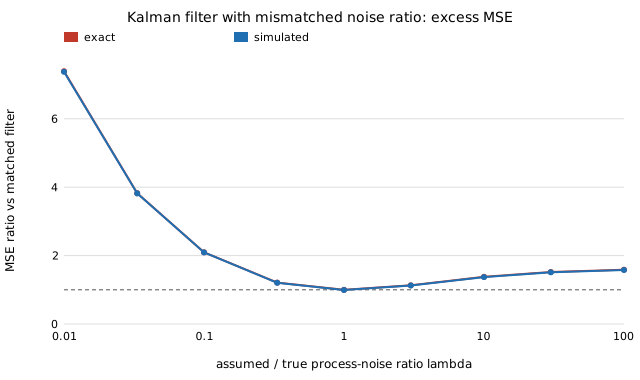
How much does a wrong process-noise guess cost a Kalman filter? Exact scalar steady state: under-guessing q by ×100 costs ×7.4 MSE, over-guessing by ×100 only ×1.6 (bounded by r), and the under-guessing filter reports 5× too-small error bars. Stylised.
What it found
Exact steady-state MSE of a scalar Kalman filter run at the wrong process noise qa = λq, matched to simulation within 1%. Underestimating costs far more than overestimating: at λ = 1/100 the excess is ×7.4 against ×1.6 at λ = 100; the over-estimate is bounded (MSE → r) and the under-estimate is not. The filter’s claimed variance is 5× too small at λ = 1/10. The gap closes at high signal-to-noise. Textbook-level and stylised: scalar, steady state, Gaussian.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- Do low-discrepancy scenarios make a twin evaluate a policy more accurately than iid domain randomisation?Do low-discrepancy scenarios beat iid domain randomisation for evaluating a policy in a twin? Latin hypercubes only cut MSE 1.6–12× (rate stays
n^-0.5); shifted Halton changes the rate for smooth returns (149× lower MSE at d=2) and keeps 4–24× on a success-rate jump, shrinking with d; theR_dlattice is erratic at d=5; 95% intervals from 8 randomisations cover 94–97%. Stylised. - Why does the Rd low-discrepancy lattice lose its advantage at d = 5 when evaluating a twin policy?Why does the
R_dlow-discrepancy lattice lose its edge at d=5 when scoring a twin policy? Not a seed fluke (exponent −0.45 ± 0.01 over six seeds) and not a smooth dimension effect (a dip between d=4 and d=6); a√pgenerator gets −0.66 at d=5. A simple resonance score does not explain it. Stylised. - How long does a float32 twin of a chaotic system shadow the float64 one, and do its statistics survive?How long does a float32 twin of a chaotic system shadow the float64 one, and do its statistics survive? Lorenz and Rössler: float32 departs from float64 after a median 12.3 and 164 time units, like a float64 start error of about 5×10⁻⁶ (100× the float32 roundoff), but the Lyapunov exponent and time-averaged statistics agree within sampling error (stylised).
- Does a float32 simulation of a bouncing, chaotic system lose its statistics? Sinai billiard against float64Does a float32 simulation of a bouncing, chaotic system lose its statistics? Sinai billiard: float32 leaves the float64 trajectory after a median 21 collisions, like a float64 start error of about one unit roundoff, and changes the event order one collision later, but the mean free path and circle-hit share agree with float64 and with Cauchy's exact value (stylised).
- How many research READMEs admit their citations are unchecked, and which works need checking first?Audit of how many research READMEs flag a citation as unchecked: 94 of 550 (17.1%), with Dawid and Skene (1979), Zhang et al. (2019), Horowitz (2014) and Horvitz (1999) the most repeated; counts admissions only, nothing verified.
- How much does noisy scoring cost the secretary problem, and should the 1/e cutoff move?How much noisy scoring costs the secretary problem: with n = 50 the best cutoff stays at 16–17 (19 noiseless) while P(best) falls from 0.373 to 0.145 at noise 1; cutoff rules only, simulation.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.