Where does a new home's price go, and which levers move it most?
research/house-cost
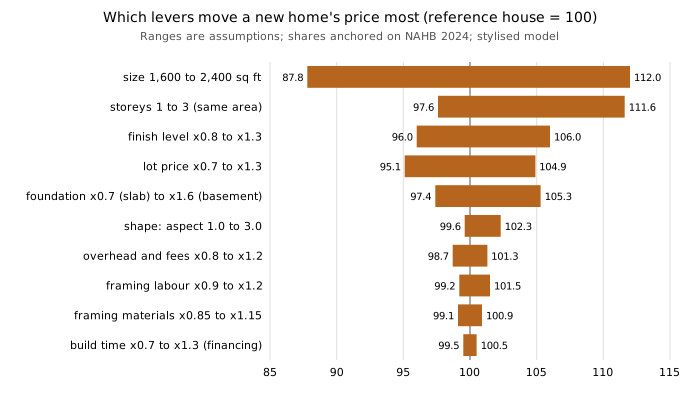
Where does a new home's price go, and which levers move it most? Share-anchored model (NAHB 2024): size moves the price most (87.8 to 112.0 for 1,600 to 2,400 sq ft), then storeys, finish level and lot; a 14% framing-lumber cut is worth 0.85% of price (2.4% with labour). Index not dollars, assumed driver splits. Milestone 4 of track 12.
What it found
A driver-based price model anchored on NAHB's 2024 cost shares (construction 64.4% of the price, framing 16.6% of construction, lot 13.7%, profit 11.0%). Each construction stage scales with floor area, footprint or wall area, and the model reproduces every NAHB share at its 2,000 sq ft reference house. In a sweep, size moves the price most (index 87.8 to 112.0 for 1,600 to 2,400 sq ft), then one against three storeys (111.6 to 97.6), finish level, lot price and foundation type. A 14% cut in framing lumber, the gap between house-plan's default and best plans, is worth only 0.85% of the price, or 2.4% if it also cuts framing labour by 20%. Stylised: a price index, not dollars; the stage-driver splits and lever ranges are my assumptions; the Census reconciliation and a priced takeoff are not done.
A figure from its own output
Paper, code and results
More in Open-source residential construction
- Does the house-cost lever ranking survive its assumed driver splits?Does the house-cost lever ranking survive its assumed driver splits? Monte Carlo over the splits: floor area stays the largest lever in 96–100% of draws; storeys is the soft claim (swing 9.0–19.9 vs 14.0 baseline); the lumber result does not move. Index not dollars.
- Which uncertain input of the house-cost model drives the uncertainty in a house's price?Which uncertain input of the house-cost model drives a house's price uncertainty? Sobol indices over every lever range, the framing share and the driver splits at once: floor area 53% of variance, storeys 19%, all framing inputs together under 1%. Index not dollars.
- Which envelope upgrades pay for themselves over 30 years, by climate, and does advanced framing belong in the answer?Which envelope upgrades pay back over 30 years, by climate? A degree-day net-present-cost search of 640 packages in eight climates: advanced 2x6 framing is in every optimum (13–15% lower cost than a 2x4 baseline); better windows and R-49 attics do not pay at assumed prices. Stylised, assumed prices, not EnergyPlus.
- Does any alternative to a wood-framed wall beat it on cost, carbon or heat loss for a small house?Does any alternative to a wood-framed wall beat it on cost, carbon or heat loss for a small house? In a stylised model wood 2x6 is cheapest in 97% of random draws and lowest-carbon in 100%; SIP, CLT and printed walls win only on labour. Inputs are ranges from memory.
- Does a small wood-frame house have enough shear wall for wind and earthquakes once the windows and doors are cut out?Does a small wood-frame house have enough shear wall for wind and earthquakes once the openings are cut out? At 115 mph and SDS 0.50 the 28 x 40 ft house uses 19% of a gable-wall line's capacity at 6 in nailing; the openings, not the load, are what shrink it. Stylised, capacities from memory.
- How much does accidental torsion add to the garage-front wall's demand in a rigid-diaphragm wind split?How much does accidental torsion add to the garage-front wall's demand in a rigid-diaphragm wind split? Offsetting the load up to 15% of the length in
house-nailedwall's split raises a 22 ft-door wall from 0.36–0.59 to 0.44–0.71 demand over capacity, still under the flexible 1.05. Stylised.
All 41 Open-source residential construction projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.