Does a small wood-frame house have enough shear wall for wind and earthquakes once the windows and doors are cut out?
research/house-structure
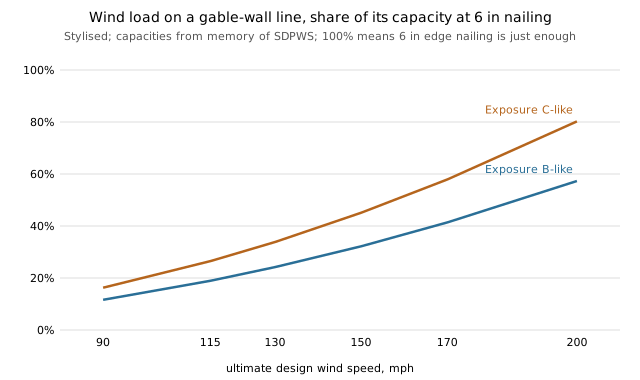
Does a small wood-frame house have enough shear wall for wind and earthquakes once the openings are cut out? At 115 mph and SDS 0.50 the 28 x 40 ft house uses 19% of a gable-wall line's capacity at 6 in nailing; the openings, not the load, are what shrink it. Stylised, capacities from memory.
What it found
Wind and seismic base shear on the house-framing house (28 × 40 ft, one storey) against the segmented shear-wall length its openings leave. At 115 mph and SDS 0.50 the worst case uses 19% of a gable-wall line's capacity at the loosest (6 in) nailing; wind must reach 264 mph before that nailing runs out. Lateral load does not govern this plan, but glazing does: four windows per gable wall cut the usable wall from 24 ft to 11 ft, six leave none. A 16 ft garage door in the gable wall raises the load share to 41% at 6 in nailing, and a centred 22 ft door needs tighter nailing. Advanced and conventional framing carry the same shear. Stylised: the nailing table and load coefficients are from memory and unchecked, and diaphragms, uplift and overturning are not modelled.
A figure from its own output
Paper, code and results
More in Open-source residential construction
- How much does accidental torsion add to the garage-front wall's demand in a rigid-diaphragm wind split?How much does accidental torsion add to the garage-front wall's demand in a rigid-diaphragm wind split? Offsetting the load up to 15% of the length in
house-nailedwall's split raises a 22 ft-door wall from 0.36–0.59 to 0.44–0.71 demand over capacity, still under the flexible 1.05. Stylised. - Does the rigid-diaphragm relief for a garage-front wall survive a nailed-wall stiffness model?Does the rigid-diaphragm relief for a garage-front wall survive a nailed-wall stiffness model? Four-term pier deflection (bending, shear, nail slip, hold-down) in
house-diaphragm's rigid split: yes; a centred 22 ft door falls from 1.05 (flexible) to 0.36–0.59 demand over capacity. Stylised. - Does the half-and-half load split understate the demand on a garage-front wall?Does the half-and-half load split understate the demand on a garage-front wall? In a toy stiffness model a rigid roof diaphragm gives the garage line less than half, so the flexible split governs; stylised, torsion not modelled.
- What does an open, reproducible plan set for a 480 sq ft backyard cottage look like when it is generated from code?What does an open plan set for a 480 sq ft backyard cottage look like when generated from code? A 24 x 20 ft ADU composed from the track's models: drawings, bill of materials, IFC, lateral check, envelope energy (a tight envelope cuts modelled heating and cooling cost 36-37%) and a cost index. A worked example, not a buildable design; every input assumed.
- At what climate does each envelope upgrade start to pay, when climate is a continuous axis?At what climate does each envelope upgrade start to pay? Climate as a continuous axis over
house-energy's model: slab-edge R-10 from 3,271 heating degree-days with gas (2,386 with a heat pump), 3 ACH50 from 5,769, and cooling alone switches on only the attic and air sealing above ~3,000 cooling degree-days. Stylised: unsourced prices, no solar gain. - How much extra can a tight envelope cost before it stops paying back on a 480 sq ft backyard cottage?How much extra can a tight envelope cost before it stops paying back on a 480 sq ft backyard cottage? The ADU's whole upgrade package can carry $1,409 to $3,104 of extra first cost (3% real rate, heat pump); at assumed prices only the wall switch clearly pays. Stylised.
All 41 Open-source residential construction projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.