How often can a wearer pick the wrong garment before a second garment stops paying?
research/garment-wearwrong
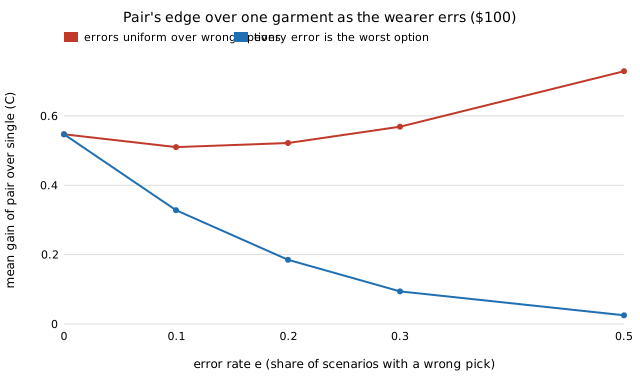
How often can a wearer pick the wrong garment before a second garment stops paying? With random wrong picks the pair's edge over one garment holds (+0.57 C at 30% error, $100); if every mistake is the worst option it falls from +0.55 to +0.09 C (stylised).
What it found
Re-runs the two-garment wardrobe search of garment-wearpair with a wearer who picks a wrong option in a share e of scenarios, re-optimising each purchase at each e (replica trench, 66 wearing mixes, thin cloth removed). If a wrong pick is a random wrong option the pair’s edge holds (+0.55 C at e = 0, +0.57 C at 0.3, $100 budget), because errors hurt a single garment’s all-or-nothing choice more than an overlapping pair. If every mistake is the worst owned option the $100 edge falls to +0.09 C at e = 0.3, with a break-even e of median 0.72 and as low as 0.04. At $50 the edge is negligible either way. Stylised: error rates and premiums are assumed, no wearer behaviour was observed, and the conclusion flips between the two error models.
A figure from its own output
Paper, code and results
More in Engineered clothing
- How much conductive yarn does an RF-shielding fabric need, and how fast does breakage ruin it?RF-shielding weave model: 54–87 dB sheet shielding but the aperture bound caps it (36 dB at 2.4 GHz for 1 mm pitch, ~15 dB at 28 GHz); yarn breakage tracks 1/(1−2f) and conduction fails near 50% broken. Stylised; plane wave, ideal crossings, RF part only.
- Does contact resistance at yarn crossings matter for an RF-shielding fabric?Contact resistance at yarn crossings in the RF-shielding weave: no effect on an intact fabric, but with 20% of yarns broken a contact equal to one segment raises sheet resistance 22% and ten segments 2.3×. Stylised; contact values are a sweep, not measured.
- Does it matter where an RF-shielding fabric is damaged, and whether worn contacts go with the breaks?Correlated damage in the RF-shielding weave: worn contacts next to breaks (rc×10) raise the median sheet resistance at 20% broken from 2.05 to 3.03 segments; a fold band across the current direction at the same mean breakage leaves 57 of 60 draws open, while a fold along it helps. Stylised; wear multiplier is a sweep, not measured.
- How thin must a coating be to colour a fibre without dye, and how fragile is that colour?Thin-film transfer-matrix structural colour on a nylon-like substrate: 6-pair stacks reach 99% reflectance with 2–3 g/m² of oxide but blue-shift 48 ΔE by 60° incidence, and 10% layer-thickness error moves hue by ΔE≈10. Stylised; flat substrate, no dispersion.
- Can an optimiser cut the angle shift of a structural-colour coating, and what does it give up?Optimising 8-layer thin-film stacks for low angle shift at fixed colour: Nelder–Mead restarts cut mean ΔE76 shift from 12.4 to 1.4 (red) and 25.9 to 5.6 (blue) at 3000 evaluations, beating random search and differential evolution, at the cost of chroma and ~1.8–2.5× oxide mass. Stylised; flat substrate, no tolerance.
- Does an angle-stable structural-colour stack survive layer-thickness error?Thickness-error robustness of the
garment-stackoptangle-stable stacks: the nominal optimum (J 1.4) degrades to 24.9 at 3% layer error and loses to the quarter-wave stack; a sampled robust objective at equal cost recovers part of it (red, 3%: 11.7 vs 13.2 quarter-wave) but not colour drift. Stylised; independent Gaussian errors, 10 seeds.
All 45 Engineered clothing projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.