Can an optimiser cut the angle shift of a structural-colour coating, and what does it give up?
research/garment-stackopt
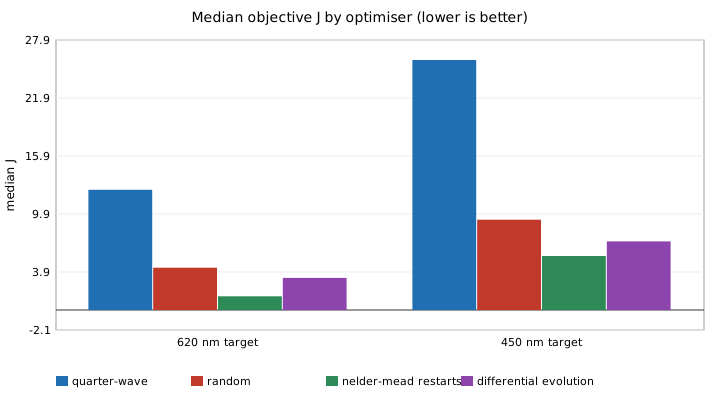
Optimising 8-layer thin-film stacks for low angle shift at fixed colour: Nelder–Mead restarts cut mean ΔE76 shift from 12.4 to 1.4 (red) and 25.9 to 5.6 (blue) at 3000 evaluations, beating random search and differential evolution, at the cost of chroma and ~1.8–2.5× oxide mass. Stylised; flat substrate, no tolerance.
What it found
Eight-layer thin-film stacks on a flat nylon-like substrate, optimised to minimise the colour shift between 0 and 15–45° incidence while keeping chroma C* ≥ 40 and hue near a quarter-wave target. At an equal budget of 3000 evaluations (10 seeds), Nelder–Mead with restarts cuts the median mean ΔE76 shift from 12.4 to 1.4 (red target) and from 25.9 to 5.6 (blue), beating random search and differential evolution, but chroma falls toward the floor and oxide mass rises about 1.8–2.5×. Stylised: flat substrate, three sample angles, recalled indices, no fabrication tolerance; no LLM involved.
A figure from its own output
Paper, code and results
More in Engineered clothing
- Does an angle-stable structural-colour stack survive layer-thickness error?Thickness-error robustness of the
garment-stackoptangle-stable stacks: the nominal optimum (J 1.4) degrades to 24.9 at 3% layer error and loses to the quarter-wave stack; a sampled robust objective at equal cost recovers part of it (red, 3%: 11.7 vs 13.2 quarter-wave) but not colour drift. Stylised; independent Gaussian errors, 10 seeds. - Does a tail-risk objective, or a correlated-error model, rescue the angle-stable structural-colour stack?Negative follow-up to
garment-stackrobust: a CVaR (worst-quarter) training objective and a correlated rate-drift error model do not rescue the optimised angle-stable stacks; none beats the quarter-wave stack (red, iid error: mean J 14.1 vs best optimised 16.5). CVaR trims Nelder-Mead's 90th-percentile cost (47.1 to 43.1) at the price of the mean. Stylised; no coating measured. - How much angle shift can a structural-colour coating shed at a given chroma and oxide mass?Shift against chroma and oxide mass for the
garment-stackopt8-layer coating: on a grid of chroma floors and mass caps, the best red-target shift is 0.68 at a 4.0 g/m² cap but 2.71 at 3.0 and no feasible run at 2.0 or below (floor C* 40); mass binds before chroma. Stylised; 5 seeds per cell, one optimiser. - Does adding layers cut the angle shift of a structural-colour coating at fixed chroma and oxide mass?Layer-count sweep (2 to 12) of the constrained structural-colour coating: six to ten layers reach best angle shifts under 1 dE at C* 40 and 4 g/m2 where 2 and 4 layers stay near 3.4, but 12 layers did not search well at the same budget (stylised, 8 seeds).
- Does an assistive garment pay for its own mass?One-joint ankle exosuit model: active assist cuts modelled whole-body cost 3–14% (gain 0.1–0.5) but a few kg of garment mass erases it; break-even mass ∝ 1/(mass sensitivity). Stylised; assumed constants, no OpenSim/MyoSuite.
- Is it the motor or the battery that decides whether an exosuit pays for its own mass?Adds a motor and battery mass model to the ankle exosuit: at an assumed 8 N m/kg the motor (about 8 kg) makes a gain-0.3 suit raise cost 0.2–1.9%; the sign flips between 8 and 20 N m/kg, battery hours matter little. Stylised; assumed constants.
All 45 Engineered clothing projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.