Which sensors in a smart garment recognise what you are doing, and how fragile is that to garment slip?
research/garment-smart
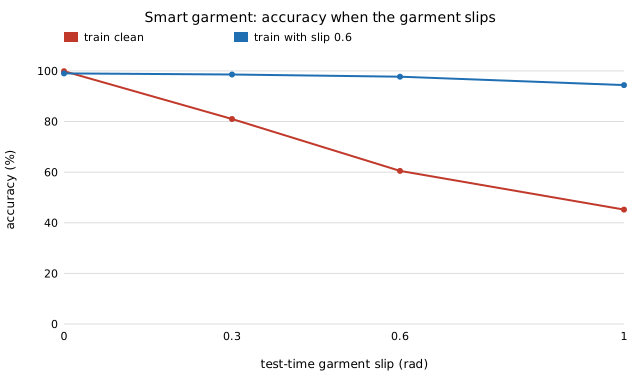
Activity recognition from simulated chest/thigh/wrist IMUs and knee/elbow strain: two sensors reach ~99% and all five 99.9% on easy synthetic classes, but a clean-trained model falls to 45% under 1 rad garment slip (94% when trained with slip). Stylised; invented signals, no real dataset.
What it found
Synthetic chest, thigh and wrist accelerometers and knee and elbow strain channels, six activities, a softmax classifier on spectral features and unseen simulated people. Two sensors reach about 99% and all five 99.9%, because the invented classes are easy to separate. A model trained on clean data falls to 81, 61 and 45% when the IMUs rotate by 0.3, 0.6 and 1.0 rad (a garment slipping), while training with 0.6 rad of slip holds 94–99%. Strain-only stays at 97% under slip by construction. Stylised: sinusoidal signals, no real dataset, no drift or hysteresis.
A figure from its own output
Paper, code and results
More in Engineered clothing
- Where does a designer coat's price go, and what does a $20 to $50 replica keep?Bottom-up cost model for a lined coat applied to two reported designer prices: modelled factory cost is under 15% of price, the assumed markup chain does not close the gap, and a $20–50 replica needs very cheap cloth and labour. All inputs assumed. Stylised.
- Can a cheap cloth drape score how well a flat pattern fits a body, and is a fitted pattern body-specific?Position-based cloth drape scores a flat skirt-tube pattern on two synthetic elliptical bodies by strain and waist ease; the best waist is near the body's waist perimeter and a pattern fitted to one body fits the other clearly worse. Stylised; strains depend on mesh and solver.
- How much cloth does marker making waste, and do annealing and exact methods beat greedy nesting?Marker making as strip packing: on 20 random 8-box markers, shelf heuristics leave 17–20% extra length vs the exact optimum, annealing 0.5%; on two stylised garments, polygon nesting beats box packing at equal budget. Stylised; no seam allowance or multi-ply.
- What do seam allowance and mixed sizes do to marker efficiency, and what does that do to a garment's cloth cost?A 1 cm seam allowance cut the stylised shirt's marker efficiency from 0.69 to 0.63 and the skirt's from 0.71 to 0.51; mixing three sizes in one marker shortened it 9%; swapped into the cost model, trench cloth rises from $26 to $33–41 at $7/m². Stylised; sensitivity, not a coat measurement.
- How much cloth does a cutting plan save by mixing sizes in one marker, and is the saving real?Cutting-order planning for a 3-size stylised shirt: laying several garments per marker saves 9–11% of cloth over one per marker; mixing sizes adds 0.4–3.7% in sample, but re-nesting the chosen markers with fresh seeds leaves +0.09%, so it is within nesting noise. Stylised; invented shapes.
- How far is a fixed 0.80 marker efficiency from a nested coat, and what does the difference do to the cost model?Nesting a stylised coat's 10 shell and 5 lining pieces with a 1.5 cm seam allowance gives marker efficiencies of 0.68–0.73 (shell) and 0.59–0.68 (lining) at three cloth widths, below the fixed 0.80 in
garment-teardown; its trench FOB moves +9% to +15% at the teardown's own areas. Stylised, preliminary.
All 45 Engineered clothing projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.