How far is a fixed 0.80 marker efficiency from a nested coat, and what does the difference do to the cost model?
research/garment-nestcost
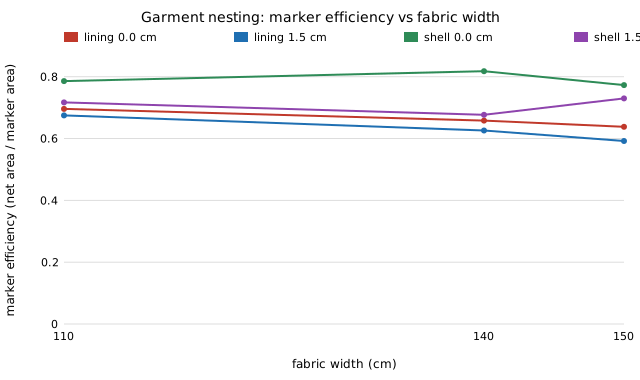
Nesting a stylised coat's 10 shell and 5 lining pieces with a 1.5 cm seam allowance gives marker efficiencies of 0.68–0.73 (shell) and 0.59–0.68 (lining) at three cloth widths, below the fixed 0.80 in garment-teardown; its trench FOB moves +9% to +15% at the teardown's own areas. Stylised, preliminary.
What it found
Follow-up to the nesting and cost-teardown projects (stylised, preliminary). A coat drawn as 10 shell and 5 lining polygons, grown by a 1.5 cm seam allowance and nested by annealing at cloth widths of 110, 140 and 150 cm, gives marker efficiencies of 0.68–0.73 for the shell and 0.59–0.68 for the lining, against the fixed 0.80 assumed earlier (0.77–0.82 without allowance). Transplanted into the teardown trench model, the efficiency alone raises factory cost by about $20–30; the larger uncertainty is the pattern area, which these invented pieces do not settle. One ply, one size, my own shapes, no exact reference.
A figure from its own output
Paper, code and results
More in Engineered clothing
- How many clothing sizes does it take to fit a population, and does a regular S-M-L grid waste them?How many sizes fit a population? On a stylised synthetic bust/hip population (+-4 cm), an exact size run beats a regular grid by 12 to 25 points at correlation 0.9 but not on fresh people at correlation 0; greedy is within 3.7 points of optimal (stylised, preliminary).
- How many clothing sizes does a stretch fabric save?How many sizes does a stretch fabric save? On a stylised synthetic bust/hip population, 10% usable stretch cuts the sizes needed for 80% fit from 6 to more than 8 down to 2 or 3; an idealised upper bound (preliminary).
- How much comfort can an infrared-transparent or gating textile buy, and which fabric properties matter?Fanger/ISO PMV and a two-node model extended with fabric infrared transmittance, emissivity and solar absorptance: indoors, transmittance 0→0.8 is worth ~2.4 °C of comfort at 28 °C; in sun, absorptance dominates. Stylised; assumed fabric properties, no reference for the optical extension.
- How far is the repository's two-node thermal model from an open-source implementation of the Gagge model?Cross-checks
garment-thermal's two-node model againstpythermalcomfortover 108 conditions: core temperature within 0.25 °C, skin temperature mean 0.6 °C (up to 2.1 °C) apart; a comparison of implementations, not of people. - Which design choices explain the gap between the repository's two-node model and an open-source Gagge implementation?Switches nine design choices one at a time between
garment-thermal's two-node model andpythermalcomfort's: variable skin mass fraction, convection coefficient and vasodilation gain explain most of the 0.58 °C skin-temperature gap; a comparison of implementations, not of people. - Do the fabric-optics conclusions of the thermal-comfort model survive a different two-node implementation?Adds
garment-thermal's fabric optics (infrared transmittance, emissivity, solar absorptance) to the switchable two-node model and re-runs the comparisons underpythermalcomfort's choices: property rankings agree in all four scenarios, sizes within 3% at 28 °C but up to ~2× apart in cool air and in sun; a comparison of implementations, not of people.
All 45 Engineered clothing projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.