Does tilting a quadrotor's rotors buy the yaw authority that no attitude controller could?
research/codesign-aero-cant
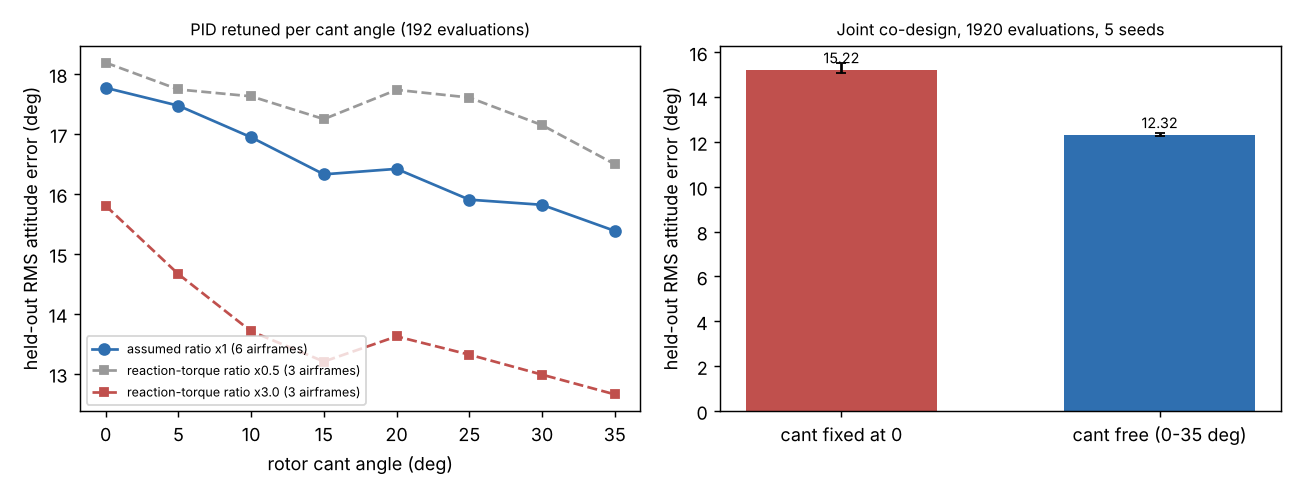
Does a rotor cant angle, co-designed with arm length and propeller size, beat the yaw limit that control-law changes could not move? In simulation yes: joint co-design with free cant (chosen at the 35° bound in 5 of 5 seeds) cuts held-out attitude error from 15.22° to 12.32°, at equal evaluations.
What it found
Follow-up to codesign-aero-coupled, which found yaw (reaction-torque limited) dominates quadrotor attitude error and that no control law changed that. Here the rotor cant angle α is a design variable: tilting rotors about their arms, alternating with spin direction, raises yaw authority to 2ΔT(κ cosα + r sinα) but costs thrust (every rotor is sized for T/cosα: more mass, more cost). With the PID retuned at each angle (6 airframes × 5 seeds, 64 held-out episodes), error falls from 17.77° at α = 0 to 15.38° at 35° (paired: better in 20 of 20 feasible pairs, mean −2.85°); the gain survives a 0.5× and 3× reaction-torque ratio. Joint CMA-ES co-design of arm length, propeller size, cant and gains (1920 evaluations, 5 seeds) reaches 12.32° against 15.22° with cant fixed at 0, and picks 34–35°, the edge of the allowed range, every time, so the optimum is not located. Higher cant also makes some airframes infeasible under the cost cap (20 of 30 grid cells feasible at 30–35°). Limits: the reaction-torque ratio, plant ranges and cost model are assumed and swept, not measured; tilt-induced efficiency loss, internal force fighting and roll/pitch cross-coupling from the tilted thrust vectors are not modelled; attitude only, step references.
A figure from its own output
Paper, code and results
More in Agentic co-design of low-cost robots
- Where is the best rotor cant angle for a quadrotor co-designed with its controller?Does more rotor tilt keep helping once the 35° cap of codesign-aero-cant is lifted? In simulation no: with the bound at 35°, 50°, 65° and 80° the joint co-design reaches 12.3° held-out attitude error and picks 34–40° each time, so the optimum is interior and flat; an assumed tilt efficiency loss changes it by 0.1°.
- Does the best rotor cant angle change when yaw reaction torque scales with propeller size?Does the interior cant optimum survive a reaction torque that grows with propeller diameter (κ = c·D) instead of a fixed 0.016 m? In simulation yes: for c = 0.06, 0.126 and 0.25 the joint co-design reaches 12.5°, 12.3° and 11.8° held-out attitude error with the bound at 80°, picks 33–41° each time, and cant still beats no cant in 5 of 5 seeds; the gain is largest (−4.8°) for the weakest reaction torque.
- Does rotor cant still pay once a co-designed quadrotor must hold position?Once the vehicle must hold position, does a canted-rotor quadrotor still win? In simulation cant still buys yaw (−6° RMS, 5 of 5 seeds) but not position, and the sideways force a tilted rotor makes under roll/pitch torque breaks designs tuned without it (1.1 m against 0.25 m position error).
- What reaction-torque-to-thrust ratio do real small propellers have, and does the best rotor cant angle survive it?What is the reaction-torque-to-thrust ratio of real small propellers, and does the best cant angle survive it? Measured static data for 77 propellers of 3.15–9.85 in give c = CP/(2π·CT) = 0.065–0.13 (median 0.081); in simulation cant still beats no cant in 5 of 5 seeds at every c, by 2.9–4.7°, and the joint design picks 36–41°.
- Is rotor cant just a cheap way to buy yaw authority that bigger motors would buy as well?Does rotor cant still help once motor headroom is a design variable? With thrust-to-weight free in 1.5–4 (no cant picks the 4.0 ceiling), cant to 35° still beats no cant in 5 of 5 seeds at each of three measured propeller c values, by 1.6–3.4°; headroom alone recovers 2.5–3.5° of the 3.8–4.7° the parent credited to cant.
- Was the thrust-to-weight ceiling of 4 what made rotor cant look good?Does raising the TWR ceiling from 4 to 6 and 8 erase the cant advantage? No: cant to 35° still beats no cant in 5 of 5 seeds at three measured propeller c values, by 1.5–3.0° at ceiling 8 (1.6–3.4° at 4); the optimiser stops near TWR 5 without cant.
All 27 Agentic co-design of low-cost robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.