How much of a best-of-40 gripper design's score is selection noise when every design gets its own trained grasp force?
research/codesign-forcefresh
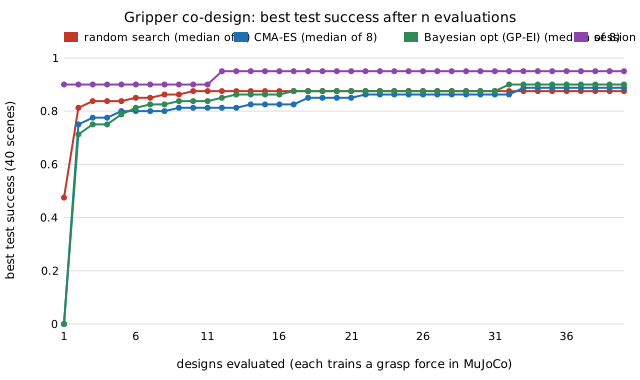
Do agent-proposed gripper fingers beat random search, CMA-ES and Bayesian optimisation when each design gets its own trained grasp force? On 40 held-out scenes all methods' best seeds reach 0.93 to 0.95 and the ranking is within noise; on 100 fresh scenes the session agent's 0.95 falls to 0.81, level with the baseline median (stylised, preliminary, mostly negative).
What it found
Companion to codesign-gripper with a different objective and a searched grasp force. Five parameters of a 3D-printable two-finger gripper (width, thickness, length, V-groove depth, TPU pad) are searched under a print-time cap; for each design a grasp force is tuned in MuJoCo and the design is scored on 40 held-out scenes (cylinders, spheres, boxes of 100–900 g). With 40 designs each, the best seeds of all three baselines reach 0.93–0.95 test success (medians 0.875, 0.887, 0.900 over 8 seeds) and one session-agent trajectory (n = 1, hand-written proposals) reaches 0.95 after 20 designs. On 100 fresh scenes every method’s best design drops 0.06–0.07 on average and the agent’s falls to 0.81, level with the baseline median: the task is nearly saturated and the ranking is within noise (standard error about 0.05). Stylised: assumed costs and strengths, rigid fingers, grid-plus-refine policy search rather than deep RL, nothing printed.
A figure from its own output
Paper, code and results
More in Agentic co-design of low-cost robots
- Does tilting a quadrotor's rotors buy the yaw authority that no attitude controller could?Does a rotor cant angle, co-designed with arm length and propeller size, beat the yaw limit that control-law changes could not move? In simulation yes: joint co-design with free cant (chosen at the 35° bound in 5 of 5 seeds) cuts held-out attitude error from 15.22° to 12.32°, at equal evaluations.
- Where is the best rotor cant angle for a quadrotor co-designed with its controller?Does more rotor tilt keep helping once the 35° cap of codesign-aero-cant is lifted? In simulation no: with the bound at 35°, 50°, 65° and 80° the joint co-design reaches 12.3° held-out attitude error and picks 34–40° each time, so the optimum is interior and flat; an assumed tilt efficiency loss changes it by 0.1°.
- Does the best rotor cant angle change when yaw reaction torque scales with propeller size?Does the interior cant optimum survive a reaction torque that grows with propeller diameter (κ = c·D) instead of a fixed 0.016 m? In simulation yes: for c = 0.06, 0.126 and 0.25 the joint co-design reaches 12.5°, 12.3° and 11.8° held-out attitude error with the bound at 80°, picks 33–41° each time, and cant still beats no cant in 5 of 5 seeds; the gain is largest (−4.8°) for the weakest reaction torque.
- Does rotor cant still pay once a co-designed quadrotor must hold position?Once the vehicle must hold position, does a canted-rotor quadrotor still win? In simulation cant still buys yaw (−6° RMS, 5 of 5 seeds) but not position, and the sideways force a tilted rotor makes under roll/pitch torque breaks designs tuned without it (1.1 m against 0.25 m position error).
- What reaction-torque-to-thrust ratio do real small propellers have, and does the best rotor cant angle survive it?What is the reaction-torque-to-thrust ratio of real small propellers, and does the best cant angle survive it? Measured static data for 77 propellers of 3.15–9.85 in give c = CP/(2π·CT) = 0.065–0.13 (median 0.081); in simulation cant still beats no cant in 5 of 5 seeds at every c, by 2.9–4.7°, and the joint design picks 36–41°.
- Is rotor cant just a cheap way to buy yaw authority that bigger motors would buy as well?Does rotor cant still help once motor headroom is a design variable? With thrust-to-weight free in 1.5–4 (no cant picks the 4.0 ceiling), cant to 35° still beats no cant in 5 of 5 seeds at each of three measured propeller c values, by 1.6–3.4°; headroom alone recovers 2.5–3.5° of the 3.8–4.7° the parent credited to cant.
All 27 Agentic co-design of low-cost robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.