Is rotor cant just a cheap way to buy yaw authority that bigger motors would buy as well?
research/codesign-aero-cant-twr
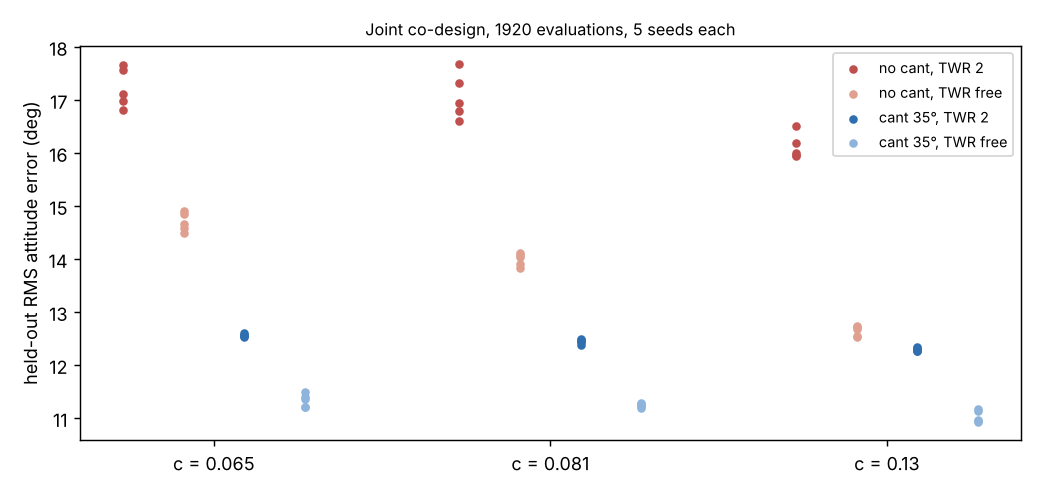
Does rotor cant still help once motor headroom is a design variable? With thrust-to-weight free in 1.5–4 (no cant picks the 4.0 ceiling), cant to 35° still beats no cant in 5 of 5 seeds at each of three measured propeller c values, by 1.6–3.4°; headroom alone recovers 2.5–3.5° of the 3.8–4.7° the parent credited to cant.
What it found
Follow-up to codesign-aero-cant-propdata (next step: compare at equal cost with a motor upgrade). Thrust-to-weight (motor headroom, 1.5–4.0) becomes an optional design variable beside arm length, propeller size, cant and six PID gains; κ = c D with c at the 10th, 50th and 90th percentile of measured UIUC static propeller data (0.065, 0.081, 0.13). Four arms, 1920 CMA-ES evaluations, 5 seeds, 64 held-out episodes, $300 cost cap. Without cant, free headroom cuts the held-out error from 17.2/17.1/16.1° to 14.7/14.0/12.6° (5 of 5 seeds at every c) but the optimiser sits on the 4.0 ceiling, so these are lower bounds on what headroom buys. With headroom free, cant to 35° still improves it to 11.3/11.2/11.0° (better in 5 of 5, by 3.4, 2.8 and 1.6°); the chosen cant falls from 35° to 23–29° and TWR is 3.7–3.8. At the largest c, cant with TWR 2 is only 0.3° better than no cant with free TWR. Limits: the TWR range, the motor mass/cost fits and plant ranges are assumed, TWR ceiling binds for no cant, attitude steps only, no position hold, no hardware.
A figure from its own output
Paper, code and results
More in Agentic co-design of low-cost robots
- Was the thrust-to-weight ceiling of 4 what made rotor cant look good?Does raising the TWR ceiling from 4 to 6 and 8 erase the cant advantage? No: cant to 35° still beats no cant in 5 of 5 seeds at three measured propeller c values, by 1.5–3.0° at ceiling 8 (1.6–3.4° at 4); the optimiser stops near TWR 5 without cant.
- Does a neural residual help a quadrotor attitude controller once roll, pitch and yaw are coupled?Does a residual network or analytic gyroscopic compensation beat per-axis PID on a coupled three-axis quadrotor? No: the residual is worse than PID in 26 of 30 pairs (+0.32° held out) and compensation changes the error by 0.001°; yaw authority sets the error.
- Does a small neural roll controller beat the three-gain PID on a randomised quadrotor, and does it change which airframe is best?Does a 31-parameter neural roll controller beat the three-gain PID on a randomised quadrotor? Not at equal evaluations (7.7° PID against 9.0°); with 10× the evaluations it only matches it (7.6°), and the airframe ranking is unchanged (Spearman 1.00).
- Does a neural residual on top of the tuned PID get a quadrotor roll controller below the PID error floor?Does a zero-initialised neural residual on the tuned PID beat the PID on a randomised quadrotor? No at equal evaluations (7.68° against 7.58°, better in 7 of 18 pairs); the airframe ranking is unchanged (Spearman 1.00).
- Does the strawberry gripper co-design survive the measured range of stem pull-off force?Does the strawberry-gripper co-design of codesign-agri survive measured stem pull-off forces (3.17 N bending and pulling, 13.94 N pulling alone) instead of an assumed 3.5 N? Partly: the optimiser ranking holds in 8 of 10 cells, but the best achievable objective falls from 0.665 to 0.075 as the median pull-off rises from 3.17 to 13.94 N, and at 13.94 N no 40-evaluation run finds a gripper that picks anything
- Do the codesign-agri conclusions survive when its assumed constants change?Does the optimiser ranking of codesign-agri survive a sweep of its 12 invented constants? Mostly: Bayesian optimisation beats CMA-ES beats random search in 82 of 100 worlds, but the best gripper has 2, 3 or 4 fingers depending on stem strength and the nominal winner loses 0.06 J or goes over budget in most worlds
All 27 Agentic co-design of low-cost robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.