How many hours of an 8-hour shift can a battery-powered Unitree G1 actually work, and does it change whether it pays?
research/buildbot-shift
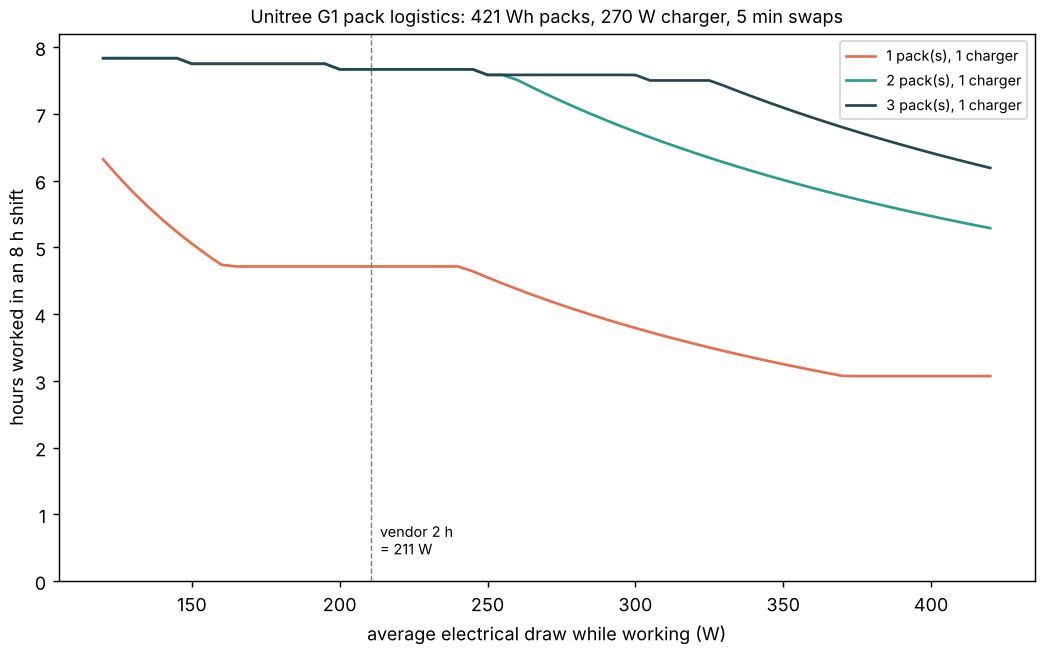
How many hours of an 8-hour shift can a battery-powered Unitree G1 work? One 421 Wh pack gives 4.7 h; two packs and one charger give 7.7 h; above about 300 W the charger is the limit, and pack logistics move the cost break-even only from 2.42 to 2.27 to 2.46 (draw swept, not measured).
What it found
Event model of battery swaps for a Unitree G1: 421.2 Wh packs (9000 mAh at 46.8 V), a 270 W charger and the vendor's “about 2 hours” runtime, which implies about 211 W. One pack gives 4.7 h of work in an 8 h shift; two packs and one charger give 7.7 h, and a third pack adds nothing. Above about 300 W the charger is the bottleneck (3 packs for 7 h at 300 W, 4 at 400 W). Fed into buildbot-cost, pack wear and extra packs move the G1 break-even slowdown only from 2.42 to 2.27–2.46, so battery logistics are a scheduling detail rather than the deciding cost, and put the robot at 1,200–1,900 h/yr. The draw is back-calculated from a vendor claim and swept 150–400 W, not measured; swap time, usable fraction, charger efficiency and pack cycle life are assumed.
A figure from its own output
Paper, code and results
More in Robots on the building site
- Can the building-site robot skills be packaged as loadable files, and does training on two plants at once cover a third?Can the building-site robot skills ship as loadable files? Five JSON skill files reload and re-score exactly; a follow skill tuned on the worse of two plants passes 68%, 65% and 70% on the rigid, flexing and MuJoCo plants, no better than tuning on the flexing plant alone (72%, 69%, 71%).
- Does a sheet-following robot skill trained on a rigid-sheet simulator survive a flexing sheet, sensing delay and actuator lag?Does a sheet-following skill tuned on a rigid-sheet simulator survive a flexing sheet with delay? It passes 81% of episodes where it was tuned and 0-11% on the held-out plant; tuning on the held-out plant gives 61-66% there.
- How many times must a G1 humanoid re-stand to nail one 4x8 sheet of sheathing?How many times must a G1 humanoid re-stand to nail one 4x8 sheet? About 13 stances at 5 platform heights: with its feet planted it holds a 3.4 kg nailer at 50 N only 0.7-1.5 m high and 0.3 m sideways, so one stance covers at best 6 of 62 nails, and the sheet matches hand nailing (372 s) only if each re-stance takes under 26-29 s (push to seat and re-stance time are swept, not sourced; no walking simulated).
- How well must a nailing robot find the studs, and does measuring more beat measuring better?How well must a nailing robot find the studs? A 4x8 sheet needs a single stud reading good to 0.89 mm (1 sigma) for 95% clean sheets; a stud finder's 'within 1/8 in' claim gives 28% (8 of 62 nails missed) or 69%; averaging reads and pooling a straight wall help, re-measuring each nail is worst.
- Which tasks of building a wood-frame house hold the crew hours, and which can a stock humanoid even hold the load for?Which house-building tasks hold the crew hours, and which can a stock humanoid hold the load for? An open task book of a 28x40 ft wood-frame house: 20 tasks with cycles, masses, tolerances and crew-hours, scored against the simulated Unitree G1 and H1 payload envelopes; fastening is 31% of the hours, and the H1 passes the payload test for 53-81% of them (minutes per unit are assumptions, swept).
- Which joint's torque limit sets how fast a stock humanoid can carry a load?Which joint's torque limit caps a stock humanoid's carrying? For the G1 it is the waist pitch: doubling it alone takes the heaviest feasible payload from 4 to 6 kg; the H1 has no single bottleneck.
All 27 Robots on the building site projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.