Can the building-site robot skills be packaged as loadable files, and does training on two plants at once cover a third?
research/buildbot-skillpack
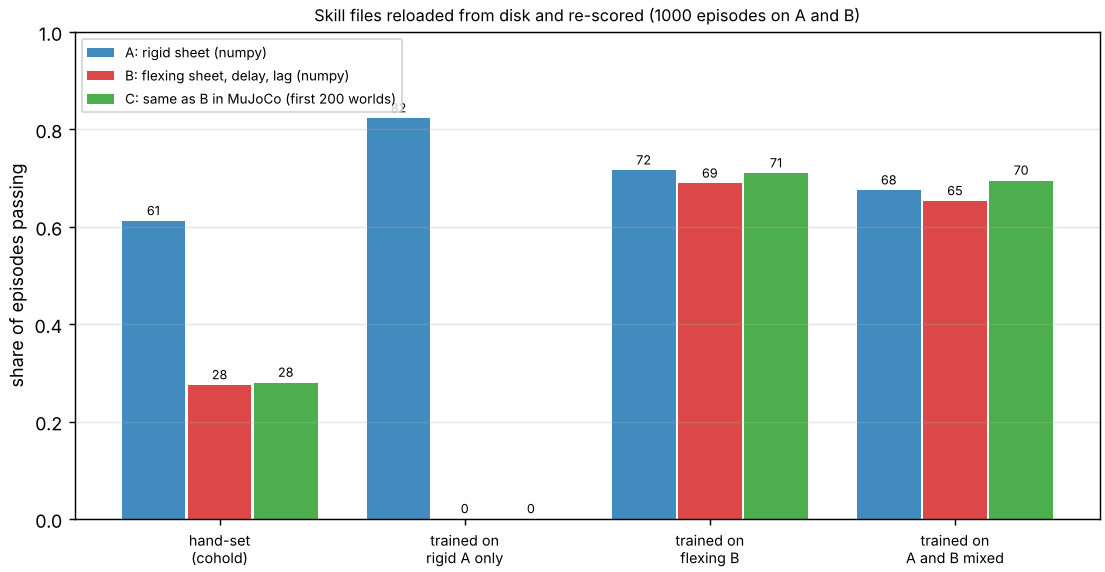
Can the building-site robot skills ship as loadable files? Five JSON skill files reload and re-score exactly; a follow skill tuned on the worse of two plants passes 68%, 65% and 70% on the rigid, flexing and MuJoCo plants, no better than tuning on the flexing plant alone (72%, 69%, 71%).
What it found
Five versioned JSON skill files (four sheet-following impedance gains and a 62-nail sheathing tolerance budget) with a validating loader and a re-scorer that regenerates each file's test episodes from its stored seed; all five reproduce their claimed success exactly. The follow skill trained on a rigid plant only passes 82% there and 0% on a flexing plant and in MuJoCo; the hand-set gains pass 61%, 28% and 28%; the skill trained on the flexing plant passes 72%, 69% and 71% on the rigid, flexing and MuJoCo plants; a skill tuned on the worse of the rigid and flexing plants passes 68%, 65% and 70%, so mixing the two does not beat training on the flexing one. MuJoCo (200 worlds) agrees with the numpy plant within sampling error. Delay, actuator lag and sheet stiffness are swept ranges, not measurements; the B-trained seed was picked on its test set, the mixed one on a validation set; nothing ran on a robot.
A figure from its own output
Paper, code and results
More in Robots on the building site
- Does a sheet-following robot skill trained on a rigid-sheet simulator survive a flexing sheet, sensing delay and actuator lag?Does a sheet-following skill tuned on a rigid-sheet simulator survive a flexing sheet with delay? It passes 81% of episodes where it was tuned and 0-11% on the held-out plant; tuning on the held-out plant gives 61-66% there.
- How many times must a G1 humanoid re-stand to nail one 4x8 sheet of sheathing?How many times must a G1 humanoid re-stand to nail one 4x8 sheet? About 13 stances at 5 platform heights: with its feet planted it holds a 3.4 kg nailer at 50 N only 0.7-1.5 m high and 0.3 m sideways, so one stance covers at best 6 of 62 nails, and the sheet matches hand nailing (372 s) only if each re-stance takes under 26-29 s (push to seat and re-stance time are swept, not sourced; no walking simulated).
- How well must a nailing robot find the studs, and does measuring more beat measuring better?How well must a nailing robot find the studs? A 4x8 sheet needs a single stud reading good to 0.89 mm (1 sigma) for 95% clean sheets; a stud finder's 'within 1/8 in' claim gives 28% (8 of 62 nails missed) or 69%; averaging reads and pooling a straight wall help, re-measuring each nail is worst.
- Which tasks of building a wood-frame house hold the crew hours, and which can a stock humanoid even hold the load for?Which house-building tasks hold the crew hours, and which can a stock humanoid hold the load for? An open task book of a 28x40 ft wood-frame house: 20 tasks with cycles, masses, tolerances and crew-hours, scored against the simulated Unitree G1 and H1 payload envelopes; fastening is 31% of the hours, and the H1 passes the payload test for 53-81% of them (minutes per unit are assumptions, swept).
- Which joint's torque limit sets how fast a stock humanoid can carry a load?Which joint's torque limit caps a stock humanoid's carrying? For the G1 it is the waist pitch: doubling it alone takes the heaviest feasible payload from 4 to 6 kg; the H1 has no single bottleneck.
- Do open permit records predict how long a permit and the build behind it take, better than each city's own averages?Research programme: LightGBM quantile models beat the per-city, per-type empirical-quantile baseline on pinball loss in 13 of 15 city/target/quantile cells (2024 test year, Chicago, San Francisco, Austin); Chicago's tails are the exception
All 27 Robots on the building site projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.