How often, and how long, should a digital twin be re-identified as the plant drifts?
research/twin-recalibration
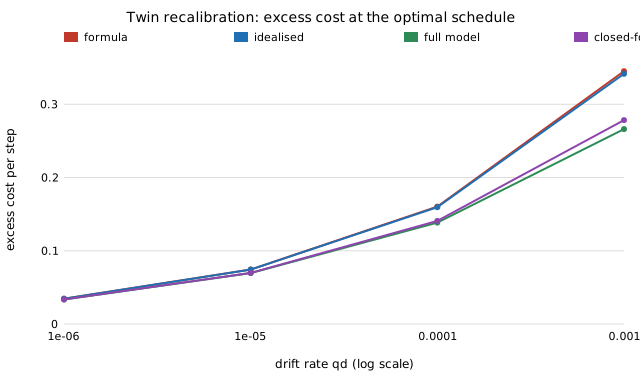
Re-identifying a drifting twin by dedicated experiments: closed-form interval T*∝q_d^{−2/3} with downtime, noise and drift regret exactly equal at the optimum, excess ∝q_d^{1/3}, a 4× drift misjudgement costs ≤26%, but the second-order optimum destabilises 0.7–15% of cycles and a safe schedule is 37–200× worse than an always-on Kalman twin.
What it found
For a twin refitted from dedicated experiments rather than filtered from operating data, the second-order-optimal schedule is closed-form: interval T* = (4cσ2/(vρqd2))1/3, with experiment downtime, estimation noise and drift regret exactly equal at the optimum, so excess cost scales as qd1/3 (fitted slope 0.333) and 10× cheaper experiments lower it only 2.2×. Misjudging the drift rate by 4× costs at most 26%. But the second-order optimum is unsafe: 0.7–15% of its cycles destabilise the loop, and a schedule with failure probability ≤ 10−3 costs 1.2–16× more and is 37–200× worse than an always-on Kalman twin. Stylised.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- What should you pay a digital-twin provider for?What to pay a digital-twin provider for: cost-paid twins differ from Brier-paid ones, certainty-equivalence loss is quartic in spread, payment caps make the elicited twin jump at a closed-form threshold, and Brier mispays probing by 15×.
- How long can a digital twin be wrong before you can prove it, and what does waiting cost?Anytime-valid e-process audit of a digital twin in closed loop: peeking-safe (2.4% vs 58% false alarms), delay set by the controller's own excitation, regret before detection nearly independent of the gap, dither pays only for gross errors.
- What does a Gaussian-clutter radar simulator do to a CFAR detector's false-alarm rate?What a Gaussian-clutter radar twin does to a CA-CFAR detector: exact false-alarm law under gamma texture (matched to simulation), 9–30× inflation at design 1e-4, 1.9–3.7 dB threshold repair, shared texture is harmless, and a real-cell calibration budget (median 1.1× at 1000 cells).
- Does a more robust CFAR detector survive a Gaussian-clutter radar simulator?Does a more robust CFAR survive a Gaussian-clutter twin? CA, OS and log-t all inflate 8–44× at design 1e-4 (no detector escapes), a known-scale oracle inflates as much as CA (the test cell's own texture), and CA detects best at equal real Pfa after repair.
- What does a light-tailed simulated human do to a collaborative robot's timeout?When a collaborative robot should give up waiting for a human:
J'(τ)=S(τ)(w−c·h(τ))makes exponential/Weibull simulated humans corner-only (never abort), 3.7% regret in the base case rising to 37–81% for heavy tails and cheap aborts, plug-in lognormal fit regret1/n(delta method within 11%). - What does a too-clean sensor twin do to a mapper's commit error?What a too-clean sensor twin does to a mapper's commit error: exact real error via the Lundberg exponent (false-hit 0.05 twin vs 0.15 real turns 1e-3 into 1.45e-2, 14.5×), tempering restores the target at 1.4–16× latency, and the exponent needs several hundred real samples to estimate.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.