What should you pay a digital-twin provider for?
research/twin-elicitation
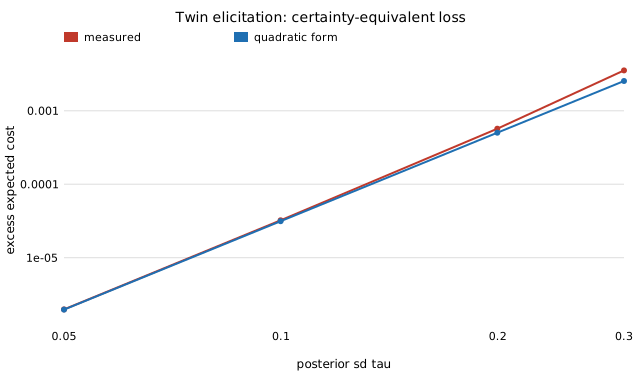
What to pay a digital-twin provider for: cost-paid twins differ from Brier-paid ones, certainty-equivalence loss is quartic in spread, payment caps make the elicited twin jump at a closed-form threshold, and Brier mispays probing by 15×.
What it found
A provider paid Brier score on the twin’s parameter reports its posterior mean; one paid the deployed control cost reports the Bayes gain, which is more conservative (0.778 vs 0.823 at posterior sd 0.3, mean 1) and equals domain randomization under the provider’s own uncertainty. Certainty equivalence costs a quartic in spread (16× per doubling); reports with equal squared error have regret ratios of 1.3–24×; a payment cap makes the elicited gain jump at a closed-form threshold M* (19.3 in the example) that decides whether rare catastrophic plants are priced in; and Brier under- or over-pays probing by a 15× spread in decision value per unit variance. Stylised.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- How long can a digital twin be wrong before you can prove it, and what does waiting cost?Anytime-valid e-process audit of a digital twin in closed loop: peeking-safe (2.4% vs 58% false alarms), delay set by the controller's own excitation, regret before detection nearly independent of the gap, dither pays only for gross errors.
- What does a Gaussian-clutter radar simulator do to a CFAR detector's false-alarm rate?What a Gaussian-clutter radar twin does to a CA-CFAR detector: exact false-alarm law under gamma texture (matched to simulation), 9–30× inflation at design 1e-4, 1.9–3.7 dB threshold repair, shared texture is harmless, and a real-cell calibration budget (median 1.1× at 1000 cells).
- Does a more robust CFAR detector survive a Gaussian-clutter radar simulator?Does a more robust CFAR survive a Gaussian-clutter twin? CA, OS and log-t all inflate 8–44× at design 1e-4 (no detector escapes), a known-scale oracle inflates as much as CA (the test cell's own texture), and CA detects best at equal real Pfa after repair.
- What does a light-tailed simulated human do to a collaborative robot's timeout?When a collaborative robot should give up waiting for a human:
J'(τ)=S(τ)(w−c·h(τ))makes exponential/Weibull simulated humans corner-only (never abort), 3.7% regret in the base case rising to 37–81% for heavy tails and cheap aborts, plug-in lognormal fit regret1/n(delta method within 11%). - What does a too-clean sensor twin do to a mapper's commit error?What a too-clean sensor twin does to a mapper's commit error: exact real error via the Lundberg exponent (false-hit 0.05 twin vs 0.15 real turns 1e-3 into 1.45e-2, 14.5×), tempering restores the target at 1.4–16× latency, and the exponent needs several hundred real samples to estimate.
- Does cloning an expert from logs recorded in a digital twin recover the expert?Cloning an expert from twin-logged demonstrations under actuator saturation: applied-action logs bias the clone even in a perfect twin (gain 0.58 vs 0.96, +9.8% cost), Stein closed form, quieter or looser twins help, narrow coverage fixes it, DAgger with applied labels is worse.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.