Can penalty continuation free SIMP topology-optimisation starts that stay stuck in a different local optimum?
research/simdesign-stuck
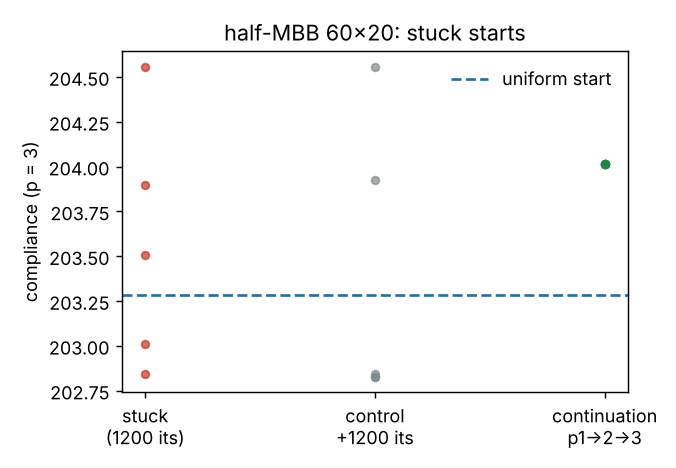
Can penalty continuation free SIMP starts stuck in a different local optimum? No: it sends all 5 stuck starts of 20 to one design (c 204.01) worse than the 202.83 three reach by running longer at p = 3. Stylised.
What it found
Follow-up to simdesign-startsconverge. Half-MBB 60×20, p = 3: after 1200 iterations 5 of 20 random starts still differ from the uniform-start design in at least 1% of elements. Penalty continuation (p = 1, 2, 3) frees none of them: all five collapse onto one design, 20.4% different from the uniform-start one, with compliance 204.01 versus 203.29 for the uniform start. Simply running 1200 more iterations at p = 3 takes three of them to 202.83, about 0.6% better than continuation. Stylised: 2D, dimensionless compliance, one mesh, 20 seeds.
A figure from its own output
Paper, code and results
More in Simulation-first design
- Is the start-dependence of fixed-penalty SIMP topology optimisation just slow convergence?Is the start-dependence of fixed-penalty SIMP just slow convergence? Over 1200 iterations the median of 20 random starts reaches the uniform-start design (0.0% of elements differ, from 3.9% at 150), but the compliance spread only falls 1.43% → 0.85% (stylised, 2D, one mesh).
- How much does a SIMP topology optimisation depend on its starting density field, and does penalty continuation remove it?How much does a SIMP topology optimisation depend on its starting density field? With a fixed penalty, final compliance spreads 1.4–2.8% over 30 random starts and 2–23% of elements change state; with penalty continuation the spread is 0–0.4% (stylised, 2D, 150 iterations).
- How short can SIMP penalty continuation be and still remove the dependence on the starting density field?How short can SIMP penalty continuation be and still remove the start dependence? A ramp of 25 iterations or fewer leaves much of it (worst start differs in 16–23% of elements, 27–31% for a fixed penalty); 50 iterations cuts compliance spread to 0.01–0.23%, and a 112-iteration ramp is most repeatable but ends at a worse compliance (stylised, 2D, 150 iterations).
- When does a cheaper beam model pick the same design as 3D finite elements?Cantilever sizing with Euler–Bernoulli, Timoshenko, 2D and 3D finite elements: stress agrees everywhere, deflection differs; cheap models land within ~5% of the 3D depth, unsafe when narrow and stubby (Euler–Bernoulli) and oversized when wide (plane stress). Stylised, assumed material.
- How do design proposals from a language-model agent compare with CMA-ES, Bayesian optimisation and random search at an equal simulation budget?Session-agent design proposals vs CMA-ES, Bayesian optimisation and random search on a bracket sized by finite elements, 40 evaluations each: agent 23.0 g vs 32–39 g baseline medians (best known 22.4 g); the agent had prior knowledge, n = 1, not an LLM benchmark. Stylised.
- What do manufacturing rules cost a sized bracket on FDM, CNC routing, laser cutting and casting?Manufacturability rules (FDM, CNC routing, laser cutting, sand casting) added to the sized L-bracket: the mass price of each rule set against the same material with no rules (casting +43% from its even-section rule, CNC +24% from plate stock, laser and FDM ~0); designs overshoot the stress limit by 17–26% on a fine mesh (stylised, assumed rule values).
All 64 Simulation-first design projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.