How much does a SIMP topology optimisation depend on its starting density field, and does penalty continuation remove it?
research/simdesign-starts
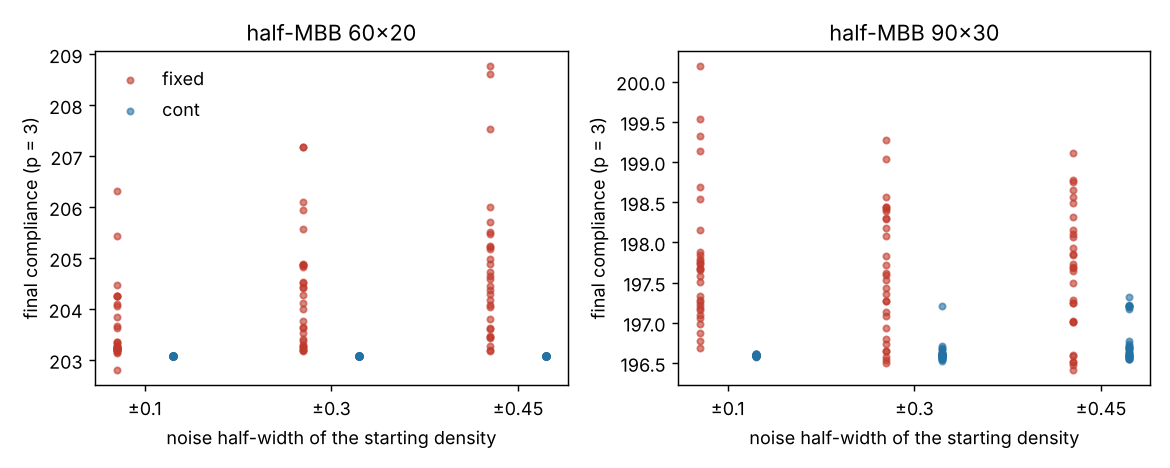
How much does a SIMP topology optimisation depend on its starting density field? With a fixed penalty, final compliance spreads 1.4–2.8% over 30 random starts and 2–23% of elements change state; with penalty continuation the spread is 0–0.4% (stylised, 2D, 150 iterations).
What it found
Half-MBB, volume 0.5, p = 3, 150 sensitivity-filtered OC iterations, 30 random starting fields at each of three noise levels on two meshes, with and without penalty continuation (1 → 3). With a fixed penalty the final compliance spreads by 1.4–2.8% (max/min − 1) and the 0/1 design differs from the uniform-start design in a median 2–23% of elements, with 2–10 enclosed holes. With continuation the spread is 0.0% on 60×20 (identical topology from every start) and at most 0.4% on 90×30. On 90×30 the uniform start, which the 99-line code uses, is worse than 25–28 of 30 random starts at fixed penalty. Stylised: 2D, dimensionless, 150 iterations (not run to convergence), one problem, two meshes.
A figure from its own output
Paper, code and results
More in Simulation-first design
- How short can SIMP penalty continuation be and still remove the dependence on the starting density field?How short can SIMP penalty continuation be and still remove the start dependence? A ramp of 25 iterations or fewer leaves much of it (worst start differs in 16–23% of elements, 27–31% for a fixed penalty); 50 iterations cuts compliance spread to 0.01–0.23%, and a 112-iteration ramp is most repeatable but ends at a worse compliance (stylised, 2D, 150 iterations).
- When does a cheaper beam model pick the same design as 3D finite elements?Cantilever sizing with Euler–Bernoulli, Timoshenko, 2D and 3D finite elements: stress agrees everywhere, deflection differs; cheap models land within ~5% of the 3D depth, unsafe when narrow and stubby (Euler–Bernoulli) and oversized when wide (plane stress). Stylised, assumed material.
- How do design proposals from a language-model agent compare with CMA-ES, Bayesian optimisation and random search at an equal simulation budget?Session-agent design proposals vs CMA-ES, Bayesian optimisation and random search on a bracket sized by finite elements, 40 evaluations each: agent 23.0 g vs 32–39 g baseline medians (best known 22.4 g); the agent had prior knowledge, n = 1, not an LLM benchmark. Stylised.
- What do manufacturing rules cost a sized bracket on FDM, CNC routing, laser cutting and casting?Manufacturability rules (FDM, CNC routing, laser cutting, sand casting) added to the sized L-bracket: the mass price of each rule set against the same material with no rules (casting +43% from its even-section rule, CNC +24% from plate stock, laser and FDM ~0); designs overshoot the stress limit by 17–26% on a fine mesh (stylised, assumed rule values).
- How much does a bolt hole cost a tension plate, and which rule sets its width?Tension plate with a required bolt hole sized under net-section, Kt = 3 and finite-element stress models and per-process hole rules (stylised).
- Does weighting parts by mass change which shop process, and which machine, matters?Does weighting parts by mass change which shop process, and which machine, matters? With a tip load FDM covers 0.30 of parts by count and 0.58 by mass, the laser-versus-CNC order flips, and at budgets 600–800 exhaustive search picks the laser cutter by count but the casting setup by mass (one seed). Stylised, assumed rules and prices, simulated only.
All 64 Simulation-first design projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.