Do the reversed-load buckling-limited L-bracket designs also pass the forward-load buckling, stress and deflection checks?
research/simdesign-fwdcheck
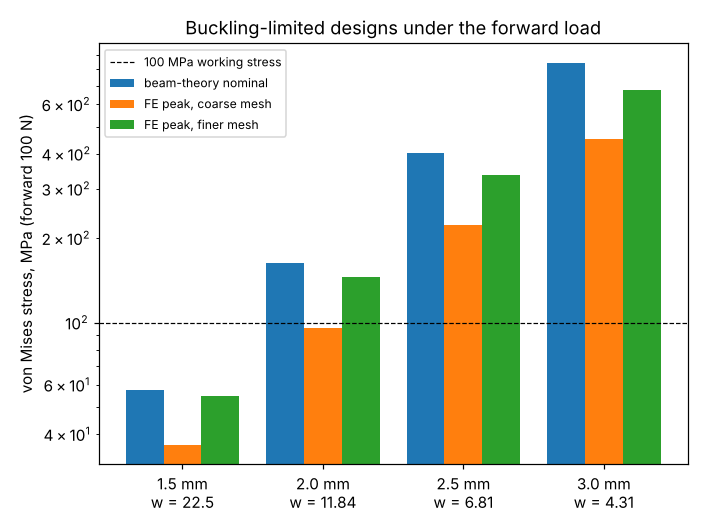
Under the forward 100 N load the four reversed-load buckling-limited L-brackets all clear buckling (factor 4.7 to 5.6), but only the 1.5 mm design also meets the 100 MPa and 4 mm limits; the 2.5 and 3.0 mm designs fail by 2 to 8 times, and the 2.0 mm design passes only on the coarse mesh (95.7 vs 144.9 MPa finer). Stylised.
What it found
A small finite-element check (stylised, preliminary; ideal elastic steel, sharp inner corner, assumed limits). Under the forward 100 N load the four lightest designs that clear the reversed-load buckling floor (1.5 to 3.0 mm sheet) all have forward buckling factors of 4.7 to 5.6, so buckling does not bind. But only the 1.5 mm, 22.5 mm design meets the 100 MPa stress and 4 mm deflection limits; the 2.5 and 3.0 mm designs exceed them by 2 to 8 times, and the 2.0 mm design passes only on the coarse mesh (95.7 MPa against 144.9 MPa on a finer one). The thicker sheet's mass saving is therefore not feasible under these limits.
A figure from its own output
Paper, code and results
More in Simulation-first design
- Is a thicker sheet lighter than a wider 1.5 mm web for clearing the reversed-load buckling floor?At the reversed-load buckling floor of 3, a 2 mm sheet needs a web of about 11.8 mm and weighs 27.5 g against 36.6 g for 1.5 mm at 22.6 mm; 2.5 mm gives 20.5 g; buckling only, one element layer through the thickness, preliminary.
- Does relaxing the 1.2 mm minimum-wall rule open thinner sheet gauges for the laser-cut bracket, or is the buckling floor what binds?Relaxing the 1.2 mm minimum wall of the laser-cut bracket: it does not open 1.0 mm sheet by itself (the buckling floor binds); with floor 1 and wall ≤ 1.0 mm a 24.8 g design appears (unvalidated closed form).
- Does the lightest 1.5 mm bracket design clear buckling in a converged 3D eigenbuckling model?A through-thickness-converged 3D eigenbuckling model agrees with the closed-form buckling factor of the lightest 1.5 mm bracket design to under 1% (3.49 vs 3.47, so it clears the floor of 3); the horizontal-arm formula is about 18% conservative; one design, ideal bar, preliminary.
- What changes when the w/b ≤ 8 slenderness ceiling of the laser-cut bracket is replaced by a buckling-factor floor?Replacing the w/b ≤ 8 ceiling with a closed-form buckling-factor floor makes the 1.5 mm laser-cut gauge feasible (31.0 g, about 13% lighter than the best 2 mm design) and changes nothing at 2 and 3 mm; at 1 mm the minimum-wall rule, not buckling, blocks every design; stylised, unvalidated factor, preliminary.
- Does lateral-torsional buckling justify the w/b ≤ 8 slenderness rule of the 2 mm laser-cut bracket?A closed-form lateral-torsional buckling check of the laser-cut bracket arms (stylised, unvalidated by FE): at 2 mm gauge the governing safety factor is 6.9–9.0 for w = 16–20 mm, so the widths of
simdesign-widerwebare not buckling-limited, and the factor rises with w, opposite to the w/b ≤ 8 rule; at 1 mm the old rule admits designs below 1. - Do the closed-form buckling factors of the laser-cut bracket arms agree with a 3D eigenbuckling model?A 3D scikit-fem eigenbuckling check of the bracket-arm closed forms (stylised, mesh not converged): within about 1% for the governing vertical arm, conservative by 6–29% for the horizontal arm at the 2 mm gauge.
All 64 Simulation-first design projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.