Does the lightest 1.5 mm bracket design clear buckling in a converged 3D eigenbuckling model?
research/simdesign-buckle15
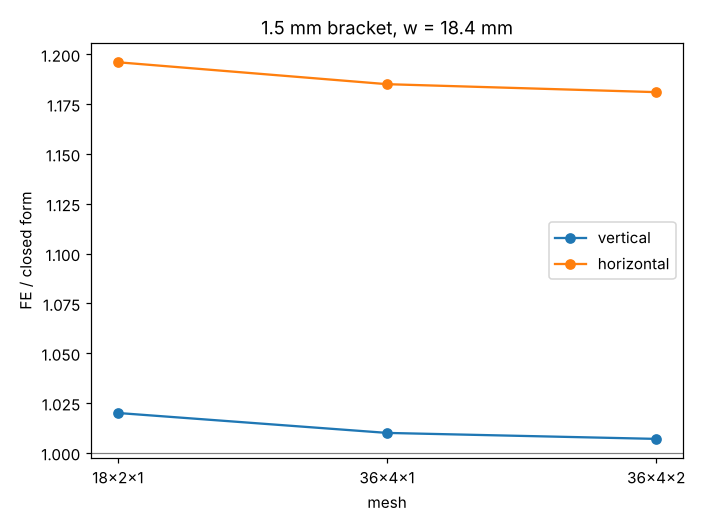
A through-thickness-converged 3D eigenbuckling model agrees with the closed-form buckling factor of the lightest 1.5 mm bracket design to under 1% (3.49 vs 3.47, so it clears the floor of 3); the horizontal-arm formula is about 18% conservative; one design, ideal bar, preliminary.
What it found
A small finite-element check (stylised, preliminary; ideal elastic clamped arms, one design). Meshing the 1.5 mm, w = 18.4 mm design from simdesign-bucklebound with hexahedra at three resolutions, including two layers through the thickness, the governing vertical-arm buckling factor is 3.49 against 3.47 from the closed form (ratio 1.020 → 1.007 on refinement), so the design clears the floor of 3. The horizontal-arm formula is about 18% conservative. Nothing was made or tested.
A figure from its own output
Paper, code and results
More in Simulation-first design
- What changes when the w/b ≤ 8 slenderness ceiling of the laser-cut bracket is replaced by a buckling-factor floor?Replacing the w/b ≤ 8 ceiling with a closed-form buckling-factor floor makes the 1.5 mm laser-cut gauge feasible (31.0 g, about 13% lighter than the best 2 mm design) and changes nothing at 2 and 3 mm; at 1 mm the minimum-wall rule, not buckling, blocks every design; stylised, unvalidated factor, preliminary.
- Does lateral-torsional buckling justify the w/b ≤ 8 slenderness rule of the 2 mm laser-cut bracket?A closed-form lateral-torsional buckling check of the laser-cut bracket arms (stylised, unvalidated by FE): at 2 mm gauge the governing safety factor is 6.9–9.0 for w = 16–20 mm, so the widths of
simdesign-widerwebare not buckling-limited, and the factor rises with w, opposite to the w/b ≤ 8 rule; at 1 mm the old rule admits designs below 1. - Do the closed-form buckling factors of the laser-cut bracket arms agree with a 3D eigenbuckling model?A 3D scikit-fem eigenbuckling check of the bracket-arm closed forms (stylised, mesh not converged): within about 1% for the governing vertical arm, conservative by 6–29% for the horizontal arm at the 2 mm gauge.
- Does refining the mesh of the 3D eigenbuckling check change how the closed-form bracket-arm buckling factors compare?Mesh refinement of the 3D eigenbuckling check of the bracket arms (stylised): refining length, width and thickness lowers every FE/closed-form ratio by 0.9–1.3 points, so the governing vertical arm agrees with the closed form to within 1% (ratio 0.99–1.00 at the finest mesh).
- At what bar slenderness does the 3D eigenbuckling model agree with the slender-beam closed form?How the 3D eigenbuckling model compares with the slender-beam closed form as a bar gets longer (stylised): the finite-element load is 14.5%, 7.4%, 3.8% and 2.1% above it at l/w = 3, 6, 12, 24.
- How much stiffer than a uniformly thinned plate is a topology-optimised part, and how does that depend on volume fraction?How much stiffer a thresholded topology-optimised part is than a uniformly thinned plate across volume fractions (stylised): 26–31% lower compliance at v = 0.3–0.5, shrinking to 14% at 0.8, and disconnected designs below that on coarse grids.
All 64 Simulation-first design projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.