Do the mass-weighting machine-choice flips of simdesign-coverweight survive across seeds?
research/simdesign-flipseeds
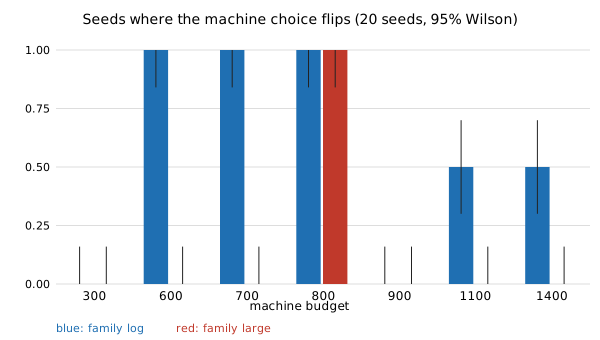
Do the mass-weighting machine-choice flips of simdesign-coverweight survive across seeds? Over 20 seeds, log flips from the laser cutter (count) to the casting setup (mass) in 20/20 at budgets 600–800, large only at 800, small never; the 1100–1400 flips are near-ties (≤0.26 points). Stylised, assumed rules and prices, simulated only.
What it found
Follow-up to simdesign-coverweight, whose machine-choice flips between count and mass weighting came from one seed. Over 20 fresh seeds of 20 000 sampled brackets and three assumed machines, family log picks the laser cutter by count but the casting setup (or, in 2 seeds at 800, the CNC router) by mass in 20 of 20 seeds at budgets 600 to 800 (95% Wilson interval 0.84 to 1.00; about 2.1 points of mass-weighted coverage given up), family large flips only at budget 800 (20 of 20), and small never flips. The log flips at 1100 and 1400 split 10 of 20 but lose at most 0.26 points, a near-tie. The intervals cover sampling noise only; rules, prices and the volume mass proxy are assumptions. Stylised; simulated only.
A figure from its own output
Paper, code and results
More in Simulation-first design
- How wide are the budget bands where mass weighting changes the machine choice when prices are uncertain?How wide are the budget bands where mass weighting changes the machine choice when prices are uncertain? With ±20% independent price noise the
logflip band widens from budgets 600–800 to 500–1000 but softens at its edges (about one half), andlarge's single nominal flip at 800 shows up in only 44% of price draws. Stylised, assumed rules and prices, simulated only. - Which share of a bracket family can each shop process make, and which machine should a shop add next?Share of a sampled bracket family each shop process can make under the
simdesign-dfmrules: geometry alone adds nothing beyond FDM (negative), with a tip-load requirement the processes separate (FDM alone 30%, +casting +laser 41%) and the best next machine depends on budget and part size, where greedy sometimes loses 1–2 points to exhaustive search (stylised, assumed rules). - Does a mesh-aware stress margin change what manufacturing rules cost a sized bracket?Re-runs
simdesign-dfmwith a stress knock-down and a finer search mesh, checking designs at h = 0.7 mm: the price ordering (casting ~1.4, CNC ~1.23, FDM 1.0) survives the mesh, the laser-cutting price does not (1.01–1.22, noisy), and a 1.3 margin leaves designs at 0.88–1.02 of the limit (stylised, assumed rule values). - Does a patch-averaged stress converge under mesh refinement where the peak element stress does not?Compares peak and patch-averaged von Mises stress under mesh refinement on the L-bracket: the peak rises 18–41% from h = 2.5 to 0.55 mm while a 3 mm patch average moves 1–6%, but it reads only 0.45–0.69 of the peak so needs its own limit (stylised, assumed values).
- Does a patch-averaged stress change what manufacturing rules cost a sized bracket?Repeats the process-rule bracket search with a 3 mm patch-averaged stress instead of the peak: the ordering of mass prices (casting > CNC > laser ≈ FDM) holds, the laser price spread across seeds shrinks from 0.16 to under 0.005, and designs overshoot their limit by 2–12% on a fine mesh against 19–34% for the peak (stylised, assumed values, uncalibrated limit).
- Is the shrinking laser-cutting price scatter under the patch stress caused by the near-sharp fillet floor?Tests whether a near-sharp fillet floor explains the laser-cutting price scatter seen in
simdesign-patchsearch: it does not (peak-stress designs already use 7.6–14.3 mm fillets, so floors of 0.2 and 1 mm give identical designs); the patch-stress price is steady (sd 0.006–0.011) at every floor, and the cause of the peak scatter is not identified (negative, five seeds, stylised).
All 64 Simulation-first design projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.