Is the shrinking laser-cutting price scatter under the patch stress caused by the near-sharp fillet floor?
research/simdesign-filletfloor
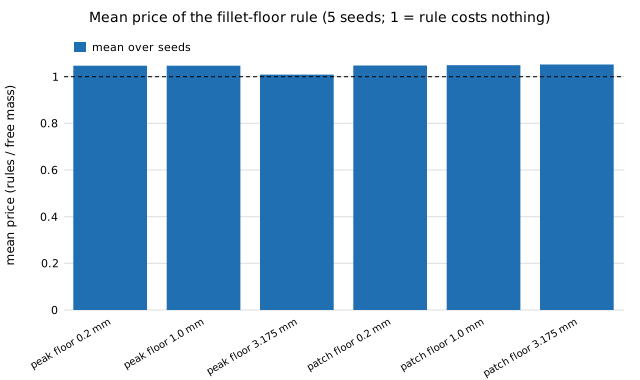
Tests whether a near-sharp fillet floor explains the laser-cutting price scatter seen in simdesign-patchsearch: it does not (peak-stress designs already use 7.6–14.3 mm fillets, so floors of 0.2 and 1 mm give identical designs); the patch-stress price is steady (sd 0.006–0.011) at every floor, and the cause of the peak scatter is not identified (negative, five seeds, stylised).
What it found
A negative result (stylised). Raising the laser-cutting inner-fillet floor from 0.2 to 1 and 3.175 mm over five seeds does not explain the scatter in the mass price of the rules: the peak-stress designs already use fillets of 7.6–14.3 mm, so the 0.2 and 1 mm floors give identical designs (sd of the price 0.063), and under a 3 mm patch average the price is steady (sd 0.006–0.011) at every floor. The cause of the peak-stress scatter is not identified. Limits: five seeds, one process and load, uncalibrated limit, assumed values, 2D plane stress.
A figure from its own output
Paper, code and results
More in Simulation-first design
- Where does the peak-stress price scatter of laser-cutting rules come from?Follow-up to
simdesign-filletfloor: the peak-stress price scatter of laser-cutting rules (sd 0.063) sits in the 2 mm gauge sub-search, not the fillet floor; a four-times search budget cuts it to 0.025 but not monotonically, so several nearby optima are plausible but not shown (five seeds, stylised). - Does a patch-averaged stress give a mesh-converged stress concentration for a bolt hole?Patch-averaged stress for a bolt hole in a tension strip: nearly settled under mesh refinement already, matches Kirsch's disc averages, needs its own limit (stylised).
- How far below the exact stress concentration does a finite-element peak stress sit, and how fast does it close?Checks the finite-element peak stress at a circular hole against Kirsch's exact 3× concentration: the element-centroid peak sits 27% (coarse) to 1.1% (fine) below it and closes only at first order, while hole-edge vertex values are within 1% (stylised).
- What causes the peak-stress price scatter of laser-cutting rules in the bracket search?The peak-stress price scatter of laser-cutting rules is a missed search at the narrow 2 mm gauge (1 seed in 20), not a cost of the rules; stylised, mesh effects untested.
- Do search restarts remove the missed 2 mm sub-search in the laser-cut bracket problem?A second DE restart or a doubled population removes the missed 2 mm sub-search (0 misses in 40 runs against 1 in 20 at baseline) and shifts results to the lighter of two mass groups at about twice the cost; stylised, 2.5 mm search mesh only.
- Are the two mass groups of the 2 mm laser-cut bracket search two separate basins?The two gauge-2 mass groups differ in web width w (about 14.3–14.9 against 15.2–15.6 mm), not fillet radius, and the lighter group matches ragged isolated feasible pockets on the 2.5 mm mesh rather than a second broad basin; stylised, preliminary.
All 64 Simulation-first design projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.