Does an epipolar gate help bundle adjustment under the mismatch mix a real SIFT matcher produces?
research/sensing-mixgate
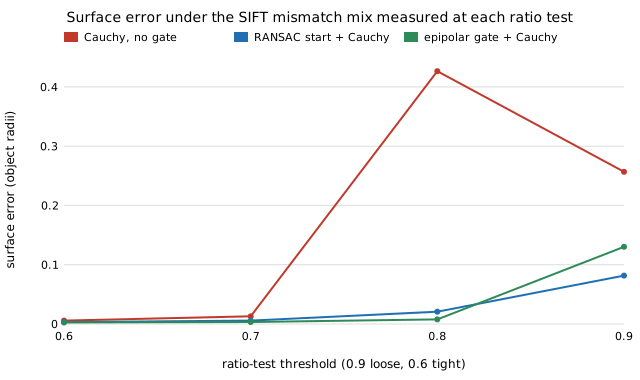
Feeding sensing-matchreal's measured SIFT mismatch mixes into the sensing-epigate trial, gate plus Cauchy beats a RANSAC start at ratio tests of 0.8 and tighter (0.0078 against 0.0207 object radii at 0.8) and loses only at a loose 0.9 ratio test, where all methods exceed 0.08; synthetic geometry, 6 seeds
What it found
sensing-epigate found a fundamental-matrix gate no better than a RANSAC start against invented mismatches; sensing-matchreal then measured real SIFT mismatches on a Middlebury stereo pair. This project runs the epigate trial with each measured mix (rate and along/near/far shares at ratio tests none, 0.9, 0.8, 0.7, 0.6). Gate plus Cauchy adjustment gives 0.0078, 0.0033 and 0.0026 object radii at ratio 0.8, 0.7 and 0.6, against 0.0207, 0.0058 and 0.0032 for a RANSAC start and 0.43, 0.013 and 0.0057 for plain Cauchy (floor 0.0015). At ratio 0.9 (23% wrong) the RANSAC start is better (0.082 against 0.130) and with no ratio test (56% wrong) nothing works. An all-uniform control at the same rates is dominated by single failed seeds and is reported as unestablished. Limits: one scene and detector for the mix, synthetic orbit geometry, independent draws, 6 seeds, no intervals, untuned gate.
A figure from its own output
Paper, code and results
More in Sensing, imaging and 3D
- Is an INS/GNSS Kalman filter honest about its drift when accelerometer bias is flicker noise?With a 1/f accelerometer bias, a filter with no bias state claims 2.9 m after a 300 s GNSS outage when the RMS is 151 m (NEES/dof 514 to 2,000 at 100 ug); a random walk read off the Allan curve at 1 s or 10 s claims 2.4 to 3.7 times the true error, and at 100 s close to honest (0.9 to 1.6). Synthetic bias, swept instability
- Does marginalising old keyframes instead of pinning them fix long-path drift in a visual-inertial smoother, and does IMU grade then matter?A Schur-complement prior in the sensing-vio planar smoother cuts rms drift on 30 s paths from 12.3 % to 2.5 % of path (8 seeds, baseline IMU), and IMU grade then orders the results (0.25x noise 2.1 %, 1x 2.5 %, 4x 6.5 %), unlike with the pinned prior; planar and synthetic, not EuRoC
- How many cheap gyros, fused, match one better gyro at the same cost?How many cheap gyros, fused, match one better gyro at equal cost? With independent errors the price ratio must beat
k²(100 for a 10× quieter unit); shared error above1/k²means no array size ties; unequal white/bias improvement makes the answer depend on integration time. Stylised. - Does a shared temperature coefficient put a floor under an array of cheap gyros?Does a shared temperature coefficient put a floor under an array of cheap gyros? The shared part of the tempco does not average out: in the illustrative case a 3× better gyro can no longer be matched at any array size above a 0.2 °C/min ramp over 100 s; compensation quality, not array size, decides.
- How many frames from a small sensor, merged, match one frame from a bigger one?How many frames from a small sensor, merged, match one frame from a sensor with A× the pixel area? A shot-noise-limited burst needs A frames, a read-noise-limited one up to A² (formula and simulation agree); splitting the same total exposure never ties; registration blur and bracketed HDR are measured. Synthetic scenes only.
- What does a moving subject do to a burst merge, and what does robust merging cost?What does a moving subject do to a burst merge? A plain mean ghosts at every speed and gets worse as frames are added (30.5 dB at 8 frames, 25.0 at 48), median and sigma-clip do no better for a slow subject, and a reference-guided merge keeps improving and ties a 4×-area frame at about 6 frames at 0.1 dB cost when nothing moves. Synthetic scenes only.
All 31 Sensing, imaging and 3D projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.