What does a moving subject do to a burst merge, and what does robust merging cost?
research/sensing-ghost
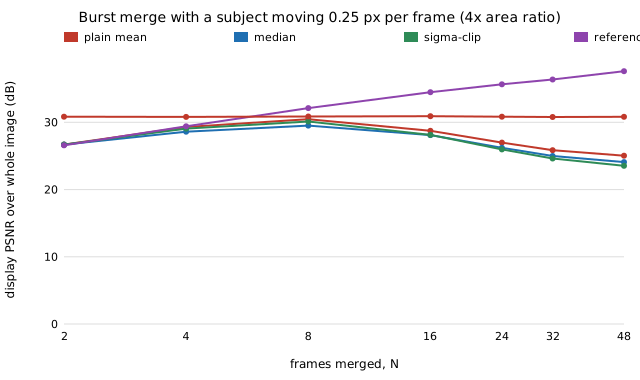
What does a moving subject do to a burst merge? A plain mean ghosts at every speed and gets worse as frames are added (30.5 dB at 8 frames, 25.0 at 48), median and sigma-clip do no better for a slow subject, and a reference-guided merge keeps improving and ties a 4×-area frame at about 6 frames at 0.1 dB cost when nothing moves. Synthetic scenes only.
What it found
Still camera, one disc moving across a synthetic burst (Poisson shot noise, Gaussian read noise, a large sensor with 4× the pixel area). A plain mean merge ghosts at every speed tested and gets worse as frames are added (30.5 dB at 8 frames, 25.0 dB at 48 for 0.25 px per frame, against 30.8 dB for one large-sensor frame); median and sigma-clip merges do no better because a slow subject covers each pixel in most frames. A reference-guided merge (add a frame only where it agrees with frame 0) keeps improving, to 37.6 dB at 48 frames, and ties the large frame at about 6 frames; with nothing moving it costs 0.1 dB against the mean, the median 1.3 dB. Stylised: synthetic images, one translating disc, a still camera, untuned thresholds, no real raw files.
A figure from its own output
Paper, code and results
More in Sensing, imaging and 3D
- Can aligning a moving subject, instead of rejecting it, rescue a burst merge?Can aligning a moving subject rescue a burst merge instead of rejecting it? Inside the subject, yes (37.0 dB against 31.5 for reject-only and 32.8 for a 4×-area frame at 8 frames), but over the whole image rejecting is as good or better (31.7 against 31.8 dB), the aligner moves 10–31% of static pixels on noise, and the revealed-background ring stays 4 dB short of the large frame. Synthetic scenes only.
- Can a burst of hand-shaken low-resolution frames recover detail that merging and upsampling cannot?Can a burst of hand-shaken low-resolution frames recover detail that merging and upsampling cannot? At 2× in bright light a least-squares reconstruction reaches 29.5 dB at 16 frames against 24.0 for merge-and-upsample and 26.6 for merge-and-deblur, so 2.9 dB is sub-pixel information; it nearly vanishes in dim light and falls to nothing at about 0.27 px of shift error. Synthetic scenes only.
- How many milliseconds of camera-to-gyro time offset double a fused attitude error, and can online calibration recover it?How many milliseconds of camera-to-gyro time offset double a fused attitude error, and can an alignment fit recover it? About 12–14 ms at 30 deg/s motion; the fit recovers it to ~1 ms with motion and fails on a still platform. Synthetic, single axis.
- How much motion does a camera-to-gyro offset fit need, and what does clock skew do to a one-off calibration?How much motion does a camera-to-gyro offset fit need, and what does clock skew do to a one-off calibration? A 20 ms offset needs about 16 deg/s rms motion to fit reliably; 1000 ppm skew leaves 0.254 deg error after a fixed-offset fit against 0.155 deg when skew is fitted too. Stylised, synthetic.
- How accurate must a scan be to rebuild a part as parametric CAD?How accurate must a scan be to rebuild a part as parametric CAD? On synthetic plate scans, RANSAC plane and circle fits give all five dimensions within 0.2 mm for noise up to 0.2 mm, but at 0.5 mm noise the error is a bias (thickness −0.20 mm) that more points do not remove, and a 0.5% scale error alone moves an 80 mm length by 0.40 mm. Synthetic, one shape.
- How many photos does a usable 3-D reconstruction need?How many photos does a usable 3-D reconstruction need? On a synthetic object with known cameras, 12 views on a full orbit triangulate every feature, 8 views 89% and 4 or fewer at most 13%; per-point error then depends on pixel noise and pose error, not view count. Triangulation stage only (synthetic).
All 31 Sensing, imaging and 3D projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.