Does the epipolar gate still help when mismatches have the mix and rate a real SIFT matcher produces?
research/sensing-gatemix
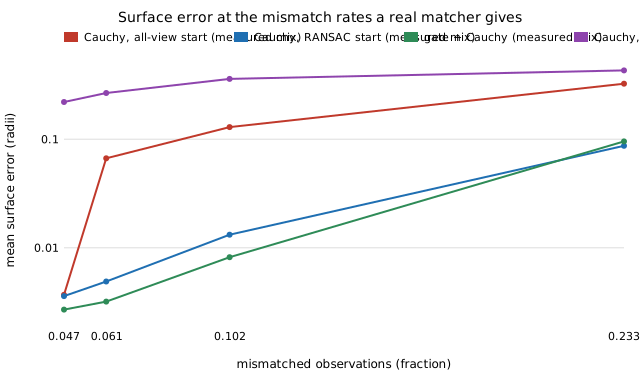
With the mismatch rates and mixes measured from SIFT on a real stereo pair, a ratio test of 0.8 to 0.6 (10% to 5% wrong) leaves gate + Cauchy adjustment at 0.008 to 0.003 object radii against 0.013 to 0.004 for the RANSAC start, and the all-random-pixel assumption overstated plain Cauchy's error 1.3 to 59 times; with no ratio test (56% wrong) every method fails
What it found
sensing-epigate assumed random-pixel mismatches; sensing-matchreal measured what SIFT actually produces. Here the measured mismatch rate and the measured along-epipolar / near / far mix, per ratio-test threshold, drive the epigate bundle-adjustment trial (synthetic 12-view rig, 300 features, wrong poses, 8 seeds). At a ratio test of 0.8, 0.7 and 0.6 (10%, 6%, 5% wrong) gate + Cauchy adjustment gives 0.0082, 0.0032, 0.0027 object radii (clean floor 0.0014) against 0.0132, 0.0049, 0.0036 for the RANSAC pair start without a gate; at 0.9 (23% wrong) they tie (0.095 vs 0.087); with no ratio test (56% wrong) every method exceeds 0.6. The gate removes about 83–86% of the measured mix against 95–97% of uniform mismatches, because the along-epipolar share passes pairwise tests, yet the adjustment is harmless to those. Treating all mismatches as random pixels overstated the error of plain Cauchy adjustment from the all-view start by 1.3 to 59 times. Limits: the geometry is synthetic and only the rate and mix are measured, from one stereo pair and one detector; rate is applied per observation; two isolated cells (mutual check, ratio 0.9 and 0.6) show one-seed spikes in 8 seeds.
A figure from its own output
Paper, code and results
More in Sensing, imaging and 3D
- Does modelling the sub-pixel coverage of a moving subject fix the edge ring that burst merging leaves behind?Does modelling the sub-pixel coverage of a moving subject fix the edge ring? Yes, on a known shape: a layered disc-over-background model fitted from the burst lifts the ring from 27.1 to 33.1 dB at 8 frames and 2 px per frame (4×-area frame: 31.7 dB), less at slow speeds, and it is sensitive to a 0.5 px centre error. Synthetic flat disc only.
- Can a background estimate or a subject mask fix the edge ring that burst alignment leaves behind?Can a temporal-median background or a subject mask fix the edge ring that burst alignment leaves behind? No: four ring treatments leave it at 21.6–27.2 dB at 8 frames against 31.6–32.0 for a 4×-area frame, none beats plain aligned-plus-reject (27.0 dB), and the mask misses most of a slow subject. Synthetic scenes only.
- How accurately does a real keypoint detector localise features as images get noisier and blurrier?On 30 warped real photographs SIFT keypoints localise to 0.13 px per axis at zero noise and 0.32 px at noise sigma 10 grey levels, 0.59 px at 40, so sensing-ba's assumed 0.5 px sits at roughly sigma 28; large keypoints are worse, blur matters little
- Does a gate or a RANSAC start survive the mismatch mixes a real SIFT matcher produces?With the mismatch rates and along/near/far mixes measured for SIFT, a ratio test of 0.8 or tighter (10% wrong or fewer) leaves gate and RANSAC-start adjustment near the clean floor (0.002 to 0.02 radii) while an all-view start is 0.005 to 0.39; at ratio 0.9 the RANSAC start wins and with no ratio test (56% wrong) everything fails. Synthetic rig, measured mixes
- What do a real matcher's mismatches look like: random pixels, near misses, or along the epipolar line?On a real Middlebury stereo pair SIFT with no ratio test is 56% wrong and 84% of the wrong ones are far, but at a 0.7 ratio test 6% are wrong and 62% of those lie on the true epipolar line (chance: 1%); ten warped photographs give 40% wrong without and 2% with ratio 0.6
- Does an epipolar gate help bundle adjustment under the mismatch mix a real SIFT matcher produces?Feeding sensing-matchreal's measured SIFT mismatch mixes into the sensing-epigate trial, gate plus Cauchy beats a RANSAC start at ratio tests of 0.8 and tighter (0.0078 against 0.0207 object radii at 0.8) and loses only at a loose 0.9 ratio test, where all methods exceed 0.08; synthetic geometry, 6 seeds
All 31 Sensing, imaging and 3D projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.