Does the best printer redesign change when imported bar stock counts as an import, not as made?
research/selfrep-stockmass
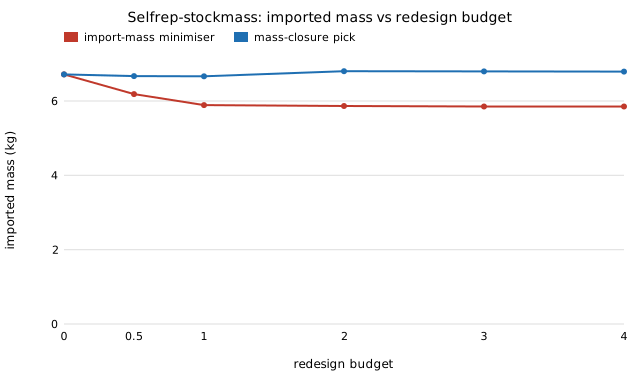
Scoring the printer redesign by the mass the shop must still import (vitamins plus raw stock) instead of closure: the best design imports 5.85 kg against 6.72 kg for the baseline, while the closure-maximising 12 mm aluminium pick imports 6.79 kg (stylised; yield and prices assumed).
What it found
A stylised, preliminary re-scoring of the 448-design search of selfrep-alusearch: the score is the mass (or cost) the shop must still import per printer copy, vitamins plus raw stock at an assumed 0.8 yield. The import-mass minimiser reaches 5.85 kg against 6.72 kg for the steel-rod baseline, with the light 8 mm hardwood rod; the earlier closure-maximising pick (12 mm aluminium) imports 6.79 kg, no better than baseline. By import cost the 12 mm aluminium rod stays best (147.5 against 173.3). Yield, stock price and penalties are assumed; computed only.
A figure from its own output
Paper, code and results
More in Simulation-first design
- Which imported part should a printer-replicating shop learn to make first?Which imported printer part to learn to make first (stylised, assumed inputs): by mass or cost the NEMA17 motor (+22 and +26 points of closure, first in 90% and 76% of draws with masses and costs scaled 0.5x to 2x), by unit count the M8 nut; by lines every vitamin ties.
- Which process capabilities should a printer-replicating shop learn when one capability unlocks several imported parts?Which process capabilities (lathe, winding, heat treatment, ...) a printer-replicating shop should learn when one capability unlocks several imported parts (stylised, assumed efforts): a lathe is the best first buy by mass (+31 points for effort 4), winding plus stamping by cost (+30 for effort 8), and exact capability sets beat part-by-part picking by up to 10 points, but the choice is fragile to the assumed efforts.
- In what order should a printer-replicating shop learn its process capabilities?In what order a printer-replicating shop should learn its process capabilities (stylised, assumed efforts): the exact best order over all 362,880 beats walking the budget frontier (54 to 73% of the optimum over 24 weeks); a gain-per-week bundle rule comes within 0 to 6%.
- Can Sigmund's 99-line topology optimisation be reproduced in Python and carried through to a printable part?Python reproduction of Sigmund's 99-line SIMP topology optimisation (cantilever, half-MBB; filter removes 11.5% checkerboards) with the density field exported as a mirrored, extruded STL; stylised 2D compliance only.
- How much stiffness does a topology-optimised cantilever lose when the real load points a different way than the model assumed?How much stiffness a topology-optimised cantilever loses when the real load direction differs from the modelled one: 1.57× at 60° and 2.58× at horizontal for the nominal design; a multi-load design at 0, ±60° cuts the worst case to 2.00× for 0.6% nominal cost; stylised 2D, preliminary.
- Does a density filter with Heaviside projection close the gap between a topology-optimised density field and the black-and-white part?Density filter and Heaviside projection added to the SIMP code: the optimiser's compliance matches the thresholded part's to 0.1% (sensitivity filter: 10% off) but the parts are equally stiff within 0.9%; β continuation needed (β=64 from the start: 344.8 vs 192.1); a minimum-length-scale check found no advantage (negative); stylised 2D.
All 64 Simulation-first design projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.