How much clearance does a printed two-pin cover need to assemble, and how wasteful is worst-case stacking?
research/robofab-tolstack
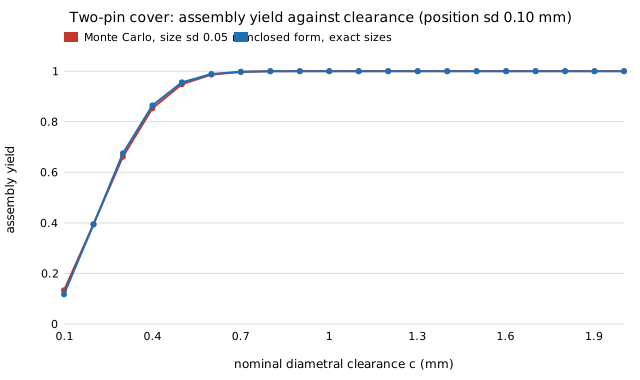
How much clearance does a printed two-pin cover need to assemble, and how wasteful is worst-case stacking? At position sd 0.10 mm and size sd 0.05 mm, 99% yield needs 0.62 mm diametral clearance and a ±3σ worst-case stack asks for 2.0 mm (stylised, assumed process spreads).
What it found
Monte Carlo of a printed base with two pins and a cover with two holes, each centre with a Gaussian position error and each diameter a Gaussian size error, translation-only assembly (exact two-disk test). With exact sizes, yield is 1 − exp(−c2/(8σp2)) (tested against simulation). For position sd 0.10 mm and size sd 0.05 mm, 99% yield needs 0.62 mm nominal diametral clearance and 99.9% needs 0.77 mm, while a ±3σ worst-case stack asks for 2.0 mm (3.0–3.4× the 99% requirement and 2.5–2.8× the 99.9% one across the six unbiased cases); a 3σ root-sum-square rule lands at 0.9990–0.9998 yield where the holes are unbiased. A hole bias adds to the needed clearance one for one. Assumed process spreads, not measured; two pins, no rotation, stylised.
A figure from its own output
Paper, code and results
More in Robot manufacturing loops
- When does the textbook milling chatter chart mislead?Zero-order milling stability lobes against semi-discretisation and time-domain simulation for a one-mode tool: exact at slotting, but at 10% up-milling the limit is up to 3.3 times too high at some speeds, and in down-milling the zero-order chart predicts no chatter while the tool goes unstable below 0.9 mm; the best spindle speed raises removal rate 5 to 18 times.
- How far below a clairvoyant schedule is online pick dispatch in a robotic waste-sorting cell?Follow-up to infra-sortvalue: an exact dynamic-programming bound on the best possible pick schedule (agreeable deadlines make arrival order optimal) shows highest-value-first dispatch reaches 96.5% of the clairvoyant optimum at 6 items/m and 93.9% at 10, FIFO 94.7% and 89.6%, and that the largest headroom (about 10 to 11%) sits at faster belts and slower arms, not at the loads where pick order helped most. A rolling-horizon rule that re-solves the schedule with a 1 s look ahead recovers most of it: 99.7% of the optimum at 6 items/m and 98.0% in the hardest cells.
- How fast can a belt run before a robot pick cell stops recovering recyclables?Single-robot conveyor pick cell fed with the class mix and object sizes of the 4,784 TACO litter annotations: with a 1 s pick and 1 m of reach, recovery of bottles and cans holds near 0.65 up to 0.5 m/s, falls to 0.48 at 1.0 m/s and is zero from 1.5 m/s (reach/pick-time is a hard limit); detector size threshold and false-call rate move purity and recovery more than the pick-order policy, which changes nothing.
- Does pick order matter for a robotic waste-sorting cell once items differ in value and arm travel?Follow-up to infra-sorting: with TACO's class mix, assumed item values (drink can = 4 plastic bottles) and 0.5 to 1.5 s of arm travel, picking the highest-value item first beats FIFO by only 0.1% at 1 item/m, 2.0% at 6/m and 4.8% at 10/m, and value-per-second picking matches it; belt speed and pick time matter far more than pick order.
- Which assembly orders survive a better checker?Assembly-order planning for a printed gearbox: exact subset DP, collision-only admits 10.6% of orders but support checking leaves 0.077%, the collision-only optimum is infeasible, greedy disassembly needs 4 direction changes vs 1 optimal. Stylised.
- Does a quasi-static support rule agree with a physics engine?MuJoCo settle tests of all 2,048 partial gearbox assemblies vs the quasi-static support rule: 95.6% agreement, 81 mutual-support false accepts and 10 bore-capture false rejects, valid-order count unchanged at 30,760. Stylised.
All 53 Robot manufacturing loops projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.