Which assembly orders survive a better checker?
research/robofab-sequence
Assembly-order planning for a printed gearbox: exact subset DP, collision-only admits 10.6% of orders but support checking leaves 0.077%, the collision-only optimum is infeasible, greedy disassembly needs 4 direction changes vs 1 optimal. Stylised.
What it found
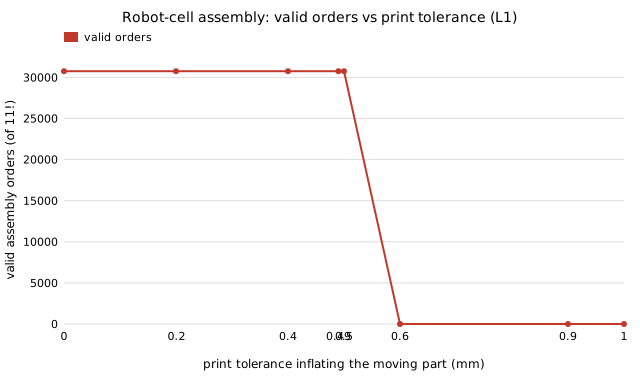
Exact subset dynamic programming over assembly orders for a twelve-part printed gearbox, checked at three fidelity levels. Collision-only admits 4,227,168 of 39,916,800 orders (10.6%); adding quasi-static support leaves 30,760 (0.077%), and the collision-only optimum is infeasible once support is checked. Greedy disassembly needs 4 insertion-direction changes against an optimum of 1; one order written by the session agent (a single attempt, not a benchmark) passes with 2. Stylised axis-aligned boxes, no physics engine.
A figure from its own output
Paper, code and results
More in Robot manufacturing loops
- Does a quasi-static support rule agree with a physics engine?MuJoCo settle tests of all 2,048 partial gearbox assemblies vs the quasi-static support rule: 95.6% agreement, 81 mutual-support false accepts and 10 bore-capture false rejects, valid-order count unchanged at 30,760. Stylised.
- Does an insertion policy tuned in one simulator survive a better one?Peg-in-hole search policies tuned by CEM in MuJoCo at three fidelity levels or with domain randomisation: tuned on the simplest level 0.91 success there but 0.53 / 0.26 on a stiffer-contact / held-out level; training on the stiffer level or with randomisation gives 0.43–0.46 held-out and cannot be ranked with 5 seeds. Stylised, sim-to-sim.
- How much of the gap between “the twin passes” and “it fails for real” does each twin fidelity close?Session-written pick-and-place programs checked in a kinematic SCARA twin at three fidelities against a held-out reference: of 69 reference-failing injected-bug mutants the levels reject 38, 46 and 60 with no false alarms; misses are unmodelled effects (stylised).
- Which resource limits a small robot-printer-inspection cell, and does the busiest one tell you what to upgrade?Discrete-event twin of an arm, printers and an inspection station: printers have the highest utilisation at every size, yet at 6 printers an extra arm saves 10.9 min vs 2.3 for an extra inspection station; dispatch rules trade makespan for flow time; a mean-value twin is optimistic. Stylised, illustrative parameters.
- Where is the bottleneck of an arm, printer and inspection cell?Discrete-event twin of an arm, 3D printers and an inspection station: a utilisation bound names the bottleneck (printers to 10, the arm from 12, ~12.7 good parts/h) and the simulation sits 10–11% below it near the switch; a 25% faster arm lifts 11.34 to 12.68 parts/h at 12 printers, a second inspector nothing (stylised).
- Does exact queueing analysis predict a robot-printer cell's throughput better than a utilisation bound?Exact mean value analysis of the arm, printers and inspection network against a discrete-event twin: a few per cent off for exponential times, up to 11% low for less variable ones, better than the utilisation bound in most real-semantics rows, and it overshoots saturation at high work in process. Stylised.
All 53 Robot manufacturing loops projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.