Does the friction-grasp bound survive lift acceleration and an off-centre centre of mass?
research/robofab-liftload
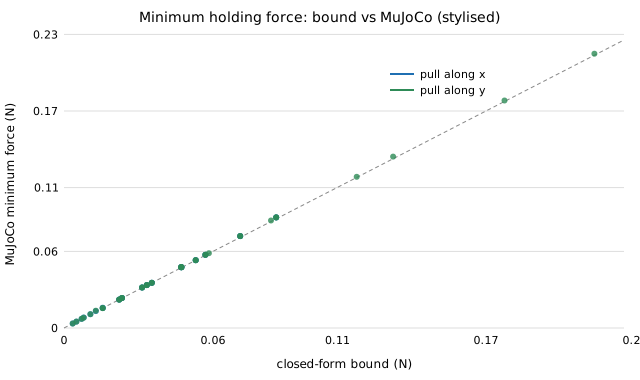
Does the friction-grasp bound survive lift acceleration and an off-centre centre of mass? Scaled bound matches MuJoCo within 6% over 66 cases; the torque bracket for an off-centre bar is inconclusive and depends on the rotation tolerance (stylised).
What it found
A follow-up to robofab-grasp. With a constant lift or sideways acceleration applied as an effective gravity, the simulated minimum jaw force for the six free parts of the toy gripper stays within 6% of the scaled bound m √((g+az)2+at2)/(2μ) over 66 cases, at most 0.21 N. These parts are symmetric, so they test no torque. For a 10×10 mm bar held at one end the torque bracket is inconclusive: with a 5° rotation tolerance MuJoCo holds with less force than the lower bound in 11 of 12 cases, and with 1° the longer bars do not hold at 20 N. Stylised: constant load, boxes, assumed density and friction, thresholds chosen by me.
A figure from its own output
Paper, code and results
More in Robot manufacturing loops
- Is the off-centre bar result in robofab-liftload a grasp effect or solver creep?Is the off-centre bar result in
robofab-liftloada grasp effect or solver creep? The bar creeps at about 3.7 deg/s from 0.3 to 3 N in MuJoCo, with a rate set by contact settings, so the earlier verdict reflects the simulator (stylised). - Does a rate-based "holds" criterion make a MuJoCo grasp verdict independent of solver settings?Does a rate-based "holds" criterion make a MuJoCo grasp verdict independent of solver settings? No: the minimum holding force still varies 33x to 400x or more across contact settings, like a 1 degree tolerance (negative, stylised).
- Is any rate threshold settings-robust for a MuJoCo grasp "holds" verdict?Is any rate threshold settings-robust for a MuJoCo "holds" verdict? Spread falls with the allowed tip speed and is 1.6 only at a loose 20 mm/s (0.5 s, 10 mm); 242.7 to 400 at 2 mm/s or less (stylised, preliminary).
- Does the loose 20 mm/s “holds” threshold stay settings-robust at other friction and under lift?Does the loose 20 mm/s "holds" threshold stay settings-robust at other friction and under lift? It is the only threshold under 5x spread in all six conditions (1.6 to 4.5), every other is at least 20x (stylised, preliminary).
- Does a stiffer friction cone make the held-bar result in robofab-liftload threshold-free?Does a stiffer friction cone make the held-bar result threshold-free? Creep falls about as 1/
impratio(3.66 to 0.004 deg/s); fromimpratio10 the 1 and 5 degree forces agree within 26%, and MuJoCo needs 0.67 to 1.17 times the old torque bracket's lower bound (stylised). - How much clearance does a printed two-pin cover need to assemble, and how wasteful is worst-case stacking?How much clearance does a printed two-pin cover need to assemble, and how wasteful is worst-case stacking? At position sd 0.10 mm and size sd 0.05 mm, 99% yield needs 0.62 mm diametral clearance and a ±3σ worst-case stack asks for 2.0 mm (stylised, assumed process spreads).
All 53 Robot manufacturing loops projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.