How much heavier must an observation UAV be if the wind is uncertain, and is designing to a wind quantile cheaper than a bigger battery reserve?
research/osrobot-uavgust
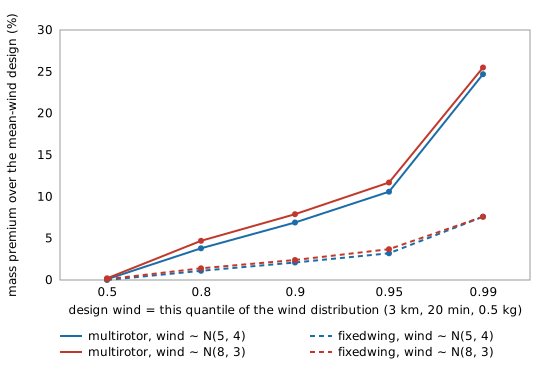
How much heavier must an observation UAV be if the wind is uncertain? Designing to the 95th-percentile of wind ~ N(8, 3) m/s costs the fixed wing +3.7% and the multirotor +11.7% mass, and a bigger battery reserve buys about the same reliability for about the same mass; stylised, one steady wind per mission.
What it found
A stdlib extension of osrobot-uavwind draws one along-track wind per mission from a normal distribution (exact discretisation, no sampling noise) and sizes the airframe for a quantile of it. For a 3 km, 20 min, 0.5 kg mission with wind ~ N(8, 3) m/s, designing to the 95th-percentile wind (12.9 m/s) costs the fixed wing +3.7% mass (1.333 against 1.286 kg) and the multirotor +11.7% (2.518 against 2.254 kg). The standard 20% reserve, if it may be spent, already lifts a mean-wind design to 0.95 (fixed wing) and 0.99 (multirotor) success, and a larger reserve and a quantile design cost within a few percent of each other. At a 1 min stay the 95th-percentile design flips the lightest airframe from multirotor to fixed wing. Stylised: one steady wind per mission, assumed constants, no turbulence, no launch limit, and no flight.
A figure from its own output
Paper, code and results
More in Open-source purpose-built robots
- If an observation UAV only launches when the forecast wind is below a limit, how much does forecast error bring failures back, and what does it cost in scrubbed missions?If an observation UAV launches only when the forecast wind is under a limit, how much does forecast error bring failures back? A perfect forecast turns every failure into a scrub (fixed wing, wind ~ N(5, 4) m/s: 4.6% scrubbed at the 95th-percentile limit); a 2 m/s error gives 6.8% failures at the median limit but 1.1% at the 95th. Stylised, one steady wind per mission.
- If a scrubbed observation-UAV launch can be retried later the same day, how much does persistent wind limit what retrying buys, and does retrying bring failures back?If a scrubbed observation-UAV launch can be retried later the same day, how much does persistent wind limit the gain, and do retries bring failures back? Fixed wing, median-wind limit, perfect forecast: eight slots complete 99.7% of days with independent wind but 71.5% with persistence 0.95; with a 2 m/s forecast error eight slots raise failures from 6.8% to 13.6% of days (23.7% at persistence 0.95). Stylised.
- What is a UAV launch wind limit worth in money, and should the launch threshold sit below the design limit when the forecast is wrong?What is a UAV launch wind limit worth in money, and should the launch threshold sit below the design limit when the forecast is wrong? With an assumed expensive airframe and a 2 m/s forecast error the best threshold sits 1 to 6 m/s below the design limit, worth up to $284 per attempt, with failures at or below 0.1%; with a cheap airframe the best design covers nearly every wind. Stylised, assumed prices.
- When does one shared robot beat a dedicated robot per job in a pick-and-place shop?When does one shared robot beat a dedicated robot per job in a pick-and-place shop? Sharing wins while the total load fits one machine and changeover is short (4 jobs, trays within 0.4 m: shared cheapest at demand 0.2 per job, dedicated from 0.3); the shared arm often cannot hold tight tolerances. Stylised, assumed costs.
- What does a shared pick-and-place robot cost once it has to stay up, and do spares change when sharing beats a robot per job?What does a shared pick-and-place robot cost once it must stay up? Spares priced per job or for every job at once: the shared fleet costs the same fraction of a robot per job when its load fits one machine (0.68 at 4 jobs), and falls to 0.34 to 0.51 when all jobs must run at once. Stylised, assumed availabilities.
- When a spoon-feeding arm meets a moving mouth, what sets the force on the lips: the sensor, the approach speed or a force cap?What sets the force on the lips when a spoon-feeding arm meets a swaying mouth: the sensor, the approach speed or a force cap? Peak force tracks approach speed (1.0 N at 0.05 m/s, 4.0 N at 0.20), a camera cuts how often the lips are touched (0.40 against 0.72 of trials) but not how hard, and latency erodes that gain. Stylised point-mass model, assumed constants.
All 44 Open-source purpose-built robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.