How fast can a purpose-built robot fill a 96-well plate, and does the robot or the number of channels matter more?
research/osrobot-plate
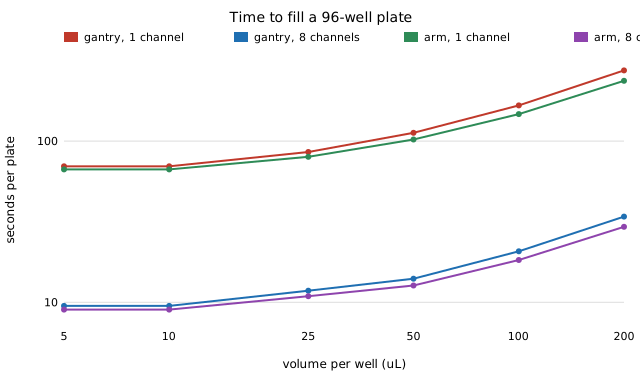
How fast can a purpose-built robot fill a 96-well plate, and does the robot or the number of channels matter more? Eight channels cut the time by 86 to 88 % (9.5 s against 69.7 s for a gantry at 10 µL) while gantry against arm moves it 4 to 14 %, since about 76 % is fixed pipetting actions (stylised; every speed, price and accuracy figure assumed).
What it found
A stdlib model times a 96-well plate fill on an XY gantry and a two-link arm with 1 or 8 channels. At 10 µL per well one channel takes 69.7 s (gantry) or 66.7 s (arm); eight channels take 9.5 and 9.0 s. Channel count cuts the time by 86–88%; robot type moves it by 4–14%, because 76–79% of the time is fixed aspirate and dispense actions, so well order saves only about 2%. Which robot is faster flips with the assumed speeds; the 8-channel gantry is cheapest per plate-hour by a small margin. With assumed joint noise the arm misses the 1.5 mm well radius often enough to hit all 96 wells with probability 0.005. Stylised: every speed, price and accuracy figure is assumed.
A figure from its own output
Paper, code and results
More in Open-source purpose-built robots
- Does the scout-and-treater weeding fleet still lose to inline robots when the machines are priced from published list prices?Re-runs osrobot-deadlineloss with a Holybro X500 V2 drone (609 USD) and an AgileX Scout Mini (4,500 USD) at list price: pipeline over inline cost moves from 1.49 to 1.54 at 0.18 ha and 1.07 to 1.15 at 1.62 ha, ties at a 4,500 USD ground platform, and flips with an unsourced loaded flight time
- Does the osrobot-uav multirotor energy model match real aircraft?Does the osrobot-uav multirotor energy model match real aircraft? With the Mavic 3's published 9.4 in propellers (0.239 m) it predicts 1.3 to 1.6 times the published 45 min endurance, so it is optimistic; the Anafi UKR rotor size was not found, so that row remains a sweep.
- Is one slow weeding pass better than several fast ones, and does treating on the move change that?A laser-weeding robot that drives three fast passes (4 km/h) kills 0.780 of the weeds in 75 min, against 0.607 in 83 min for one slow pass (1 km/h), and treating on the move instead of stopping cuts time by 6% at 0.3 weeds/m² and 39% at 3 weeds/m²; the ranking survives 30% of weeds being invisible to the detector
- Do several fast laser-weeding passes still beat one slow pass when the detector's hit rate comes from published field trials?With a detector fitted to two published field detection rates (88.9% at 0.2 m/s, 86.2% at 0.425 m/s), two laser-weeding passes at 4 km/h kill 0.952 in 40 min against 0.875 in 68 min for one pass at 1 km/h; the ranking holds, and the share of weeds the detector never sees (3 passes cap at 0.897 with 10% hidden) now sets the ceiling
- When does a purpose-built gantry beat a general two-link arm at tray pick-and-place?When does a purpose-built gantry beat a general two-link arm at tray pick-and-place? At 2 mm tolerance the arm wins only between 0.36 and 0.99 m of work area, and the band depends on assumed costs (stylised).
- Does co-designing an arm's link lengths and controller beat tuning the controller on a fixed body?Does co-designing an arm's link split and controller beat tuning the controller on a fixed body? Co-design gained 1.9% in held-out move time (0.283 against 0.289 s), within three-seed noise; tuning the controller mattered about 37%. Stylised, preliminary, mostly negative.
All 44 Open-source purpose-built robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.