Is the peak force of a feeding arm on the lips set by the lips' stiffness, the arm's force loop, or its approach lead?
research/osrobot-lipsweep
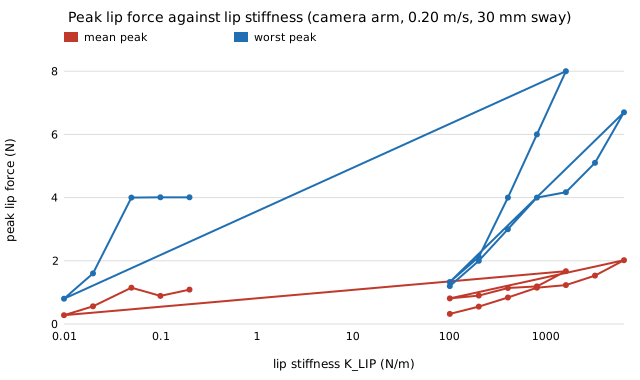
Is the peak force of a feeding arm on the lips set by lip stiffness, the force loop or the approach lead? Lip stiffness moves the mean peak from 0.32 to 2.02 N at 0.20 m/s (stylised; extends osrobot-assist).
What it found
A stdlib sweep of osrobot-assist's feeding-arm twin over lip stiffness, loop stiffness and forward lead (200 paired trials per row, 30 mm sway, camera arm at 0.20 m/s). Mean peak lip force rises from 0.32 N at 100 N/m to 1.15 N at 800 and 2.02 N at 6400; the worst trial reaches 6.7 N, above the controller's 4.0 N stall push, so that push is a ceiling only for soft and medium lips. At 0.05 m/s every stiffness stays under 2 N. Stylised: assumed constants, a point mass and a passive user.
A figure from its own output
Paper, code and results
More in Open-source purpose-built robots
- If the person being fed judges the spoon better as it nears the mouth, how much of a camera's value does a blind feeding arm get back?If the person being fed judges the spoon better as it nears the mouth, how much of a camera's value does a blind arm get back? A misjudgement shrinking to zero at the lips lifts the blind arm's safe share at 40 mm from 0.47 to 0.84 and restores every feed; stylised, extends
osrobot-leannoise. - If the person being fed misjudges the spoon, or sees it late, can a blind feeding arm still do without a camera?If the person being fed misjudges the spoon or sees it late, can a blind feeding arm still do without a camera? A 20 mm misjudgement drops the blind arm's safe share from 1.00 to 0.60 (camera arm 0.78); stylised, extends
osrobot-lean. - If the person being fed leans toward the spoon, can a blind feeding arm do without a camera?If the person being fed leans toward the spoon, can a blind feeding arm do without a camera? At 30 mm sway and 0.20 m/s the blind arm's safe share rises from 0.21 to 1.00 as the lean reaches 100 mm/s (stylised; extends
osrobot-assist). - When a pest window sets a deadline, is a scout-and-treater fleet or a fleet of inline weeding robots cheaper?When a pest window sets a deadline, is a scout-and-treater fleet or inline weeding robots cheaper? One scout cannot finish 16 fields faster than 5.3 to 32.5 h; pipeline/inline cost is 1.06 to 1.12 at 0.72 ha, 1.49 at 0.18 ha, and 0.87 to 0.93 at 1.62 ha where it can meet the deadline.
- If one scout drone feeds ground treaters in a pipeline, can a held fleet beat inline weeding robots?If one scout drone feeds ground treaters in a pipeline, can a held fleet beat inline weeding robots? One scout keeps only 1.0 to 1.3 treaters busy; overlapping the stages cuts the held-pair penalty to 1.04 at 0.72 ha fields and 0.86 at 1.62 ha, still losing on small fields. Assumed prices; scheduling over
osrobot-pairprice's fits. - Is a scout drone plus a camera-less ground treater cheaper per hectare than one weeding robot, and from what field size?Is a scout drone plus a camera-less ground treater cheaper per hectare than one weeding robot? With assumed prices and each machine charged for its own minutes, break-even is near 0.5 ha and the pair is about 0.7 times the cost per hectare at 5 ha; held for the whole job it never wins; flips with utilisation, labour and battery life. Stylised, nothing built.
All 44 Open-source purpose-built robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.