Is an interference-free or mean-noise-rise radar twin right when robots' radars interfere with each other?
research/interference-twin
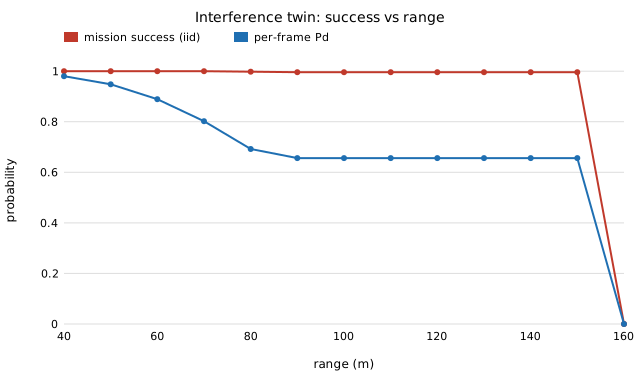
Interference-free or mean-noise-rise radar twin vs intermittent mutual radar interference between robots: exact closed-form per-frame Pd, real Pd plateaus at 0.656 (no-hit probability), mean-rise twin 9% optimistic at Pd ≥ 0.9 yet badly pessimistic for hit-tolerant missions, geometry knowledge helps 9-of-10 missions (Brier 0.089 vs 0.101). Stylised.
What it found
Mutual radar interference between robots, with heavy-tailed c/d2 interferer power hitting each frame intermittently. Per-frame detection probability has a closed form (matches Monte Carlo within 0.003); real Pd plateaus at the probability that no interferer hits the frame (0.656) rather than shrinking in range. A mean-noise-rise twin is 9% optimistic at Pd ≥ 0.9 (63.7 vs 58.4 m) but badly pessimistic for missions that tolerate hit frames (Brier 0.690 vs 0.003 for 3-of-10); for 9-of-10 missions knowing the interferer geometry helps (0.089 vs 0.101). Stylised: simulated interference, illustrative parameters, no radar data.
A figure from its own output
Paper, code and results
More in Detection & tolerances
- Does demand-driven simulation mislead leak detection on a stressed water network, and where does pressure-driven demand change the answer?Net3 leak signals under demand-driven and pressure-driven demand (WNTR): identical at 1 to 1.25 times base demand and nearly so at 1.5 times; beyond that both models fail because the pumps cannot meet demand (simulated; one network).
- How small a water-main leak can pressure sensors find, and does a changepoint detector beat a threshold or CUSUM?Water-leak detection from pressure residuals on EPANET's Net3 (WNTR): at a 5% weekly false-alarm budget, 5 sensors and 10% demand error, CUSUM finds all leaks the sensors can see at 4% of demand but 8% at 1% (3% of all leaks); demand error, not sensor noise or detector choice, sets the limit (simulated leaks; BattLeDIM L-Town was unreachable).
- Reproducible operators and refereed trainingMeasured float32 reduction-order drift, RepOps-style canonical order, Merkle-committed training traces with a teacher-forced referee; per-step tolerance is a cumulative hidden-deviation budget.
- How many honest runs does a slashing tolerance need?Calibrating slashing tolerances from honest runs: split-conformal false-slash law
(n+1-k)/(n+1)is exact but only ~51–56% of calibration sets are ≤ α, PAC safety needsn ≥ ln δ/ln(1−α)(459 at 1%/1%), the margin is cheater hiding room (×1.26 at n=2000, Pareto-3), Gaussian plug-ins over-slash skewed drift up to 17×, pooled hardware calibration over-slashes the noisy class 4.8× and lets the quiet class hide 2.9×. - Should drift tolerances be per layer or on the total?Per-layer vs total drift tolerances: a tolerance per layer admits
L·c(L,α)σvsz_α√L σon the total (6.6× at L=16), the sum test ignores how a cheat is spread while the max test catches 2.7σ in one layer but lets 16σ through spread over all, and a union test caps the hidden budget at the sum test's. - How well does Freivalds' check work in floating point?Freivalds' matrix-product check in floating point: rank-one corruption missed with probability exactly
erf(t/(√2F))(worst case for fixed norm),erf^mfor m probes, Rademacher probes stuck at ½ for any size, measured float32 noise floor, and1/erfgrinding tries when the probe is hashed from the result.
All 14 Detection & tolerances projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.