How much outer step does overlapping communication with compute cost, and how many rounds should be in flight?
research/delayed-outer
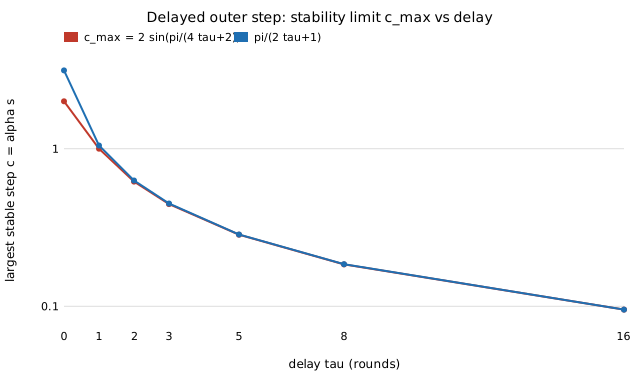
Overlapping communication in local SGD with τ-round-late outer updates: exact stable step 2 sin(π/(4τ+2)) (shrinks ~1/τ), double-root rate τ/(τ+1), exact noise floor matched to simulation, free at small steps, wall-clock-optimal delay ⌈L/T_c⌉ (1.9–7.5× faster than no overlap).
What it found
Applying the averaged displacement τ rounds late obeys zτ+1 − zτ + c = 0 with c = αs, so the stable step is exactly c < 2 sin(π/(4τ+2)) ≈ π/(2τ+1): 2, 1, 0.62, 0.45 for τ = 0…3, shrinking like 1/τ. The fastest single-mode rate is the double root τ/(τ+1), and the stationary noise floor is an exact Yule–Walker solve (closed form (1+c)/((1−c)c(2+c)) at τ = 1) that matches literal delayed-DiLoCo simulation to 0.3%. Delay is free at small steps (+1% at α = 10−3, τ = 4) but multiplies the floor by 3.9× at c = 0.8. At an equal floor each delay round costs only about 6% more rounds, so the wall-clock-optimal delay is exactly ⌈latency / compute time⌉ (1.9–7.5× faster than no overlap). Stylised: constant delay, identical workers, quadratics, no momentum.
A figure from its own output
Paper, code and results
More in Decentralised training systems
- Does error feedback rescue the noise floor that compressed local SGD loses?Error feedback in compressed local SGD: exact stability limit
2(2−ρ)Nρ/(Nρ²+4(1−ρ))and closed-form floor that returns to the uncompressed one at small steps (unbiased compression pays1/ρ), dropping is biased to the send-rate-weighted mean and the residual removes it at a variance price. - How should a server weight workers that ran different numbers of inner steps?Weighting workers that ran different numbers of inner steps: exact floor
α²Σw²V/(r(2−r)), worker informationI∞·tanh(λH/2)saturates, optimal weights span ≤2× so equal weights lose ≤9/8 (measured ≤1.09) while step-proportional weights lose up to 1.76× per mode and 10.5× on three modes. - What does a median or trimmed-mean outer step cost local SGD, and what does it buy against Byzantine workers?Median and trimmed-mean outer aggregation in local SGD: exact linear loop with floor and bias split,
π/2variance price with no attackers, bounded worst-case biasΦ(z)=1/(2(1−ε))that more workers cannot average away but a longer inner loop shrinks. - Which of sync interval, compression, delay, momentum and robust aggregation sets the final loss of low-communication training?Research programme (proposal stage): a predictive theory of DiLoCo-style low-communication training, testing on real small transformers the closed forms derived in about a dozen quadratic-model projects, with 16 references, hypotheses H1 to H6 and an ICML/NeurIPS workshop as the first target
- How far over its limit can a rate limiter be pushed in a true rolling window?How far over its limit can a rate limiter be pushed in a true rolling window? Adversarial search over fixed window, sliding log, sliding-window counter, token bucket and leaky bucket: only the sliding log holds the limit; the sliding counter admits up to about 1.5 L and the buckets nearly 2 L, and under Poisson overload at 1.5x load 39-47% of rolling windows exceed the limit for fixed window and buckets. Stylised.
- What can one stubborn node do to gossip training?Pairwise gossip for decentralised training: exact contraction
(n−2)/(2(n−1))≈½per matching round (~20 rounds at any n), noise floor(n−1)(n−2)s²/n, one stubborn node captures consensus at rate1−1/(n(n−1)), trust-region clipping caps drift atτ/(n(n−1))per step.
All 23 Decentralised training systems projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.